Real View
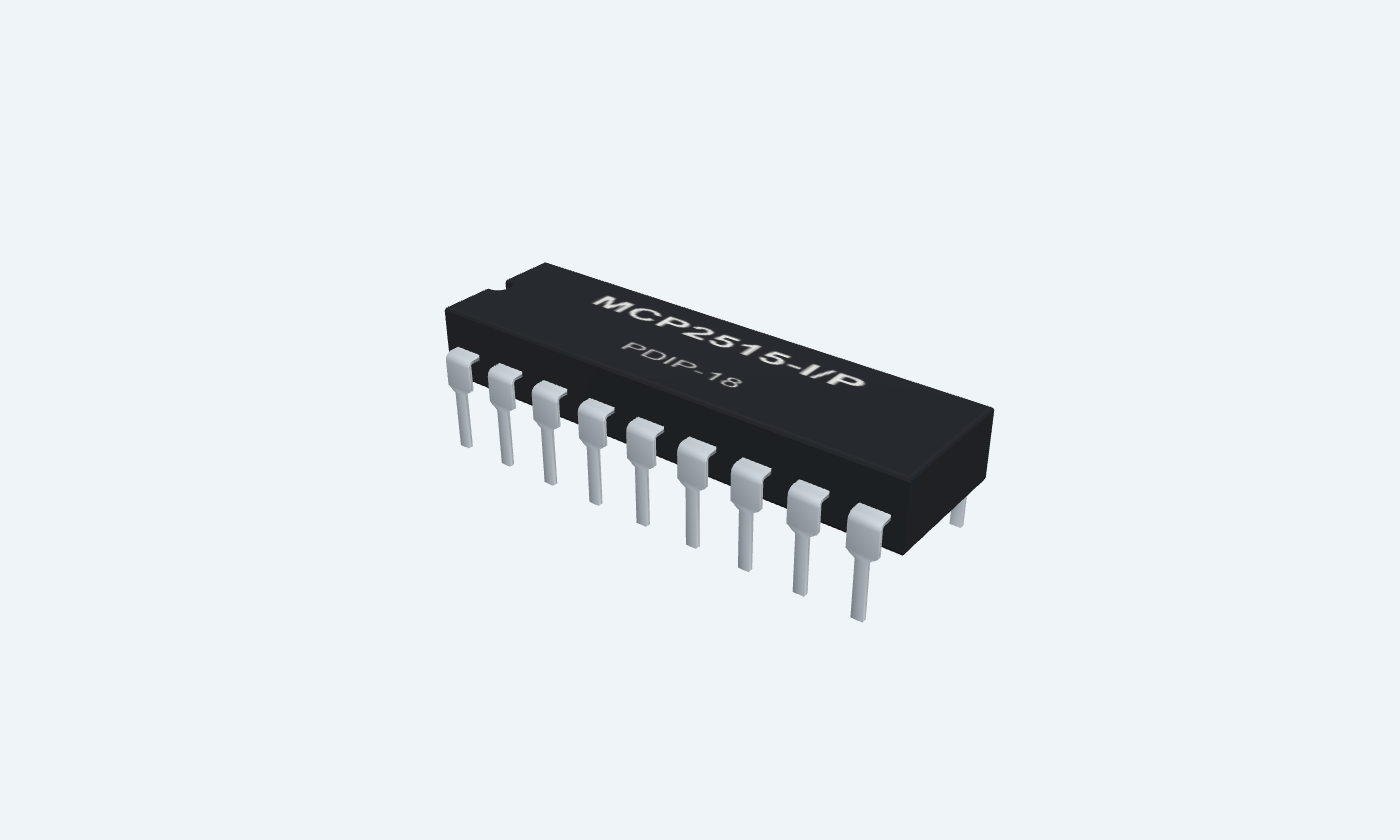
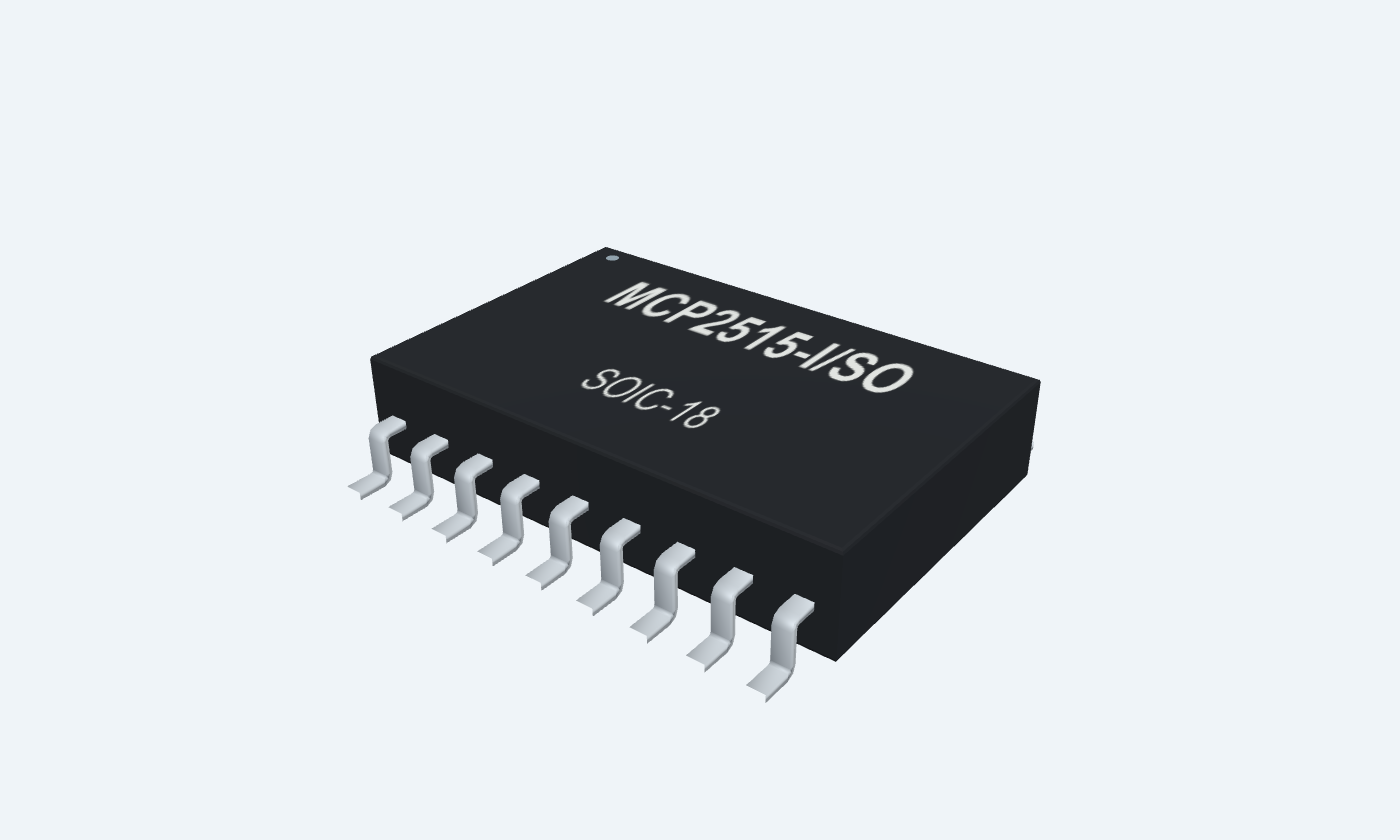
Add classical CAN messaging to an SPI-equipped controller.
MCP2515 is a stand-alone classical CAN 2.0B controller accessed through SPI. It handles frame formatting, arbitration, error detection and message buffering, while the host prepares messages and services received data. An external transceiver is required to drive CANH and CANL. Three transmit buffers and two receive buffers separate bus activity from host transfers. Six acceptance filters and two masks can reduce unnecessary host work. Standard 11-bit identifiers and extended 29-bit identifiers are supported, with up to eight data bytes per frame; CAN FD is not supported. The example combines a 5 V controller, a 20 MHz external oscillator and an MCP2562 transceiver. A reviewed timing setup produces 125 kbit/s. Wiring alone does not start communication: firmware must reset and configure the controller, select Normal mode and communicate with another correctly configured node.
Select a pin to explore its connection
Click a lead or use the arrow keys. Top view
Sends the CAN protocol engine’s dominant/recessive logic to a transceiver.
Connect to MCP2562 TXD pin 1.
This is not CANH or CANL; never connect directly to the cable.
Receives the bus state from the external transceiver.
Connect to MCP2562 RXD pin 4.
Outputs a divided oscillator clock or a selected start-of-frame indication.
Leave open when unused.
After reset the enabled clock defaults to FOSC / 8.
Active-LOW request for transmit buffer 0, or a general-purpose input according to TXRTSCTRL.
Leave unconnected when unused; its internal pull-up holds it HIGH.
Approximately 100 kΩ internal pull-up to VDD.
Active-LOW request for transmit buffer 1, or a general-purpose input according to TXRTSCTRL.
Leave unconnected when unused; its internal pull-up holds it HIGH.
Approximately 100 kΩ internal pull-up to VDD.
Active-LOW request for transmit buffer 2, or a general-purpose input according to TXRTSCTRL.
Leave unconnected when unused; its internal pull-up holds it HIGH.
Approximately 100 kΩ internal pull-up to VDD.
Feedback terminal for crystal/resonator operation.
Leave open in the external-clock example.
Accepts the clock used for CAN bit timing and internal operation.
Apply a 20 MHz, 0–5 V oscillator output with 45–55% duty cycle.
Ground for logic, clock and I/O.
Join the controller, oscillator and transceiver reference.
Configurable buffer-full indication or general-purpose output.
Leave open when using INT alone.
Configurable buffer-full indication or general-purpose output.
Leave open when using INT alone.
Signals enabled interrupt conditions; software must inspect and service their flags.
Connect to a compatible controller interrupt input.
Clocks commands and register data; SPI modes 0 and 3 are supported.
Connect controller SCK; use 1 MHz for the example.
Receives instruction, address and data from the controller.
Connect MOSI.
Returns register and buffer data; high impedance when CS is HIGH.
Connect MISO.
LOW starts an SPI instruction; return HIGH before the next instruction.
Connect a dedicated controller select and 10 kΩ pull-up to +5 V.
Initializes registers and enters Configuration mode.
Use a 10 kΩ pull-up and controller reset output; hold LOW at least 2 µs.
Allow oscillator startup before SPI access.
Powers the CAN controller and its I/O.
Use +5 V with 100 nF directly to VSS9.
Operating range 2.7–5.5 V; logic thresholds scale with supply.
The SPI host configures buffers, filters and timing. The CAN engine performs bus arbitration and error handling through TXCAN and RXCAN. A separate transceiver provides the electrical bus interface.
MCP2515-I/P · PDIP-18
| Property | Details |
|---|---|
| Manufacturer | Microchip Technology |
| Part number | MCP2515-I/P |
| Package | PDIP-18 |
| Connections | 18 pins |
| Mounting | Through-hole |
| Lead pitch | 2.54 mm |
| Package code | dip |
| Thermal reference | Board and package dependent; see manufacturer data |
Classical CAN 2.0B
Scroll sideways to see all columns.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Bus rate | Up to 1 Mbit/s | Subject to oscillator and network timing |
| Identifiers | 11-bit standard / 29-bit extended | Data and remote frames |
| Data field | 0–8 bytes | No CAN FD or bit-rate switching |
| Transmit storage | Three prioritized buffers | Abort and one-shot options |
| Receive storage | Two buffers | Priority and optional rollover |
| Acceptance | Six filters and two masks | Configure before Normal mode |
| External line interface | Required CAN transceiver | TXCAN / RXCAN are logic signals |
No specifications match. Try a parameter name or a unit.
A controller and a transceiver solve different parts of the CAN interface.
Most significant bit first · separate CS cycle per command
Scroll sideways to see all columns.
| Parameter | Value | Conditions / notes |
|---|---|---|
| RESET | 0xC0 | Initialize and enter Configuration mode |
| READ | 0x03, address, dummy clocks | Consecutive register bytes may follow |
| WRITE | 0x02, address, data… | Sequential register write |
| BIT MODIFY | 0x05, address, mask, data | Only supported registers; mask 1 permits change |
| READ STATUS | 0xA0 | Frequently used RX/TX status |
| RX STATUS | 0xB0 | Received-frame type and matching filter |
| RTS buffer 0 | 0x81 | Request already-loaded TXB0 transmission |
| SPI timing | 10 MHz maximum; 50 ns CS setup/hold | Modes 0 and 3 |
No specifications match. Try a parameter name or a unit.
The controller expects an instruction immediately after CS falls. Raise CS before issuing another instruction.
Request via CANCTRL; confirm via CANSTAT
Scroll sideways to see all columns.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Configuration | REQOP 100 | Required for bit timing, filters, masks and TXRTSCTRL |
| Normal | REQOP 000 | Transmit, receive and acknowledge CAN frames |
| Sleep | REQOP 001 | Oscillator stopped; wake-up conditions apply |
| Loopback | REQOP 010 | Internal communications test without bus transmission |
| Listen-only | REQOP 011 | Observe bus without transmitting or acknowledging |
| Mode confirmation | Read OPMOD bits | A request may wait for pending transmissions |
No specifications match. Try a parameter name or a unit.
Listen-only nodes do not supply the acknowledgment required for a transmitting node’s normal successful frame.
20 MHz external clock · single sample
Scroll sideways to see all columns.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Oscillator period | 50 ns | 1 / 20 MHz |
| BRP register field | 4 | TQ = 2 × (BRP + 1) / FOSC |
| Time quantum | 500 ns | Prescaler division by 10 |
| Segments | Sync 1; Prop 2; PS1 7; PS2 6 | 16 TQ per bit |
| Sample point | (1 + 2 + 7) / 16 = 62.5% | At the end of Phase Segment 1 |
| Synchronization jump width | 1 TQ | Must not exceed PS2 |
| CNF1 / CNF2 / CNF3 | 0x04 / 0xB1 / 0x05 | BTLMODE=1, SAM=0; wake filter/SOF disabled |
| Result | 16 × 500 ns = 8 µs per bit | 125000 bits/s |
No specifications match. Try a parameter name or a unit.
This is the manufacturer’s illustrative timing split, not a universal network prescription. Review propagation, oscillator tolerance and the other nodes.
MCP2515-I/P and MCP2515-I/SO
Scroll sideways to see all columns.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Operating supply / temperature | 2.7–5.5 V / −40 to +85°C | I grade |
| SPI input HIGH | ≥ 0.7 × VDD | SCK, SI and CS |
| SPI input LOW | ≤ 0.4 × VDD | SCK, SI and CS |
| RXCAN HIGH / LOW | ≥ 2.0 V / ≤ 0.15 × VDD | Different input thresholds from SPI |
| Reset HIGH / LOW | ≥ 0.85 × VDD / ≤ 0.15 × VDD | Schmitt reset input |
| External clock range | 1–25 MHz over 2.7–5.5 V | Up to 40 MHz at 4.5–5.5 V |
| Clock duty cycle | 45–55% | External clock input |
| Active current | 10 mA maximum | 5.5 V, oscillator25 MHz, SPI1 MHz, SO open |
| Sleep current, I grade | 5 µA maximum | Defined inputs and CS / TXnRTS HIGH |
| Hardware reset LOW | 2 µs minimum | Then allow 128 oscillator cycles for startup |
No specifications match. Try a parameter name or a unit.
At 5 V, a 3.3 V HIGH does not meet the SPI 0.7 VDD threshold. Use compatible levels or translation.
5 V logic · 20 MHz · 125 kbit/s
Scroll sideways to see all columns.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Host SPI | SCK13, MOSI→SI14, SO15→MISO, CS16 | Start with mode0 at1 MHz |
| Host control | INT12→interrupt; RESET17→reset output | 10 kΩ pull-ups on CS and RESET |
| External oscillator | 20 MHz output→OSC1 pin8 | OSC2 pin7 open; oscillator bypass per its data |
| CAN controller/transceiver | TXCAN1→MCP2562 TXD1; RXD4→RXCAN2 | Logic connections, not bus pins |
| MCP2562 supplies | VDD3 and VIO5 to5 V; VSS2 GND | 100 nF local supply bypass; STBY8 LOW |
| Bus | MCP2562 CANH7 and CANL6 | Twisted pair; two120 Ω end terminators |
| Unused outputs | CLKOUT3, RX1BF10, RX0BF11 open | Unused TXnRTS inputs have internal pull-ups |
| Firmware | Reset, configure timing and filters, enter Normal mode | Another matching normal node must acknowledge |
No specifications match. Try a parameter name or a unit.
All ground references are common in this teaching circuit. Protection, isolation and cable length require a system-specific design.
MCP2515-I/P · PDIP-18
Scroll sideways to see all columns.
| Parameter | Value | Conditions / notes |
|---|---|---|
| PDIP-18 P | 2.54 mm pitch; 7.62 mm rows | Narrow through-hole package |
| SOIC-18 SO | 1.27 mm pitch; 7.50 mm body width | Wide SOIC, not a narrow 3.9 mm body |
| Other packages | 20-lead TSSOP / QFN | Different contact maps; not interchangeable with18-pin views |
| Supply absolute maximum | 7.0 V | Normal operation ends at5.5 V |
| I/O absolute range | −0.6 to VDD + 1.0 V | Stress limits, not recommended input levels |
| Storage temperature | −65 to +150°C | Unpowered |
No specifications match. Try a parameter name or a unit.
Review the exact orderable and fabrication allowances before using the downloadable original footprints.
Select a pin for its function, connection guidance and electrical notes.
Follow the labeled connections and functional stages
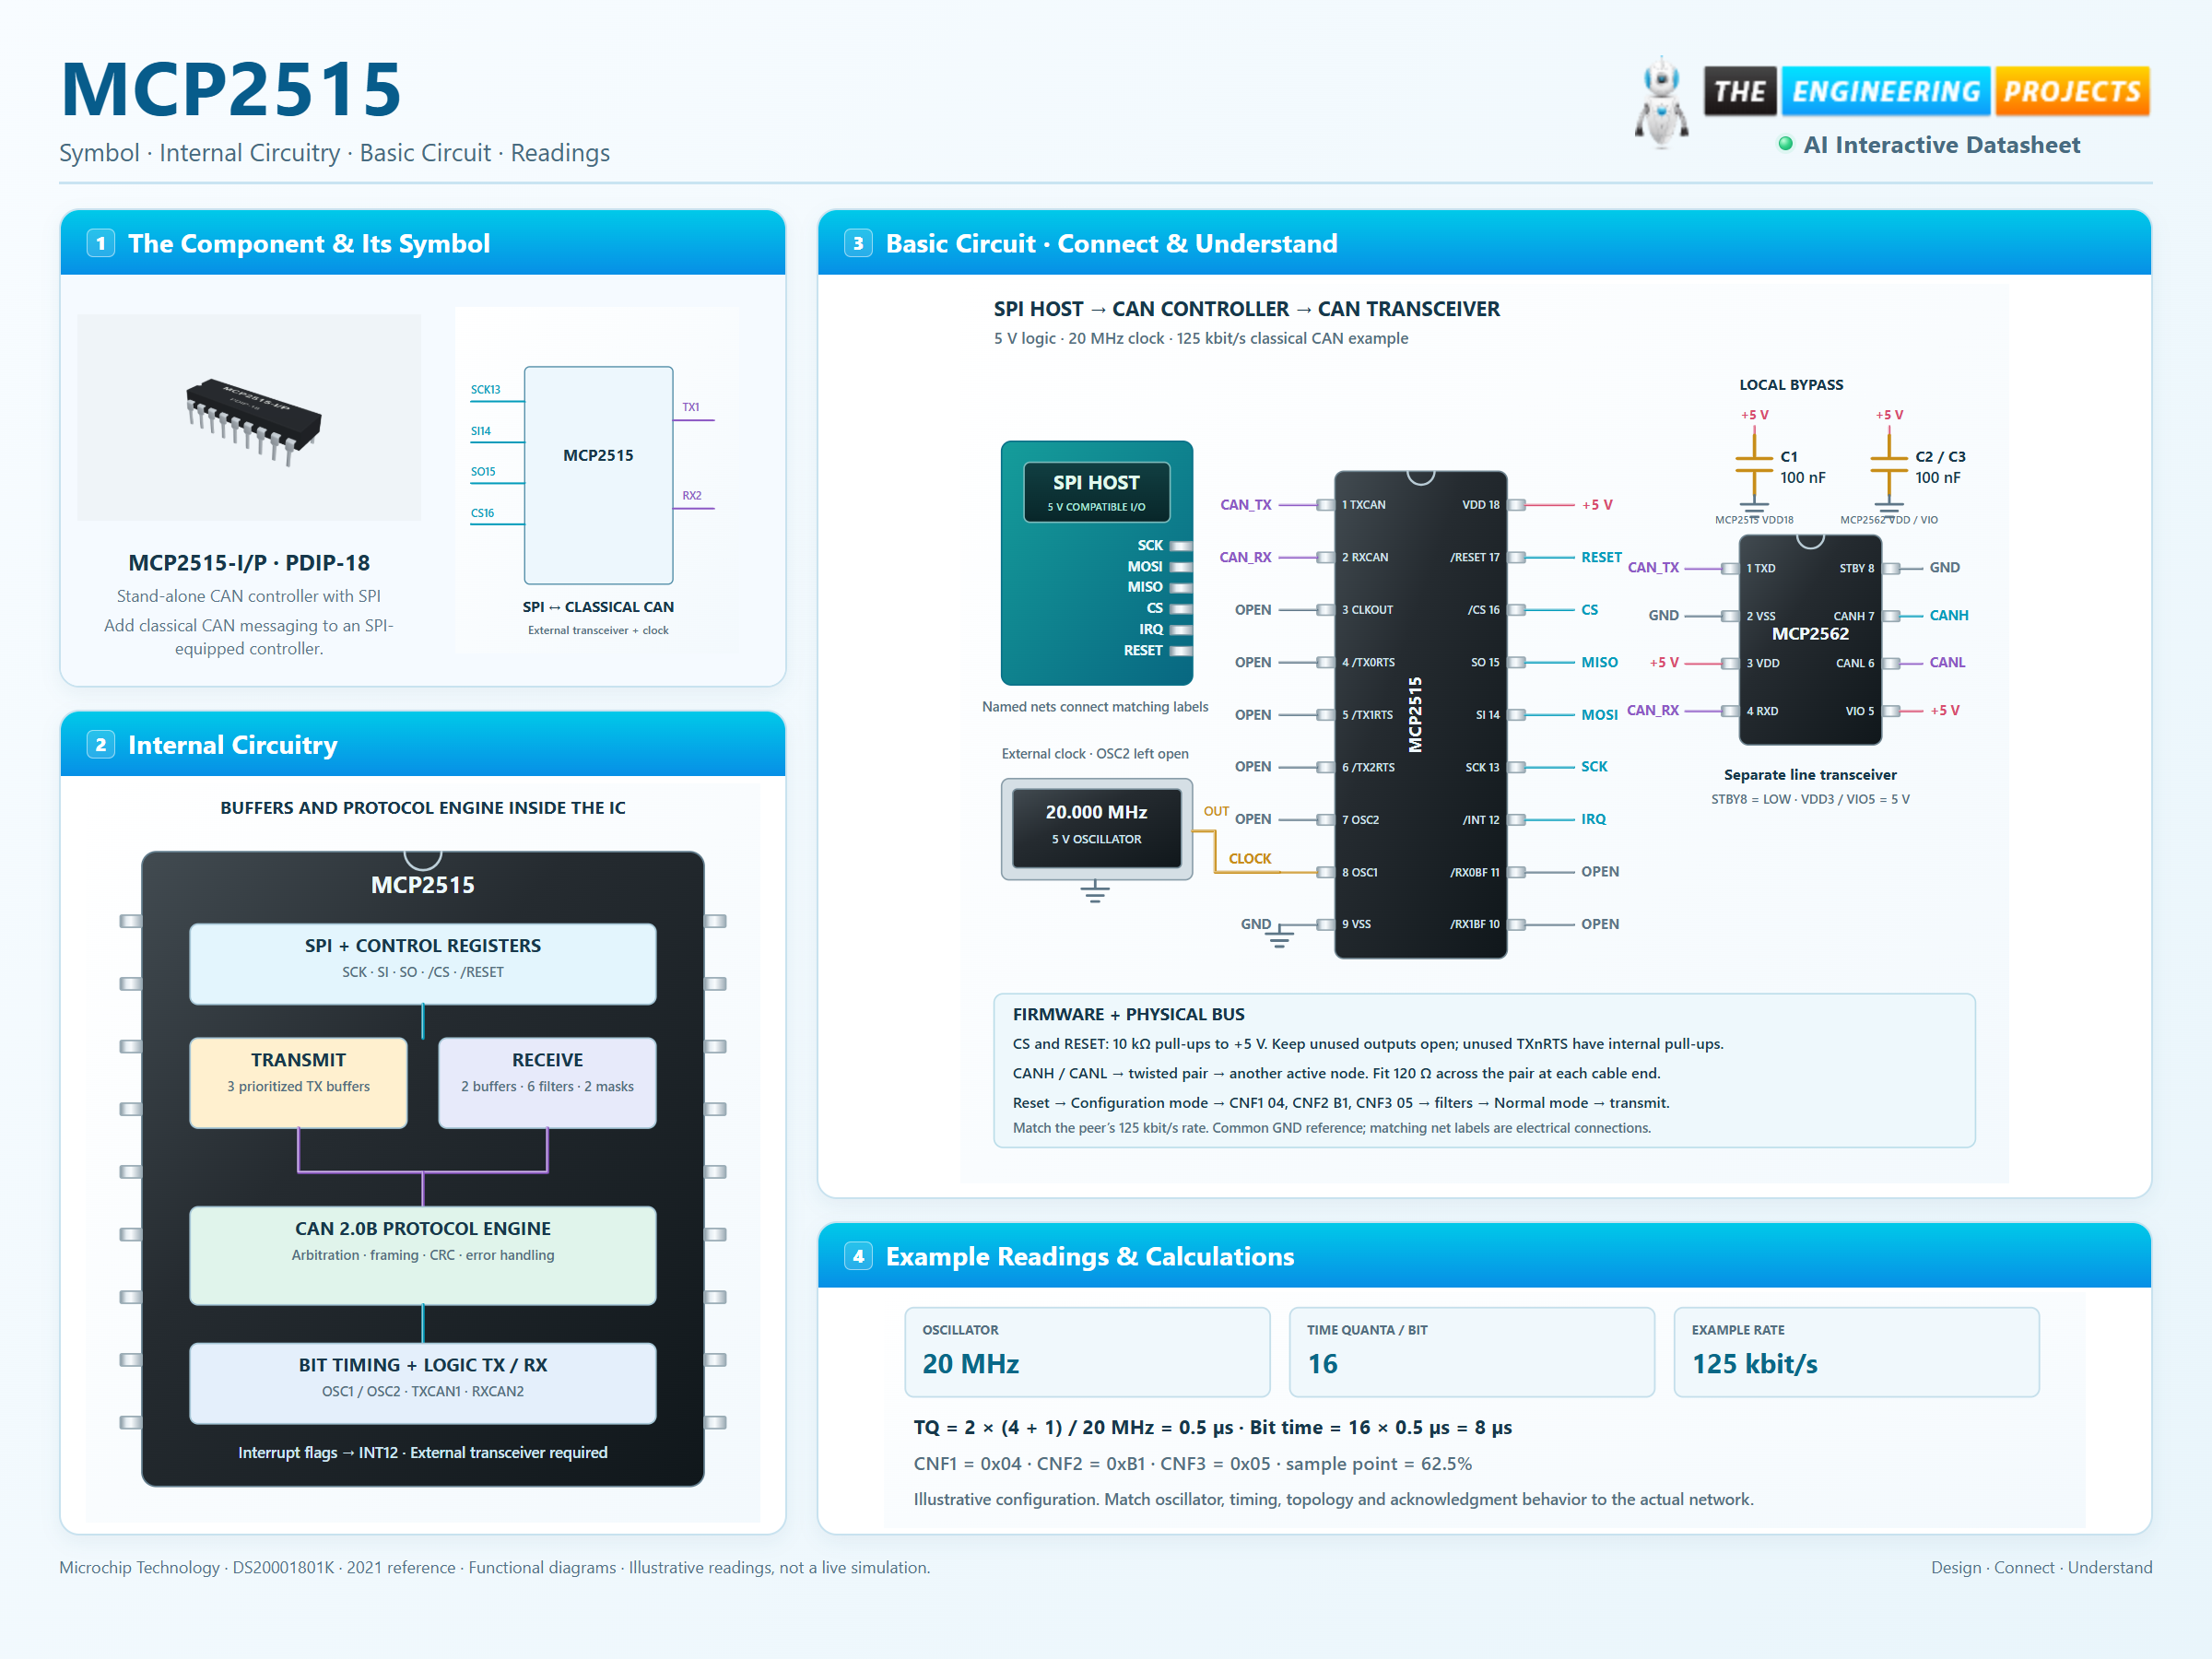
3 stages · Explore one step at a time
Reset, wait for oscillator startup and confirm Configuration mode before programming timing, masks and filters.
Load an identifier and up to eight bytes into a transmit buffer, then request transmission. The engine handles arbitration and protocol errors.
Accepted frames enter receive buffers. Enabled flags assert INT; firmware reads the message and clears or services the cause.
MCP2515 plus the separate MCP2562 bus transceiver.
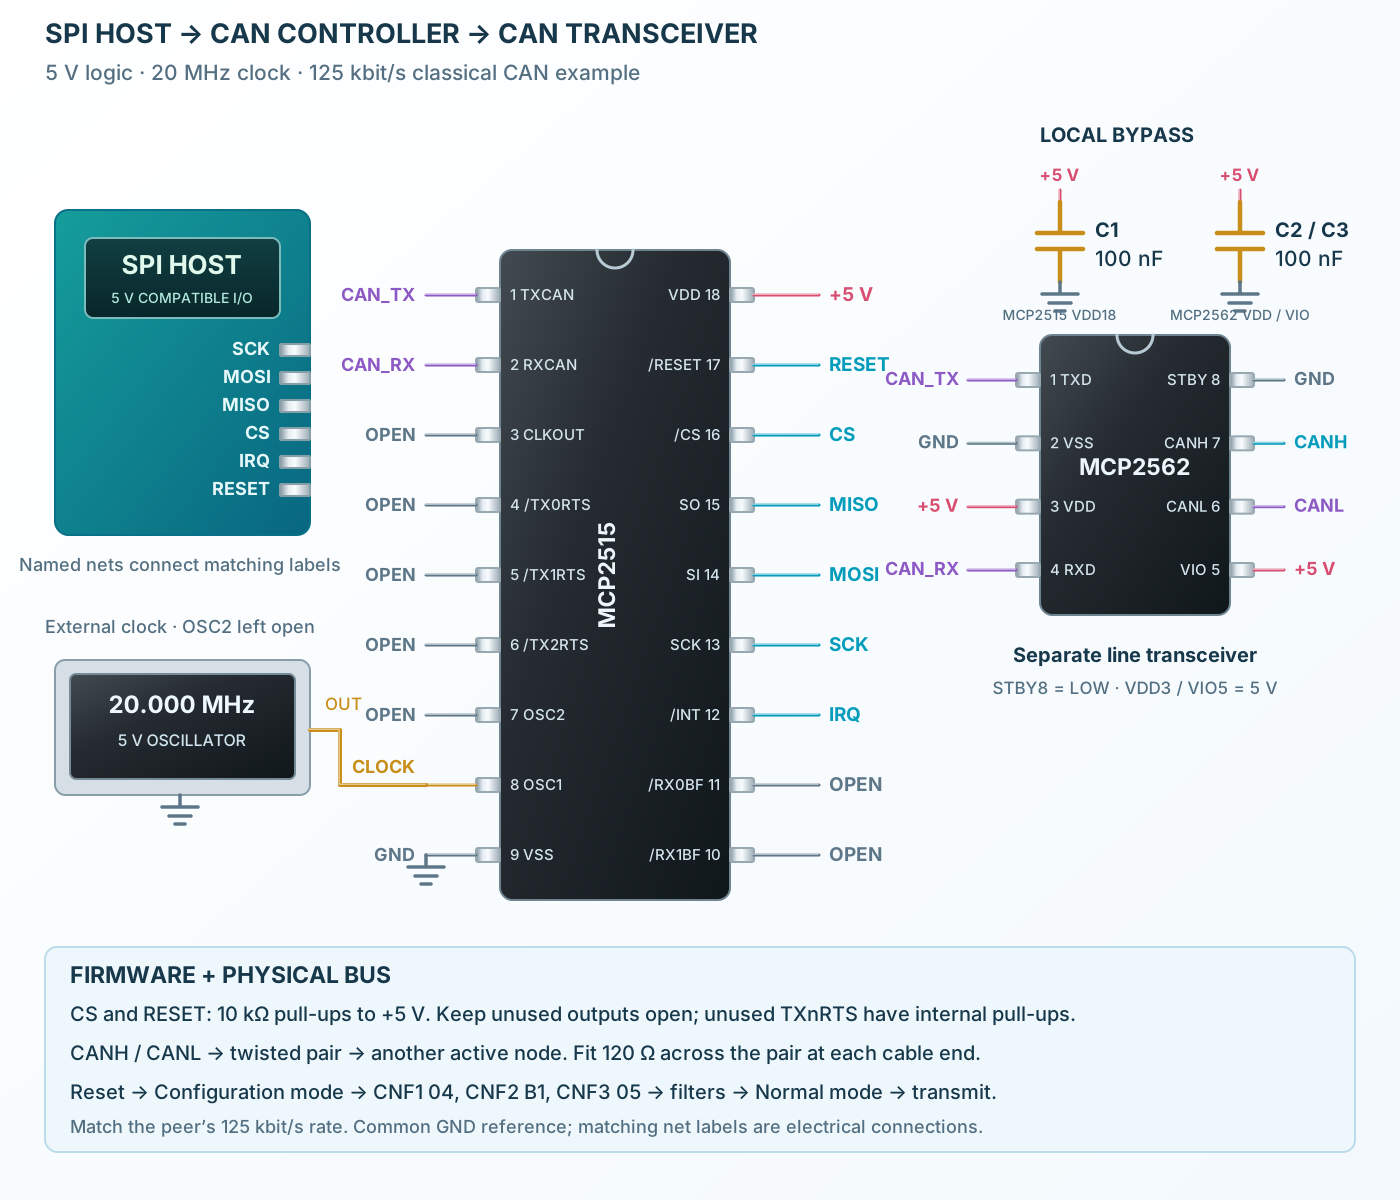
Follow the component values and pin connections
Use compatible5 V logic, local bypassing and a valid20 MHz clock.
Reset and program the125 kbit/s timing in Configuration mode before requesting Normal mode.
The external transceiver drives CANH/CANL. Terminate both cable ends and provide a matching active peer.
SPI control, buffers and a CAN engine inside the package.
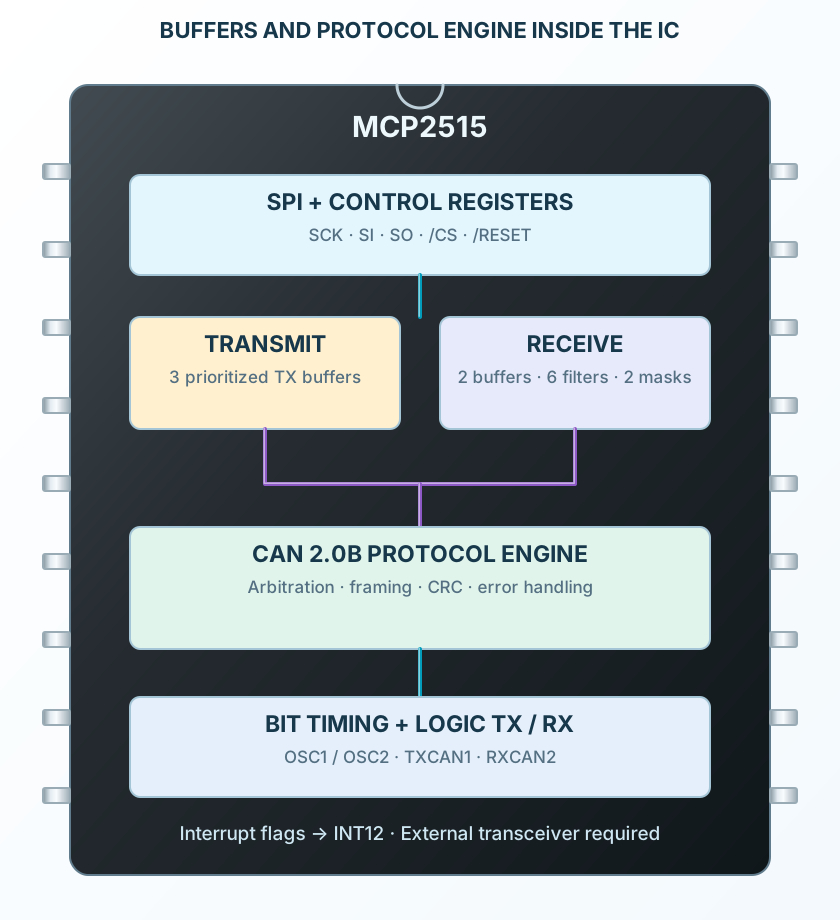
Select a stage to see its role and connections
SPI reads and writes configuration, message buffers and status.
Separate storage and acceptance logic reduce host involvement for unwanted traffic.
Oscillator-derived bit timing drives arbitration, framing, error detection and logic TX/RX.
Signal names, electrical functions and connection guidance
Scroll within the table to see all columns and rows.
| Pin | Signal | Type | Function & connection |
|---|---|---|---|
| TXCAN | Logic transmit output | Sends the CAN protocol engine’s dominant/recessive logic to a transceiver.Connection guidanceConnect to MCP2562 TXD pin 1. This is not CANH or CANL; never connect directly to the cable. | |
| RXCAN | Logic receive input | Receives the bus state from the external transceiver.Connection guidanceConnect to MCP2562 RXD pin 4. | |
| CLKOUT/SOF | Clock or start-of-frame output | Outputs a divided oscillator clock or a selected start-of-frame indication.Connection guidanceLeave open when unused. After reset the enabled clock defaults to FOSC / 8. | |
| TX0RTS̅ | Request-to-send input | Active-LOW request for transmit buffer 0, or a general-purpose input according to TXRTSCTRL.Connection guidanceLeave unconnected when unused; its internal pull-up holds it HIGH. Approximately 100 kΩ internal pull-up to VDD. | |
| TX1RTS̅ | Request-to-send input | Active-LOW request for transmit buffer 1, or a general-purpose input according to TXRTSCTRL.Connection guidanceLeave unconnected when unused; its internal pull-up holds it HIGH. Approximately 100 kΩ internal pull-up to VDD. | |
| TX2RTS̅ | Request-to-send input | Active-LOW request for transmit buffer 2, or a general-purpose input according to TXRTSCTRL.Connection guidanceLeave unconnected when unused; its internal pull-up holds it HIGH. Approximately 100 kΩ internal pull-up to VDD. | |
| OSC2 | Oscillator output | Feedback terminal for crystal/resonator operation.Connection guidanceLeave open in the external-clock example. | |
| OSC1 | Oscillator / clock input | Accepts the clock used for CAN bit timing and internal operation.Connection guidanceApply a 20 MHz, 0–5 V oscillator output with 45–55% duty cycle. | |
| VSS | Ground return | Ground for logic, clock and I/O.Connection guidanceJoin the controller, oscillator and transceiver reference. | |
| RX1BF̅ | Receive-buffer 1 flag | Configurable buffer-full indication or general-purpose output.Connection guidanceLeave open when using INT alone. | |
| RX0BF̅ | Receive-buffer 0 flag | Configurable buffer-full indication or general-purpose output.Connection guidanceLeave open when using INT alone. | |
| INT̅ | Active-LOW interrupt | Signals enabled interrupt conditions; software must inspect and service their flags.Connection guidanceConnect to a compatible controller interrupt input. | |
| SCK | SPI clock input | Clocks commands and register data; SPI modes 0 and 3 are supported.Connection guidanceConnect controller SCK; use 1 MHz for the example. | |
| SI | SPI data input | Receives instruction, address and data from the controller.Connection guidanceConnect MOSI. | |
| SO | SPI data output | Returns register and buffer data; high impedance when CS is HIGH.Connection guidanceConnect MISO. | |
| CS̅ | Active-LOW chip select | LOW starts an SPI instruction; return HIGH before the next instruction.Connection guidanceConnect a dedicated controller select and 10 kΩ pull-up to +5 V. | |
| RESET̅ | Active-LOW reset | Initializes registers and enters Configuration mode.Connection guidanceUse a 10 kΩ pull-up and controller reset output; hold LOW at least 2 µs. Allow oscillator startup before SPI access. | |
| VDD | Positive supply | Powers the CAN controller and its I/O.Connection guidanceUse +5 V with 100 nF directly to VSS9. Operating range 2.7–5.5 V; logic thresholds scale with supply. |
No pins match these filters. Try another signal name or reset the filters.
Classical CAN 2.0B
Scroll within the table to see all columns and rows.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Bus rate | Up to 1 Mbit/s | Subject to oscillator and network timing |
| Identifiers | 11-bit standard / 29-bit extended | Data and remote frames |
| Data field | 0–8 bytes | No CAN FD or bit-rate switching |
| Transmit storage | Three prioritized buffers | Abort and one-shot options |
| Receive storage | Two buffers | Priority and optional rollover |
| Acceptance | Six filters and two masks | Configure before Normal mode |
| External line interface | Required CAN transceiver | TXCAN / RXCAN are logic signals |
No specifications match. Try a parameter name or a unit.
A controller and a transceiver solve different parts of the CAN interface.
Most significant bit first · separate CS cycle per command
Scroll within the table to see all columns and rows.
| Parameter | Value | Conditions / notes |
|---|---|---|
| RESET | 0xC0 | Initialize and enter Configuration mode |
| READ | 0x03, address, dummy clocks | Consecutive register bytes may follow |
| WRITE | 0x02, address, data… | Sequential register write |
| BIT MODIFY | 0x05, address, mask, data | Only supported registers; mask 1 permits change |
| READ STATUS | 0xA0 | Frequently used RX/TX status |
| RX STATUS | 0xB0 | Received-frame type and matching filter |
| RTS buffer 0 | 0x81 | Request already-loaded TXB0 transmission |
| SPI timing | 10 MHz maximum; 50 ns CS setup/hold | Modes 0 and 3 |
No specifications match. Try a parameter name or a unit.
The controller expects an instruction immediately after CS falls. Raise CS before issuing another instruction.
Request via CANCTRL; confirm via CANSTAT
Scroll within the table to see all columns and rows.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Configuration | REQOP 100 | Required for bit timing, filters, masks and TXRTSCTRL |
| Normal | REQOP 000 | Transmit, receive and acknowledge CAN frames |
| Sleep | REQOP 001 | Oscillator stopped; wake-up conditions apply |
| Loopback | REQOP 010 | Internal communications test without bus transmission |
| Listen-only | REQOP 011 | Observe bus without transmitting or acknowledging |
| Mode confirmation | Read OPMOD bits | A request may wait for pending transmissions |
No specifications match. Try a parameter name or a unit.
Listen-only nodes do not supply the acknowledgment required for a transmitting node’s normal successful frame.
20 MHz external clock · single sample
Scroll within the table to see all columns and rows.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Oscillator period | 50 ns | 1 / 20 MHz |
| BRP register field | 4 | TQ = 2 × (BRP + 1) / FOSC |
| Time quantum | 500 ns | Prescaler division by 10 |
| Segments | Sync 1; Prop 2; PS1 7; PS2 6 | 16 TQ per bit |
| Sample point | (1 + 2 + 7) / 16 = 62.5% | At the end of Phase Segment 1 |
| Synchronization jump width | 1 TQ | Must not exceed PS2 |
| CNF1 / CNF2 / CNF3 | 0x04 / 0xB1 / 0x05 | BTLMODE=1, SAM=0; wake filter/SOF disabled |
| Result | 16 × 500 ns = 8 µs per bit | 125000 bits/s |
No specifications match. Try a parameter name or a unit.
This is the manufacturer’s illustrative timing split, not a universal network prescription. Review propagation, oscillator tolerance and the other nodes.
MCP2515-I/P and MCP2515-I/SO
Scroll within the table to see all columns and rows.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Operating supply / temperature | 2.7–5.5 V / −40 to +85°C | I grade |
| SPI input HIGH | ≥ 0.7 × VDD | SCK, SI and CS |
| SPI input LOW | ≤ 0.4 × VDD | SCK, SI and CS |
| RXCAN HIGH / LOW | ≥ 2.0 V / ≤ 0.15 × VDD | Different input thresholds from SPI |
| Reset HIGH / LOW | ≥ 0.85 × VDD / ≤ 0.15 × VDD | Schmitt reset input |
| External clock range | 1–25 MHz over 2.7–5.5 V | Up to 40 MHz at 4.5–5.5 V |
| Clock duty cycle | 45–55% | External clock input |
| Active current | 10 mA maximum | 5.5 V, oscillator25 MHz, SPI1 MHz, SO open |
| Sleep current, I grade | 5 µA maximum | Defined inputs and CS / TXnRTS HIGH |
| Hardware reset LOW | 2 µs minimum | Then allow 128 oscillator cycles for startup |
No specifications match. Try a parameter name or a unit.
At 5 V, a 3.3 V HIGH does not meet the SPI 0.7 VDD threshold. Use compatible levels or translation.
5 V logic · 20 MHz · 125 kbit/s
Scroll within the table to see all columns and rows.
| Parameter | Value | Conditions / notes |
|---|---|---|
| Host SPI | SCK13, MOSI→SI14, SO15→MISO, CS16 | Start with mode0 at1 MHz |
| Host control | INT12→interrupt; RESET17→reset output | 10 kΩ pull-ups on CS and RESET |
| External oscillator | 20 MHz output→OSC1 pin8 | OSC2 pin7 open; oscillator bypass per its data |
| CAN controller/transceiver | TXCAN1→MCP2562 TXD1; RXD4→RXCAN2 | Logic connections, not bus pins |
| MCP2562 supplies | VDD3 and VIO5 to5 V; VSS2 GND | 100 nF local supply bypass; STBY8 LOW |
| Bus | MCP2562 CANH7 and CANL6 | Twisted pair; two120 Ω end terminators |
| Unused outputs | CLKOUT3, RX1BF10, RX0BF11 open | Unused TXnRTS inputs have internal pull-ups |
| Firmware | Reset, configure timing and filters, enter Normal mode | Another matching normal node must acknowledge |
No specifications match. Try a parameter name or a unit.
All ground references are common in this teaching circuit. Protection, isolation and cable length require a system-specific design.
MCP2515-I/P · PDIP-18
Scroll within the table to see all columns and rows.
| Parameter | Value | Conditions / notes |
|---|---|---|
| PDIP-18 P | 2.54 mm pitch; 7.62 mm rows | Narrow through-hole package |
| SOIC-18 SO | 1.27 mm pitch; 7.50 mm body width | Wide SOIC, not a narrow 3.9 mm body |
| Other packages | 20-lead TSSOP / QFN | Different contact maps; not interchangeable with18-pin views |
| Supply absolute maximum | 7.0 V | Normal operation ends at5.5 V |
| I/O absolute range | −0.6 to VDD + 1.0 V | Stress limits, not recommended input levels |
| Storage temperature | −65 to +150°C | Unpowered |
No specifications match. Try a parameter name or a unit.
Review the exact orderable and fabrication allowances before using the downloadable original footprints.
No matching rowsTry a pin name, parameter, unit or test condition, or reset the filters.
Add classical CAN to a microcontroller that lacks an integrated CAN controller.
Manufacturer application guideUse listen-only mode and filtered reception to observe compatible CAN traffic.
Manufacturer application guideExchange prioritized frames with suitable transceivers, cable topology and firmware.
Manufacturer application guideFind MCP2515 in the Components Library to place its schematic symbol and connect its pins.
Reference page · circuit simulation model not yet availableOpen ProTech