Real View
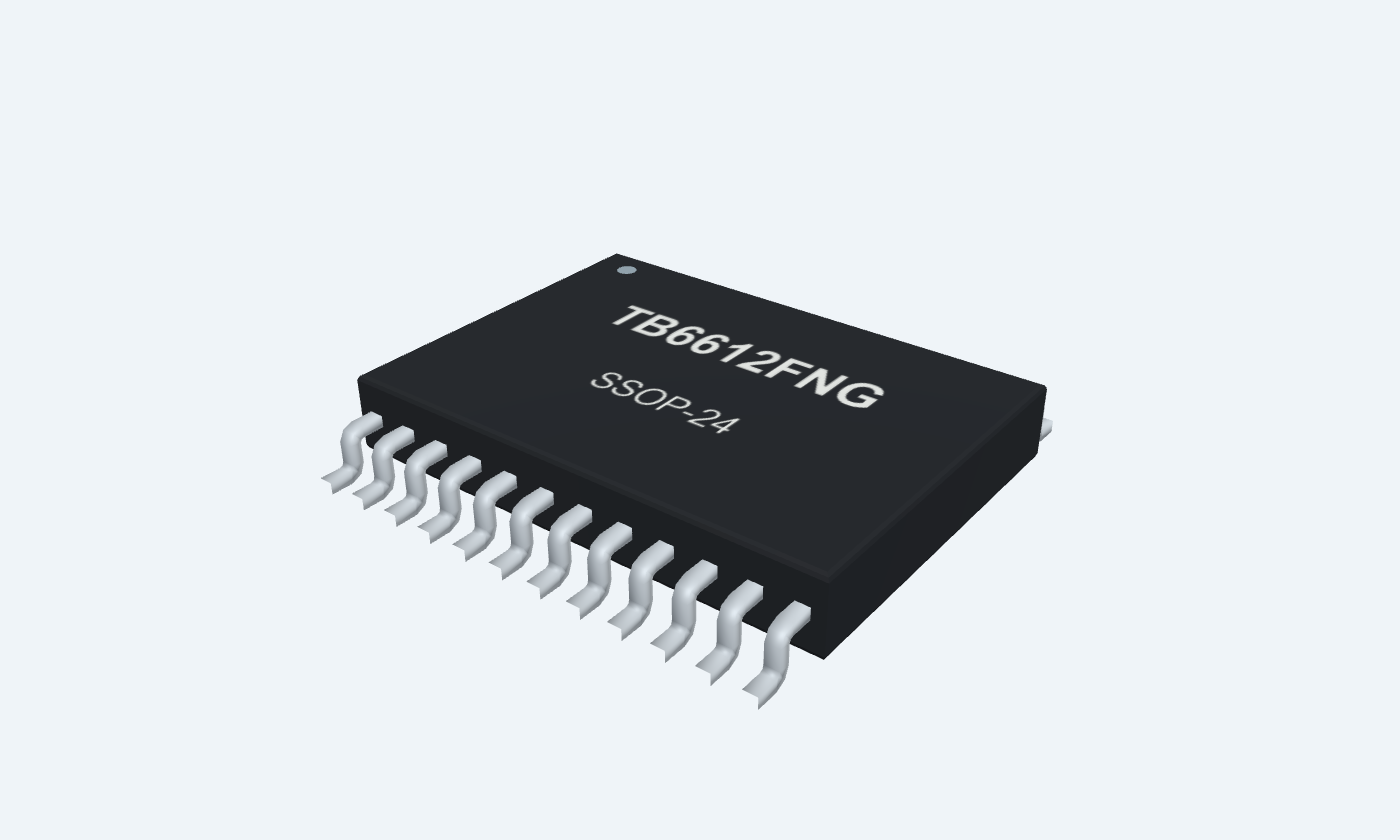
Drive, reverse, brake or coast two small motors.
TB6612FNG contains two MOS H-bridges for brushed DC motors. Each channel has two direction inputs and a PWM input; a shared STBY input disables both channels. The example uses a 5 V motor rail, 3.3 V logic and two small motors. All duplicated motor-output contacts are joined, all three VM pins are powered and every ground contact is connected. Unlike coast, short brake connects both motor terminals LOW. PWM alternates drive and brake when direction inputs are opposite. Check motor stall current and PCB heating before choosing a duty cycle.
Click a lead or use the arrow keys. Top view
Physical contact 1 of the AO1 output.
Join both AO1 contacts on the PCB; connect the motor between its channel output pairs.
Both motor terminals are switched. Do not ground one motor terminal.
Physical contact 2 of the AO1 output.
Join both AO1 contacts on the PCB; connect the motor between its channel output pairs.
Both motor terminals are switched. Do not ground one motor terminal.
Power ground for the output bridge.
Join all four PGND contacts to the supply return with low-impedance copper.
Keep motor-current paths away from small-signal ground routing.
Power ground for the output bridge.
Join all four PGND contacts to the supply return with low-impedance copper.
Keep motor-current paths away from small-signal ground routing.
Physical contact 5 of the AO2 output.
Join both AO2 contacts on the PCB; connect the motor between its channel output pairs.
Both motor terminals are switched. Do not ground one motor terminal.
Physical contact 6 of the AO2 output.
Join both AO2 contacts on the PCB; connect the motor between its channel output pairs.
Both motor terminals are switched. Do not ground one motor terminal.
Physical contact 7 of the BO2 output.
Join both BO2 contacts on the PCB; connect the motor between its channel output pairs.
Both motor terminals are switched. Do not ground one motor terminal.
Physical contact 8 of the BO2 output.
Join both BO2 contacts on the PCB; connect the motor between its channel output pairs.
Both motor terminals are switched. Do not ground one motor terminal.
Power ground for the output bridge.
Join all four PGND contacts to the supply return with low-impedance copper.
Keep motor-current paths away from small-signal ground routing.
Power ground for the output bridge.
Join all four PGND contacts to the supply return with low-impedance copper.
Keep motor-current paths away from small-signal ground routing.
Physical contact 11 of the BO1 output.
Join both BO1 contacts on the PCB; connect the motor between its channel output pairs.
Both motor terminals are switched. Do not ground one motor terminal.
Physical contact 12 of the BO1 output.
Join both BO1 contacts on the PCB; connect the motor between its channel output pairs.
Both motor terminals are switched. Do not ground one motor terminal.
One of three motor-supply contacts.
Connect VM1=24, VM2=13 and VM3=14 to the same motor rail.
Operating range 2.5–13.5 V; the 15 V absolute maximum is not a recommended operating voltage.
One of three motor-supply contacts.
Connect VM1=24, VM2=13 and VM3=14 to the same motor rail.
Operating range 2.5–13.5 V; the 15 V absolute maximum is not a recommended operating voltage.
Duty-cycle input for channel B.
Connect to a controller PWM output; use a frequency no higher than 100 kHz.
With opposite direction inputs, PWM LOW selects short brake rather than high-impedance coast.
One of the two direction controls for channel B.
Use defined HIGH/LOW logic together with PWM and STBY; see the control table.
Internal 200 kΩ pulldown. HIGH requires at least 0.7 × VCC.
One of the two direction controls for channel B.
Use defined HIGH/LOW logic together with PWM and STBY; see the control table.
Internal 200 kΩ pulldown. HIGH requires at least 0.7 × VCC.
Reference for control inputs and logic supply.
Join the common ground while keeping motor return currents out of the control path.
LOW places both channels into standby with high-impedance outputs.
Drive HIGH to operate. Keep LOW during initialization.
Internal 200 kΩ pulldown. Standby is not the short-brake mode.
Powers the small-signal control logic.
Use the controller logic rail; the example uses 3.3 V. Add local 100 nF and 10 µF bypass.
Operating range 2.7–5.5 V. Input thresholds track VCC.
One of the two direction controls for channel A.
Use defined HIGH/LOW logic together with PWM and STBY; see the control table.
Internal 200 kΩ pulldown. HIGH requires at least 0.7 × VCC.
One of the two direction controls for channel A.
Use defined HIGH/LOW logic together with PWM and STBY; see the control table.
Internal 200 kΩ pulldown. HIGH requires at least 0.7 × VCC.
Duty-cycle input for channel A.
Connect to a controller PWM output; use a frequency no higher than 100 kHz.
With opposite direction inputs, PWM LOW selects short brake rather than high-impedance coast.
One of three motor-supply contacts.
Connect VM1=24, VM2=13 and VM3=14 to the same motor rail.
Operating range 2.5–13.5 V; the 15 V absolute maximum is not a recommended operating voltage.
Dual brushed-DC motor driver
Direction logic selects which MOS switches conduct. PWM alternates drive and short brake; standby releases both outputs. Separate logic and motor rails share a ground reference.
TB6612FNG
Key parameters and their test conditions
Follows the selected physical package
Select a pin to open its function, electrical notes and wiring guidance.
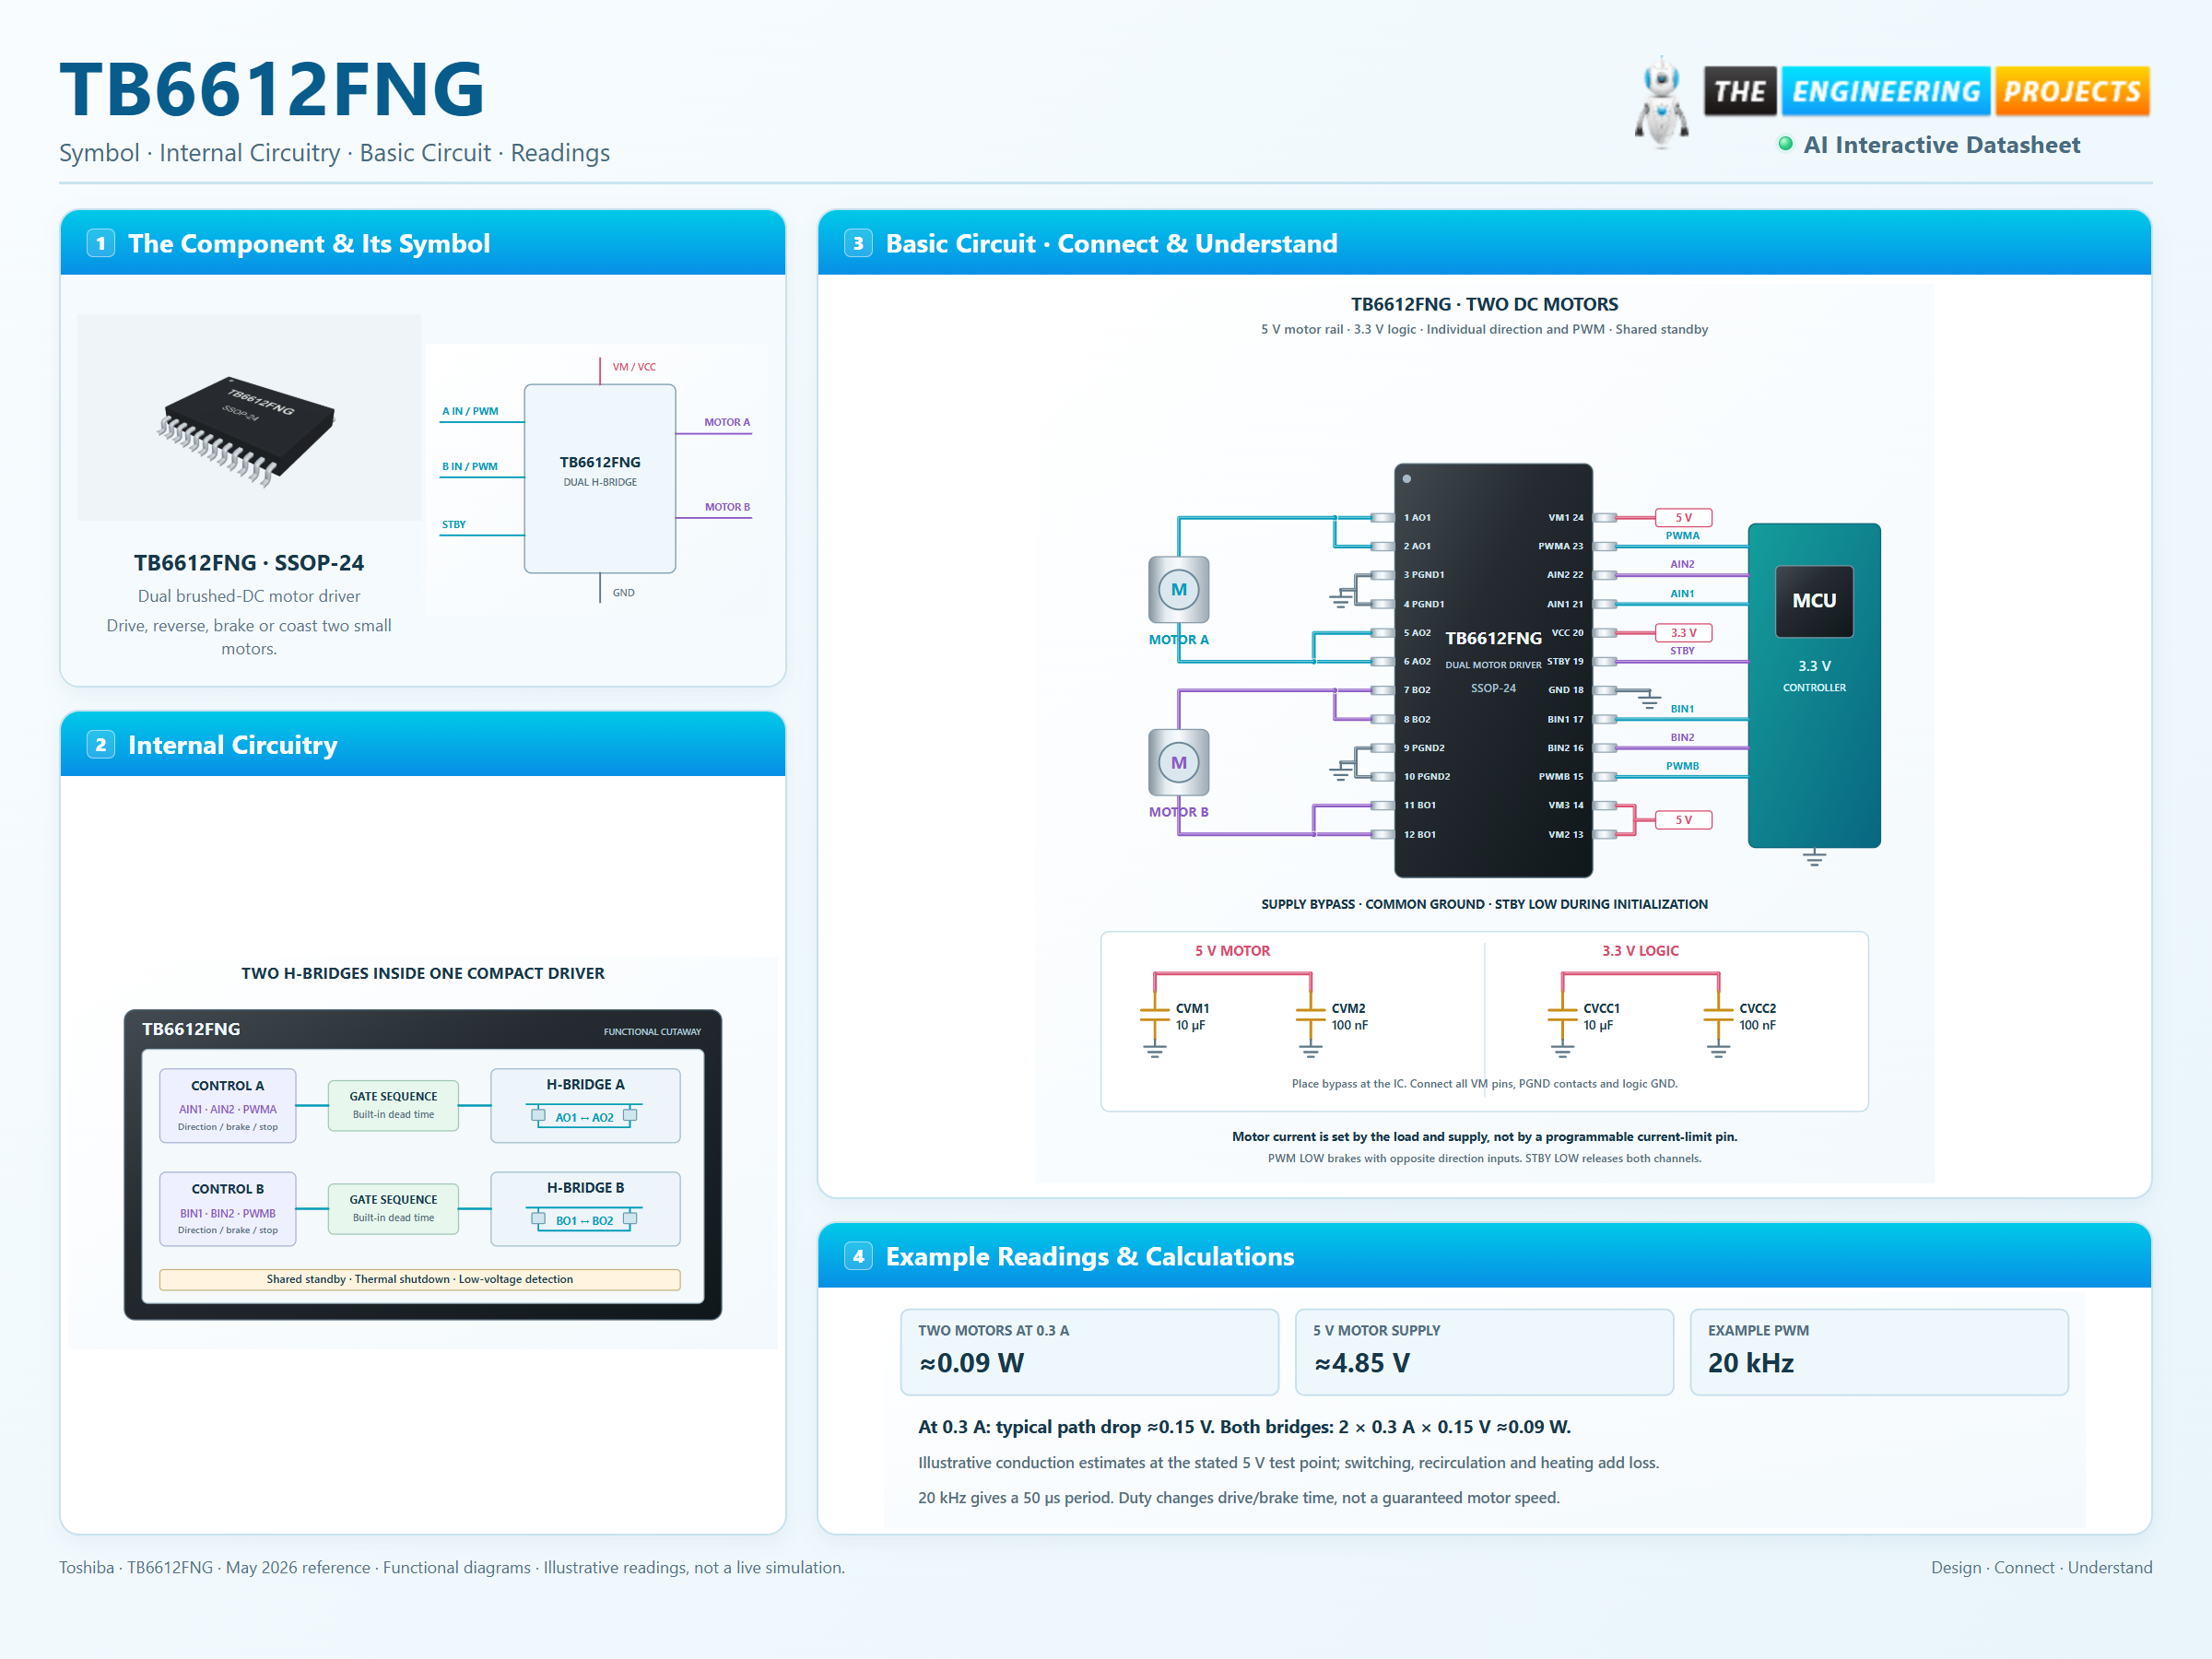
Set opposite IN1/IN2 levels for one direction, then reverse them for the other.
With STBY HIGH, PWM alternates powered drive and low-side short brake.
The motor, supply and switching losses determine current. This IC has no external current-limit adjustment.
Drive polarity follows IN1/IN2 only while PWM and STBY are HIGH. PWM LOW brakes for opposite direction inputs; STBY LOW releases the outputs.
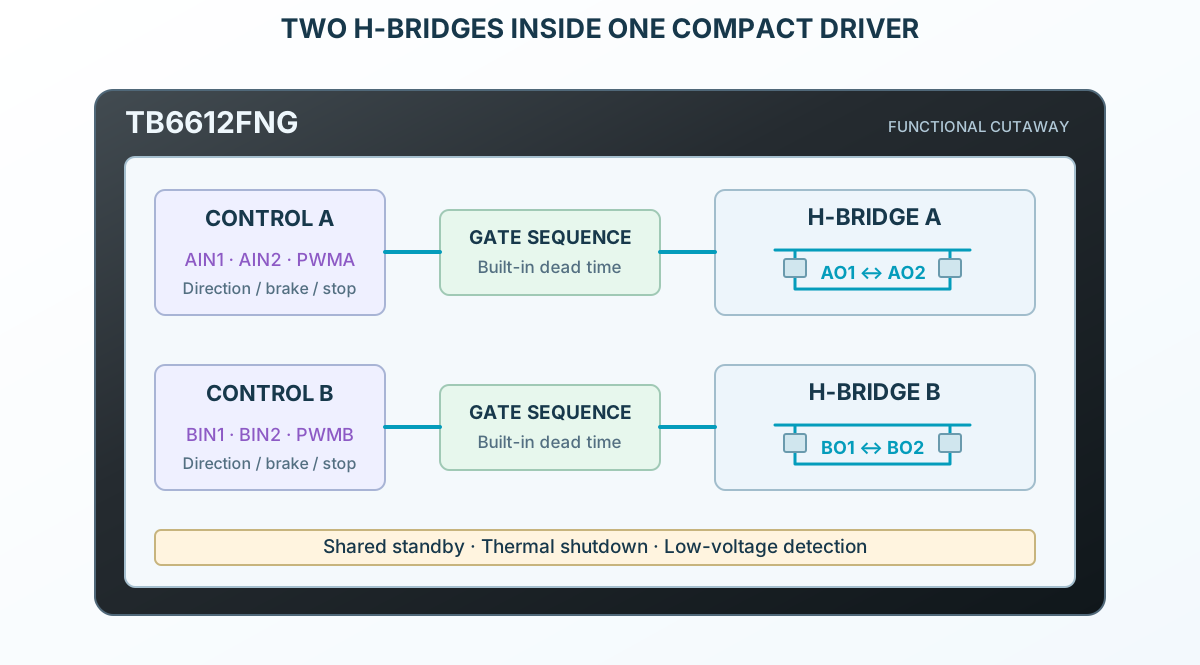
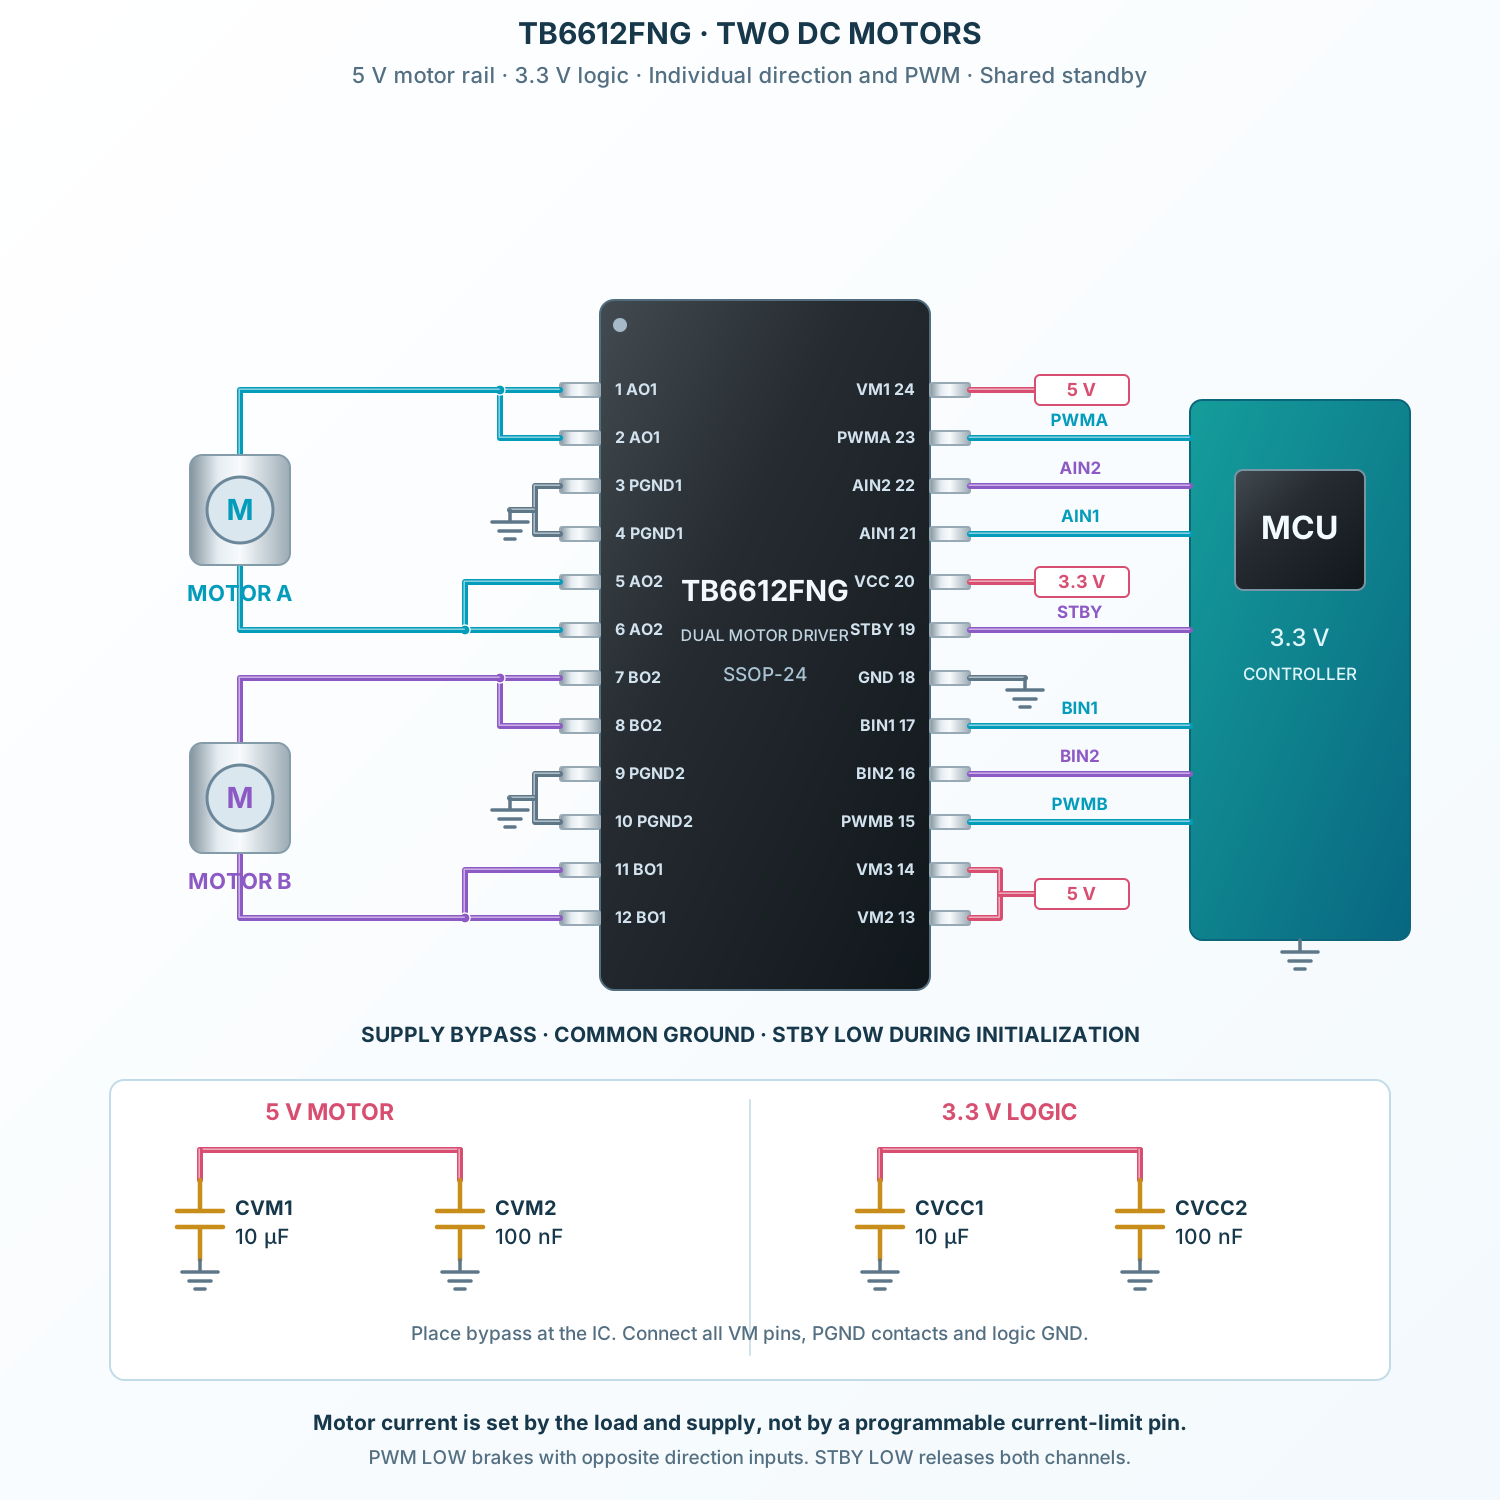
Select a pin to explore its function and connection.
| Pin | Signal | Type | Function |
|---|---|---|---|
| AO1 | Motor output | Physical contact 1 of the AO1 output. | |
| AO1 | Motor output | Physical contact 2 of the AO1 output. | |
| PGND1 | Motor-current return | Power ground for the output bridge. | |
| PGND1 | Motor-current return | Power ground for the output bridge. | |
| AO2 | Motor output | Physical contact 5 of the AO2 output. | |
| AO2 | Motor output | Physical contact 6 of the AO2 output. | |
| BO2 | Motor output | Physical contact 7 of the BO2 output. | |
| BO2 | Motor output | Physical contact 8 of the BO2 output. | |
| PGND2 | Motor-current return | Power ground for the output bridge. | |
| PGND2 | Motor-current return | Power ground for the output bridge. | |
| BO1 | Motor output | Physical contact 11 of the BO1 output. | |
| BO1 | Motor output | Physical contact 12 of the BO1 output. | |
| VM2 | Motor supply | One of three motor-supply contacts. | |
| VM3 | Motor supply | One of three motor-supply contacts. | |
| PWMB | PWM command | Duty-cycle input for channel B. | |
| BIN2 | Direction command | One of the two direction controls for channel B. | |
| BIN1 | Direction command | One of the two direction controls for channel B. | |
| GND | Small-signal ground | Reference for control inputs and logic supply. | |
| STBY | Active-LOW standby | LOW places both channels into standby with high-impedance outputs. | |
| VCC | Logic supply | Powers the small-signal control logic. | |
| AIN1 | Direction command | One of the two direction controls for channel A. | |
| AIN2 | Direction command | One of the two direction controls for channel A. | |
| PWMA | PWM command | Duty-cycle input for channel A. | |
| VM1 | Motor supply | One of three motor-supply contacts. |
No pins match. Try a signal name or choose All pins.
Recommended conditions versus absolute ratings
| Parameter | Value | Conditions / notes |
|---|---|---|
| VM motor rail | 2.5–13.5 V | 5 V example; allow margin for regenerated energy |
| VCC logic rail | 2.7–5.5 V | 3.3 V example |
| Output current, no PWM | 1.0 A maximum | Operating table at VM ≥4.5 V |
| Output current, low VM | 0.4 A maximum | Operating table at 2.5 V ≤ VM <4.5 V, without PWM |
| PWM switching | Up to 100 kHz | Use a suitable controller and motor |
| Ambient range | −20°C to +85°C | Derate power as ambient rises |
| Absolute motor / logic supply | 15 V / 6 V | Stress limits, not operating setpoints |
| Absolute current headline | 1.2 A per channel | Thermal and pulse conditions still apply |
No specifications match. Try a parameter name or a unit.
Supply levels, current, duty cycle and PCB thermal design must be considered together.
Control inputs are referenced to VCC
| Parameter | Value | Conditions / notes |
|---|---|---|
| HIGH / LOW thresholds | ≥0.7×VCC / ≤0.3×VCC | At 3.3 V: ≥2.31 V / ≤0.99 V |
| Input pulldowns | 200 kΩ nominal | IN1, IN2, PWM and STBY |
| Logic supply current | 1.1 mA typical; 1.8 mA maximum | VCC=3 V, VM=5 V, STBY=HIGH |
| Standby logic current | 1 µA maximum | STBY=LOW |
| Standby motor-rail current | 1 µA maximum | Specified standby conditions |
| Input HIGH current | 5 / 15 / 25 µA | Minimum / typical / maximum at VIN=3 V |
No specifications match. Try a parameter name or a unit.
A 3.3 V controller is directly compatible when VCC is also 3.3 V.
Tuple order: IN1 · IN2 · PWM · STBY
| Parameter | Value | Conditions / notes |
|---|---|---|
| HIGH LOW HIGH HIGH | OUT1 HIGH; OUT2 LOW | One drive polarity |
| LOW HIGH HIGH HIGH | OUT1 LOW; OUT2 HIGH | Opposite drive polarity |
| Opposite inputs; PWM LOW; STBY HIGH | Both outputs LOW | Short brake during the PWM off interval |
| HIGH HIGH; PWM either; STBY HIGH | Both outputs LOW | Short brake |
| LOW LOW HIGH HIGH | Both outputs high impedance | Stop / coast |
| Any inputs; STBY LOW | Both outputs high impedance | Standby |
| Other combinations | Use the documented control states | Do not assign behavior from a different driver truth table |
No specifications match. Try a parameter name or a unit.
CW/CCW depends on motor wiring; the electrical polarity is the useful invariant.
Do not treat a peak-current rating as continuous current
| Parameter | Value | Conditions / notes |
|---|---|---|
| Drive-path drop at 1 A | 0.5 V typical; 0.7 V maximum | VCC=VM=5 V, total upper + lower switches |
| Drive-path drop at 0.3 A | 0.15 V typical; 0.21 V maximum | VCC=VM=5 V |
| One-channel estimate at 1 A | 0.5 W typical conduction | Before switching losses and temperature rise |
| Two-channel estimate at 0.3 A each | 0.09 W typical conduction | 2×0.3 A×0.15 V; illustrative calculation |
| Absolute pulsed current | 2 A, 20 ms, duty ≤20% | Specified continuous-pulse condition |
| Absolute single pulse | 3.2 A, 10 ms | Not a continuous operating value |
| Dissipation at 25°C | 0.78 / 0.89 / 1.36 W | IC only / specified 50×50 mm PCB / specified 76.2×114.3 mm PCB |
| Thermal shutdown / hysteresis | 175°C / 20°C | Design targets, not guaranteed operating temperatures |
| Low-voltage detect / recovery | 1.9 V / 2.2 V | Design-target values |
No specifications match. Try a parameter name or a unit.
Choose motor stall current and protection so normal operation remains within electrical and thermal limits.
5 V motor supply and 3.3 V controller
| Parameter | Value | Conditions / notes |
|---|---|---|
| Motor A | AO1 pins 1+2; AO2 pins 5+6 | Join each duplicated pair before the motor |
| Motor B | BO1 pins 11+12; BO2 pins 7+8 | Both terminals are driven |
| Motor rail | VM1=24, VM2=13, VM3=14 | Connect all three to 5 V |
| Logic rail | VCC=20 | Connect 3.3 V; controller uses the same level |
| Supply bypass | 10 µF + 100 nF on each rail | Place close to the IC and keep loop area small |
| Ground | PGND1=3+4, PGND2=9+10, GND=18 | Common return with sensible current routing |
| Channel A controls | AIN1=21, AIN2=22, PWMA=23 | Defined controller outputs |
| Channel B controls | BIN1=17, BIN2=16, PWMB=15 | Defined controller outputs |
| Global standby | STBY=19 | Keep LOW until controller initialization is complete |
No specifications match. Try a parameter name or a unit.
Duplicate output pins are physical contacts of the same node, not independently controlled outputs.
Bare IC, not a breakout-board header
| Parameter | Value | Conditions / notes |
|---|---|---|
| Package name | SSOP24-P-300-0.65A | Surface mount; 24 gull-wing leads |
| Molded body | 5.6×7.8 mm nominal | Package length may reach 8.3 mm overall |
| Lead pitch / span | 0.65 mm / 7.6 mm nominal | Pin 1 marked by the top-view dot |
| Height | 1.6 mm maximum | Follow seating-plane and assembly tolerances |
| Original copper lands | 1.50×0.40 mm | 7.00 mm row centers; check assembly process |
| Exposed pad | None in this package | Do not add a fictitious center contact |
| Footprint download | KiCad .kicad_mod | Original authored footprint with all 24 pad numbers |
No specifications match. Try a parameter name or a unit.
Mechanical reference: Toshiba package drawing; the download is an original land-pattern interpretation.
Command independent left and right drive motors.
Manufacturer application guideReverse a motor and choose brake or coast deliberately.
Manufacturer application guideObserve drive/brake intervals without assuming an exact motor speed from duty alone.
Manufacturer application guideFind TB6612FNG in the Components Library to place its schematic symbol and connect its pins.
Reference page · circuit simulation model not yet availableOpen ProTech