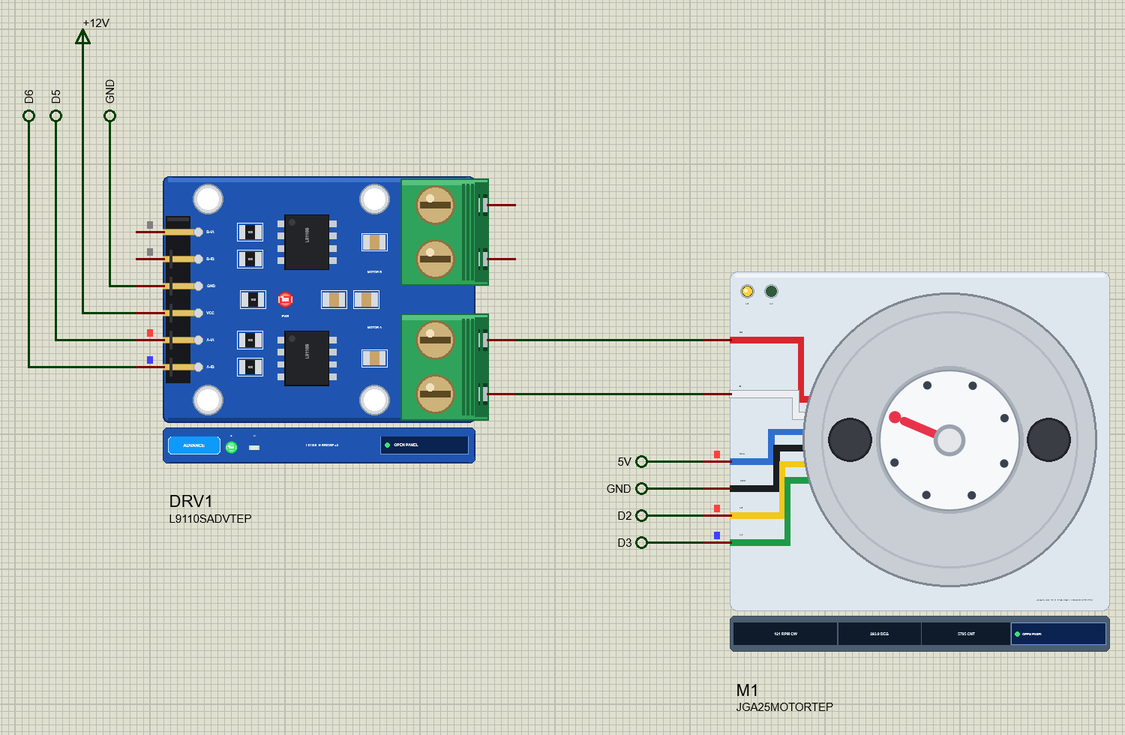
Hello friends, I hope you all are doing great. Today, I am going to share the new JGA25-370 Encoder Gear Motor Library for Proteus V1.0 . If the N20 is the motor of small robots, the JGA25-370 is the motor of the next size up: robot cars that carry a battery pack, two-wheel balancing robots, small conveyors and camera sliders. A 370-size motor behind a round 25 mm metal gearbox, 12 V, and on its back a Hall encoder that tells your Arduino exactly how far and how fast the shaft has turned. Updates JGA25-370 Encoder Gear Motor Library for Proteus Latest version: V1.0 (October 2026, this tutorial) Other motors: SG90 Servo · TT Gear Motor · 28BYJ-48 Stepper · NEMA 17 Stepper · MG996R Servo · N20 Encoder Motor · FS90R 360 Servo · 130 DC Motor · A2212 Brushless · X27.168 Gauge · Analog Panel Met ...
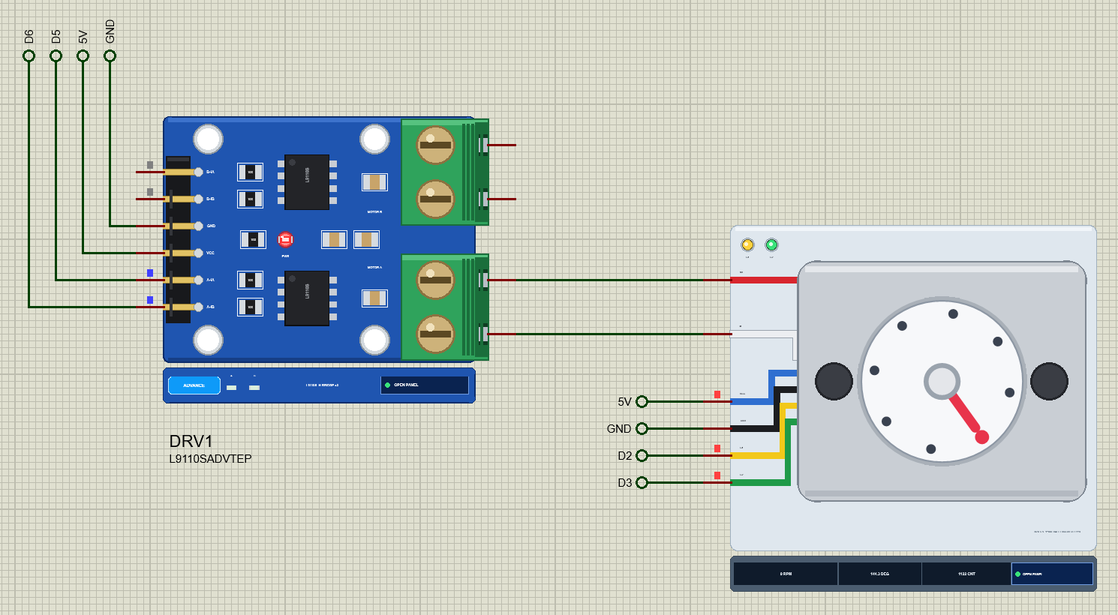
Hello friends, I hope you all are doing great. Today, I am going to share the new N20 Encoder Gear Motor Library for Proteus V1.0 . The N20 is the tiny metal gear motor of line followers, small robot arms and balancing toys: a motor no bigger than a sugar cube with a gearbox in front and, in the version everybody wants for projects, a small encoder board on its back. That encoder is what turns a plain motor into something your Arduino can steer to an exact angle or hold at an exact speed, and it is the part that matters most in this library. Updates N20 Encoder Gear Motor Library for Proteus Latest version: V1.0 (October 2026, this tutorial) Other motors: SG90 Servo · TT Gear Motor · 28BYJ-48 Stepper · NEMA 17 Stepper · MG996R Servo · JGA25-370 Encoder Motor · FS90R 360 Servo · 130 DC Moto ...