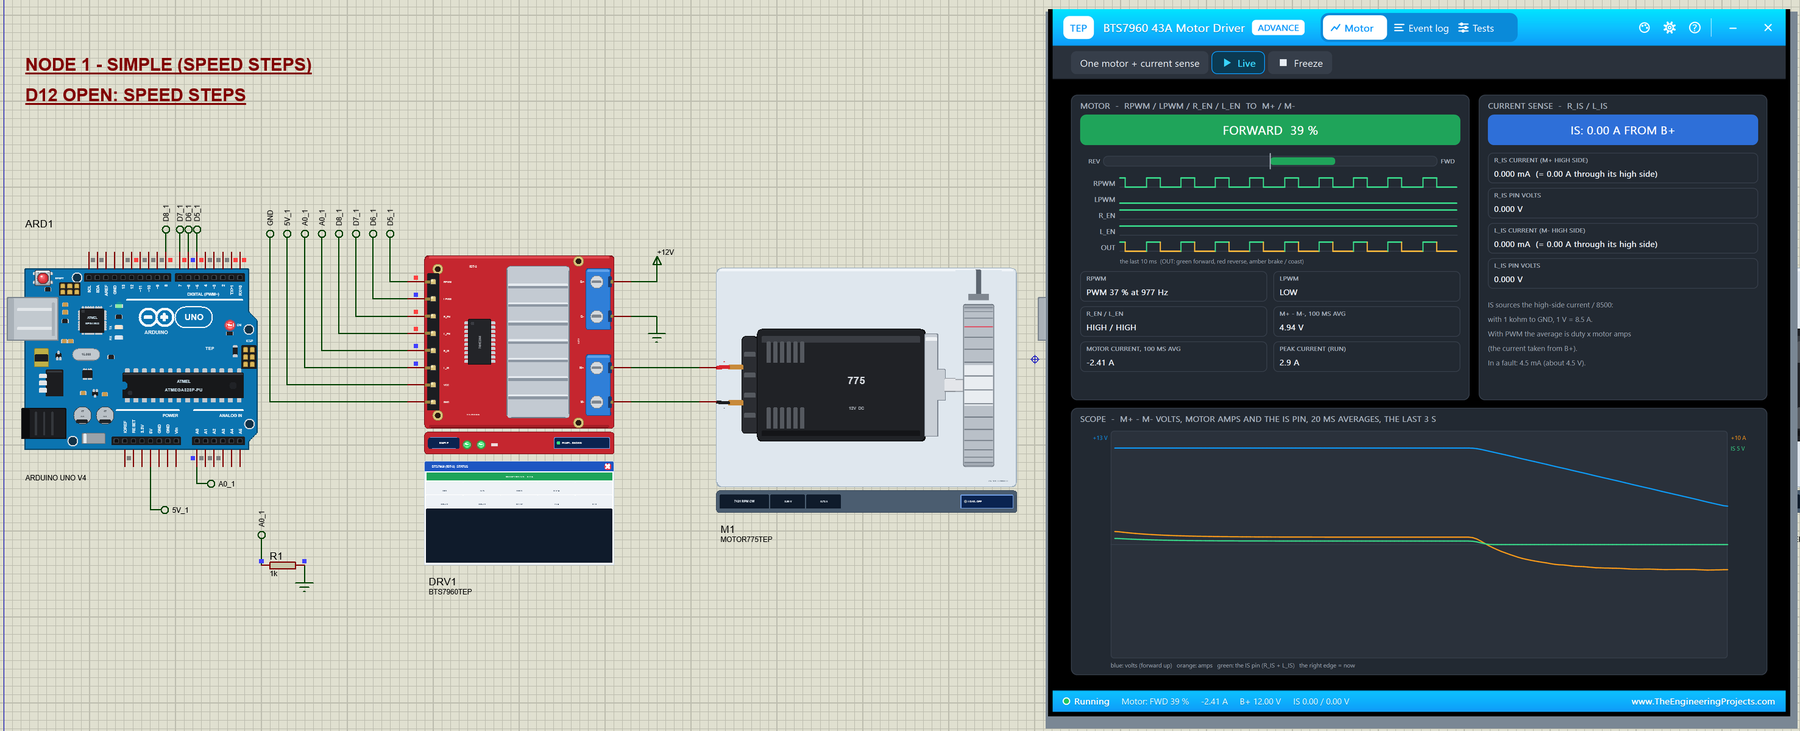
Hello friends, I hope you all are doing great. Today, I am going to share the new BTS7960 Motor Driver Library for Proteus V1.0 . When a small motor driver is not enough, makers reach for the IBT-2: a red board under a big aluminium heatsink with two BTS7960 half-bridges that switch up to 43 A. It runs the 12 V and 24 V motors of big robots, electric carts, winches and wiper motors, and it can tell your Arduino how much current flows. Now it is ready for your Proteus simulations, together with a 12 V 775 DC motor with a flywheel. Behind the board sits our own model of the IBT-2 : the two half-bridges with their 16 mohm switches, the enables, braking on the low or the high side, coasting, PWM speed control and, most important, the current sense outputs R_IS and L_IS that a real BTS7960 give ...
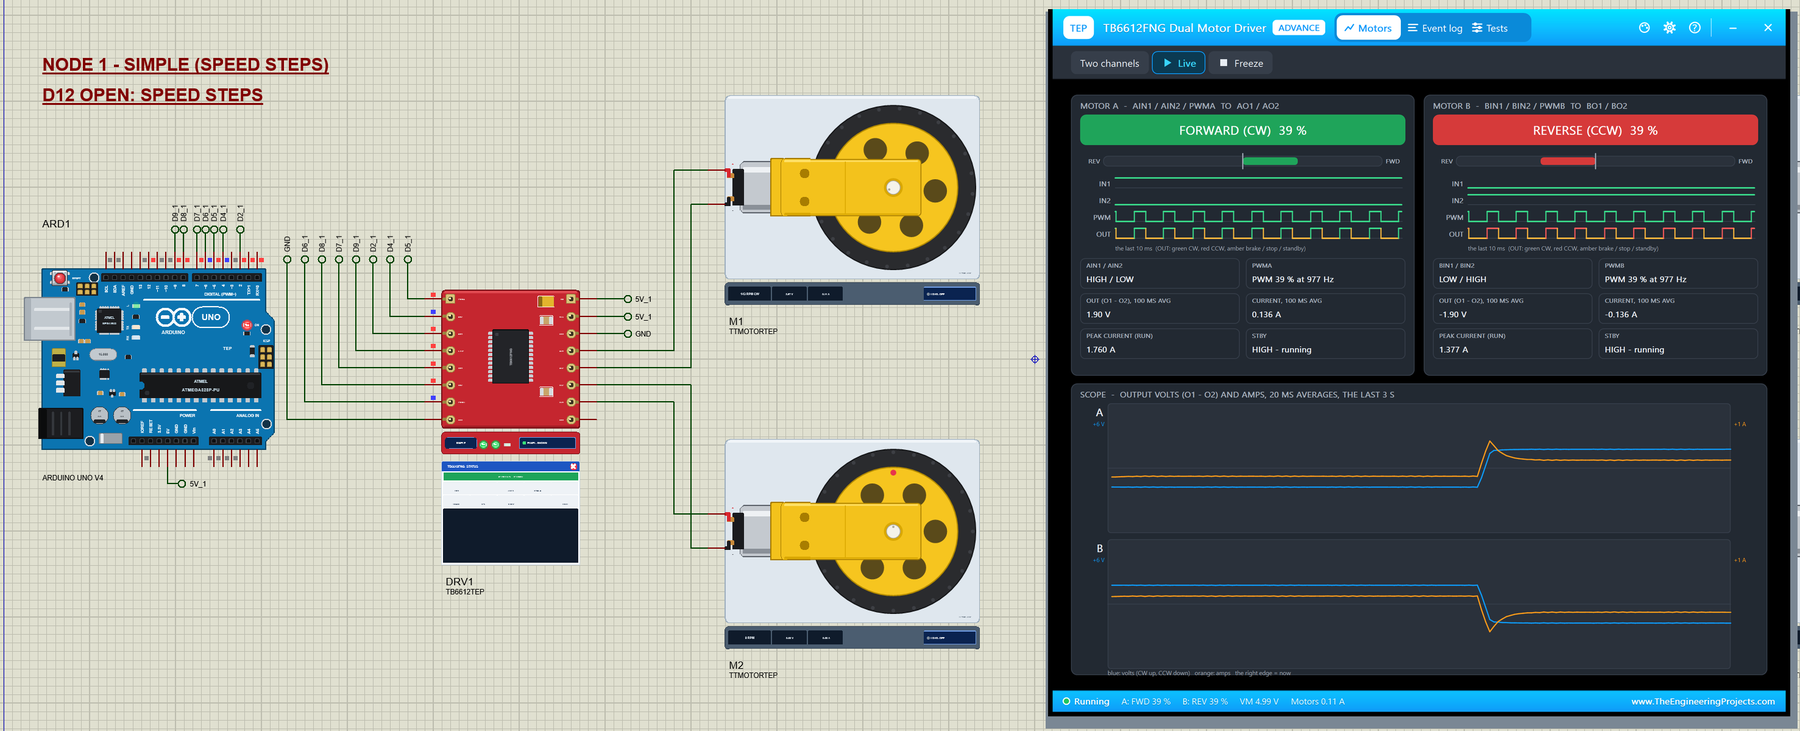
Hello friends, I hope you all are doing great. Today, I am going to share the new TB6612FNG Motor Driver Library for Proteus V1.0 . The TB6612FNG is the motor driver many makers move to after the L298N: a tiny breakout with Toshiba's dual H-bridge chip that runs two DC motors from an Arduino, wastes almost no voltage and needs no heat sink. It has a standby pin, a separate PWM pin for each motor and two kinds of stop, and now all of it works in your Proteus simulations, together with the yellow TT gear motor of a robot car. Behind the board sits our own model of the TB6612FNG : the complete truth table of the chip, the internal pull-down resistors, standby, MOSFET outputs that are real analog H-bridges and take real current, PWM speed control, the short brake and the stop. The motor is a m ...
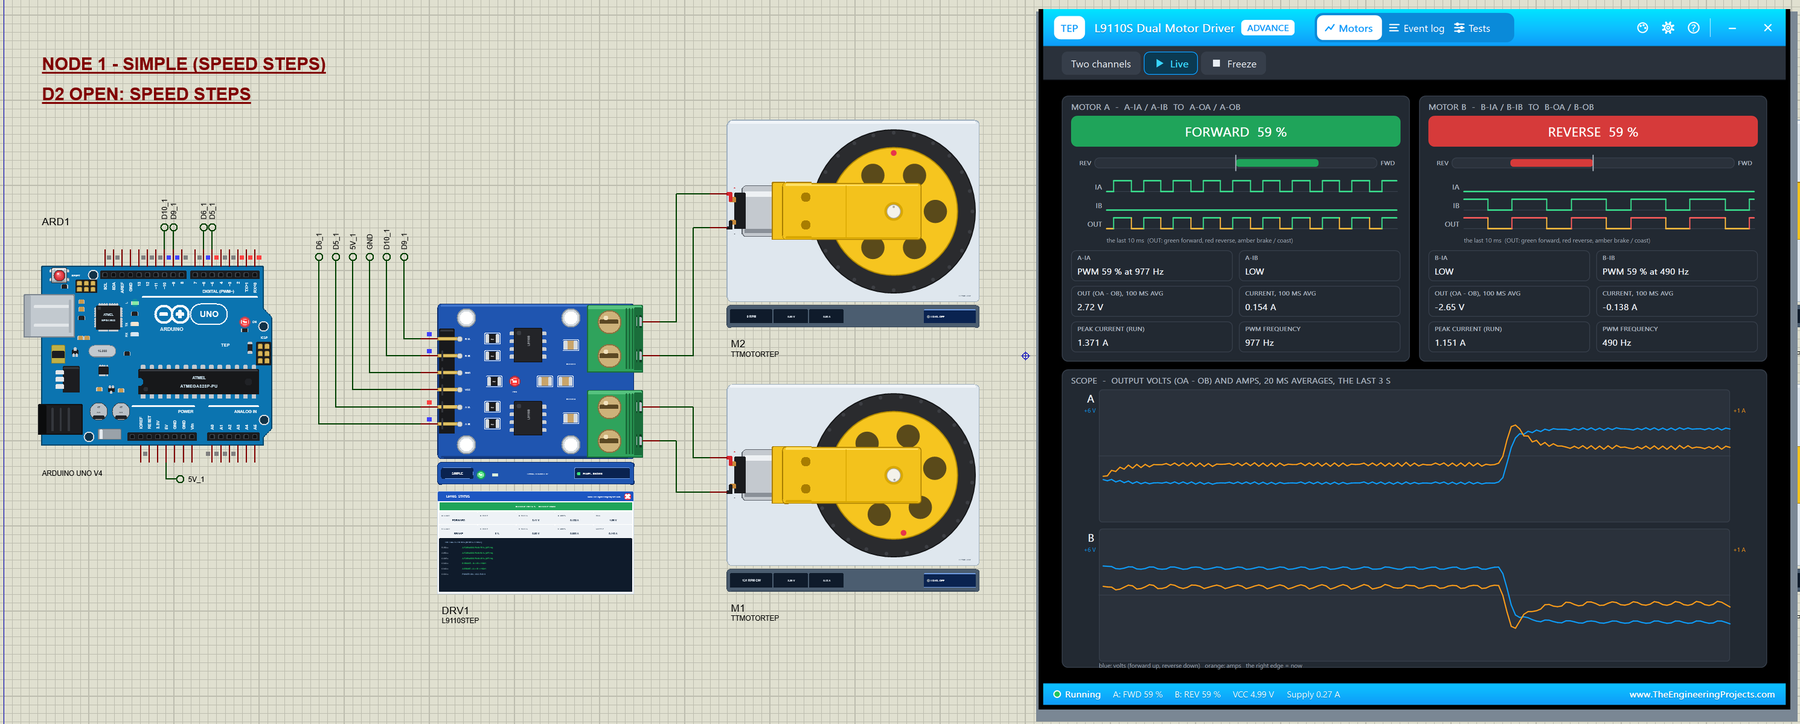
Hello friends, I hope you all are doing great. Today, I am going to share the new L9110S Motor Driver Library for Proteus V1.0 . The L9110S is the smallest and cheapest way to run two DC motors from an Arduino: a thumb-sized blue board with two H-bridge chips, two screw terminals and six pins. It sits in countless robot cars, and now it is ready for your Proteus simulations, together with the yellow TT gear motor it is usually paired with. Behind the board sits our own model of the L9110S : the truth table of the chip, the pull-up resistors of the board, outputs that are real analog H-bridges and take real current, PWM speed control, braking and coasting. The motor is a model too, with resistance, back-EMF, friction and inertia, so its wheel turns at the speed a real TT motor would. You ge ...