


Project Files of Rotary Inverted Pendulum Lab Library for Proteus
 Libraries
 Code
 Projects
 Simulation
rotary-inverted-pendulum-tep-v1-0-af6e110a801d4333b9d796e005afb069.zip

Rotary Inverted Pendulum Library for Proteus V1.0
Rotary Inverted Pendulum Library for Proteus V1.0 comes as a ZIP archive of 10 files (1.2 MB, 2.7 MB unpacked) holding Proteus library files, simulation model DLLs, a Proteus simulation, an Arduino sketch and compiled HEX firmware.
- LIBProteus library
- DLLProteus model
- DSNProteus simulation
- INOArduino sketch
- HEXHEX firmware
Description
Rotary-Inverted-Pendulum-Lab-Library-for-Proteus-v1.0.zip with a rotary inverted pendulum control lab for Proteus (a 12 V coreless motor, an 80 mm arm, a 100 mm pendulum, two 1024-line encoders, an H-bridge; a pop-up with the linear model, LQR gains and move measurements; TEPROTPEND.LIB and TEPROTPEND.DLL), our Arduino UNO V4.0, the A3 LQR demo with its sketch and a README.

File Structure
 File Structure
5.2 KB201.9 KB22.8 KB883.5 KB345 KB18.9 KB22.7 KB883.5 KB345 KB12.9 KBGallery12 images from the tutorialOpen the tutorial
 Gallery12 images from the tutorial
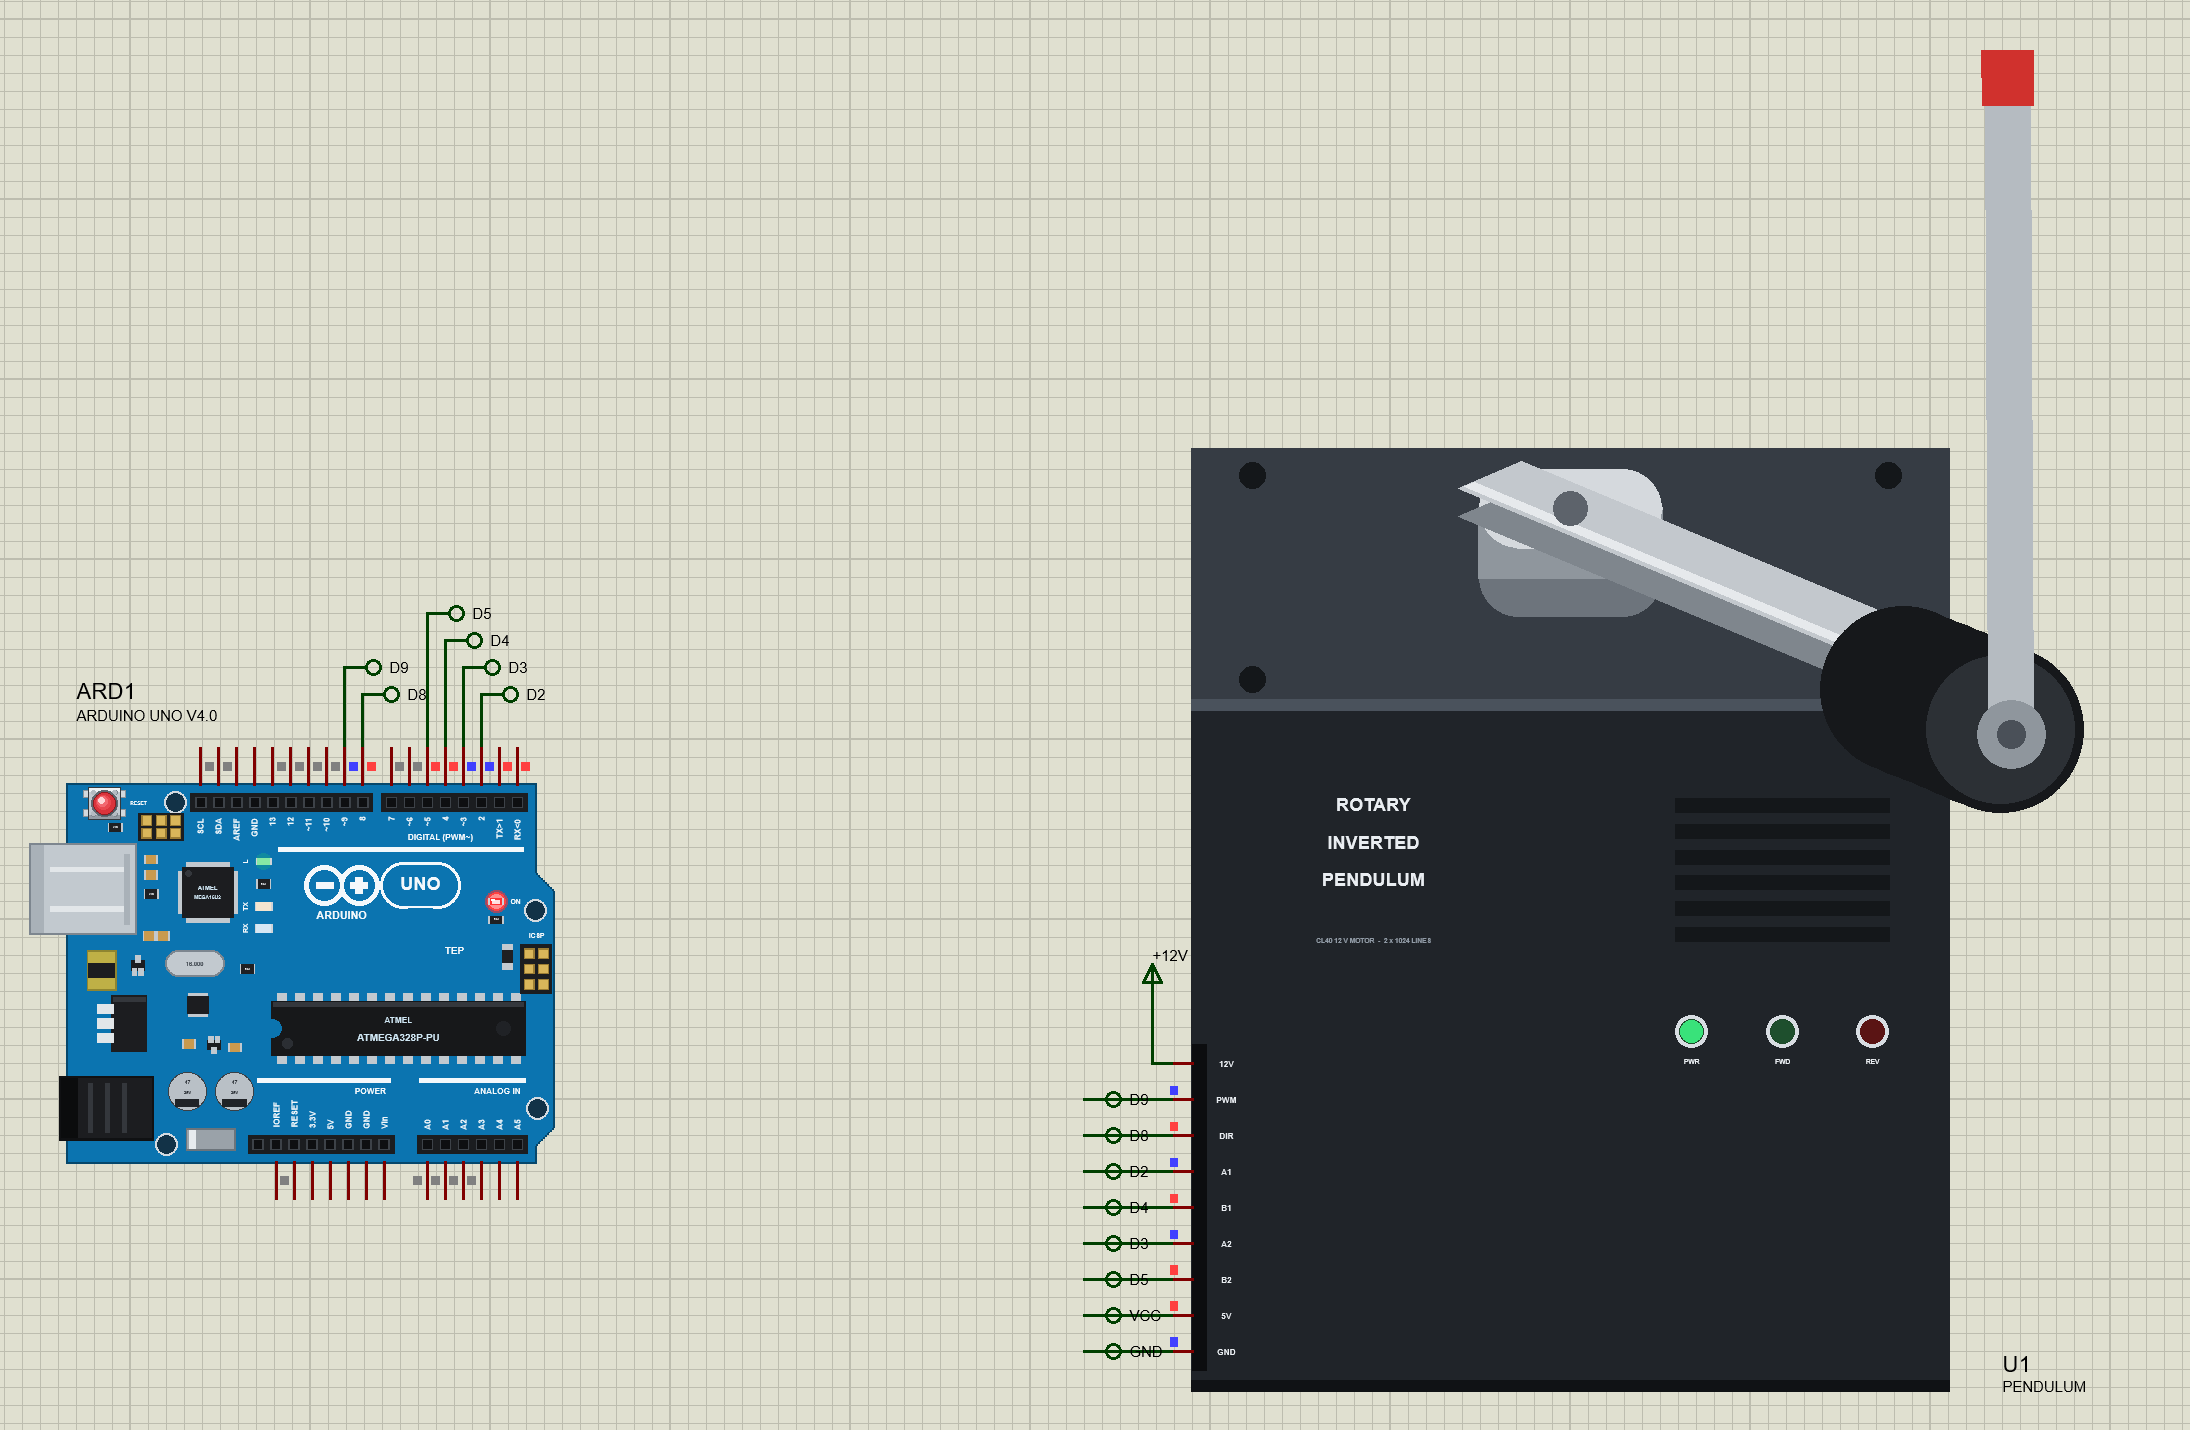
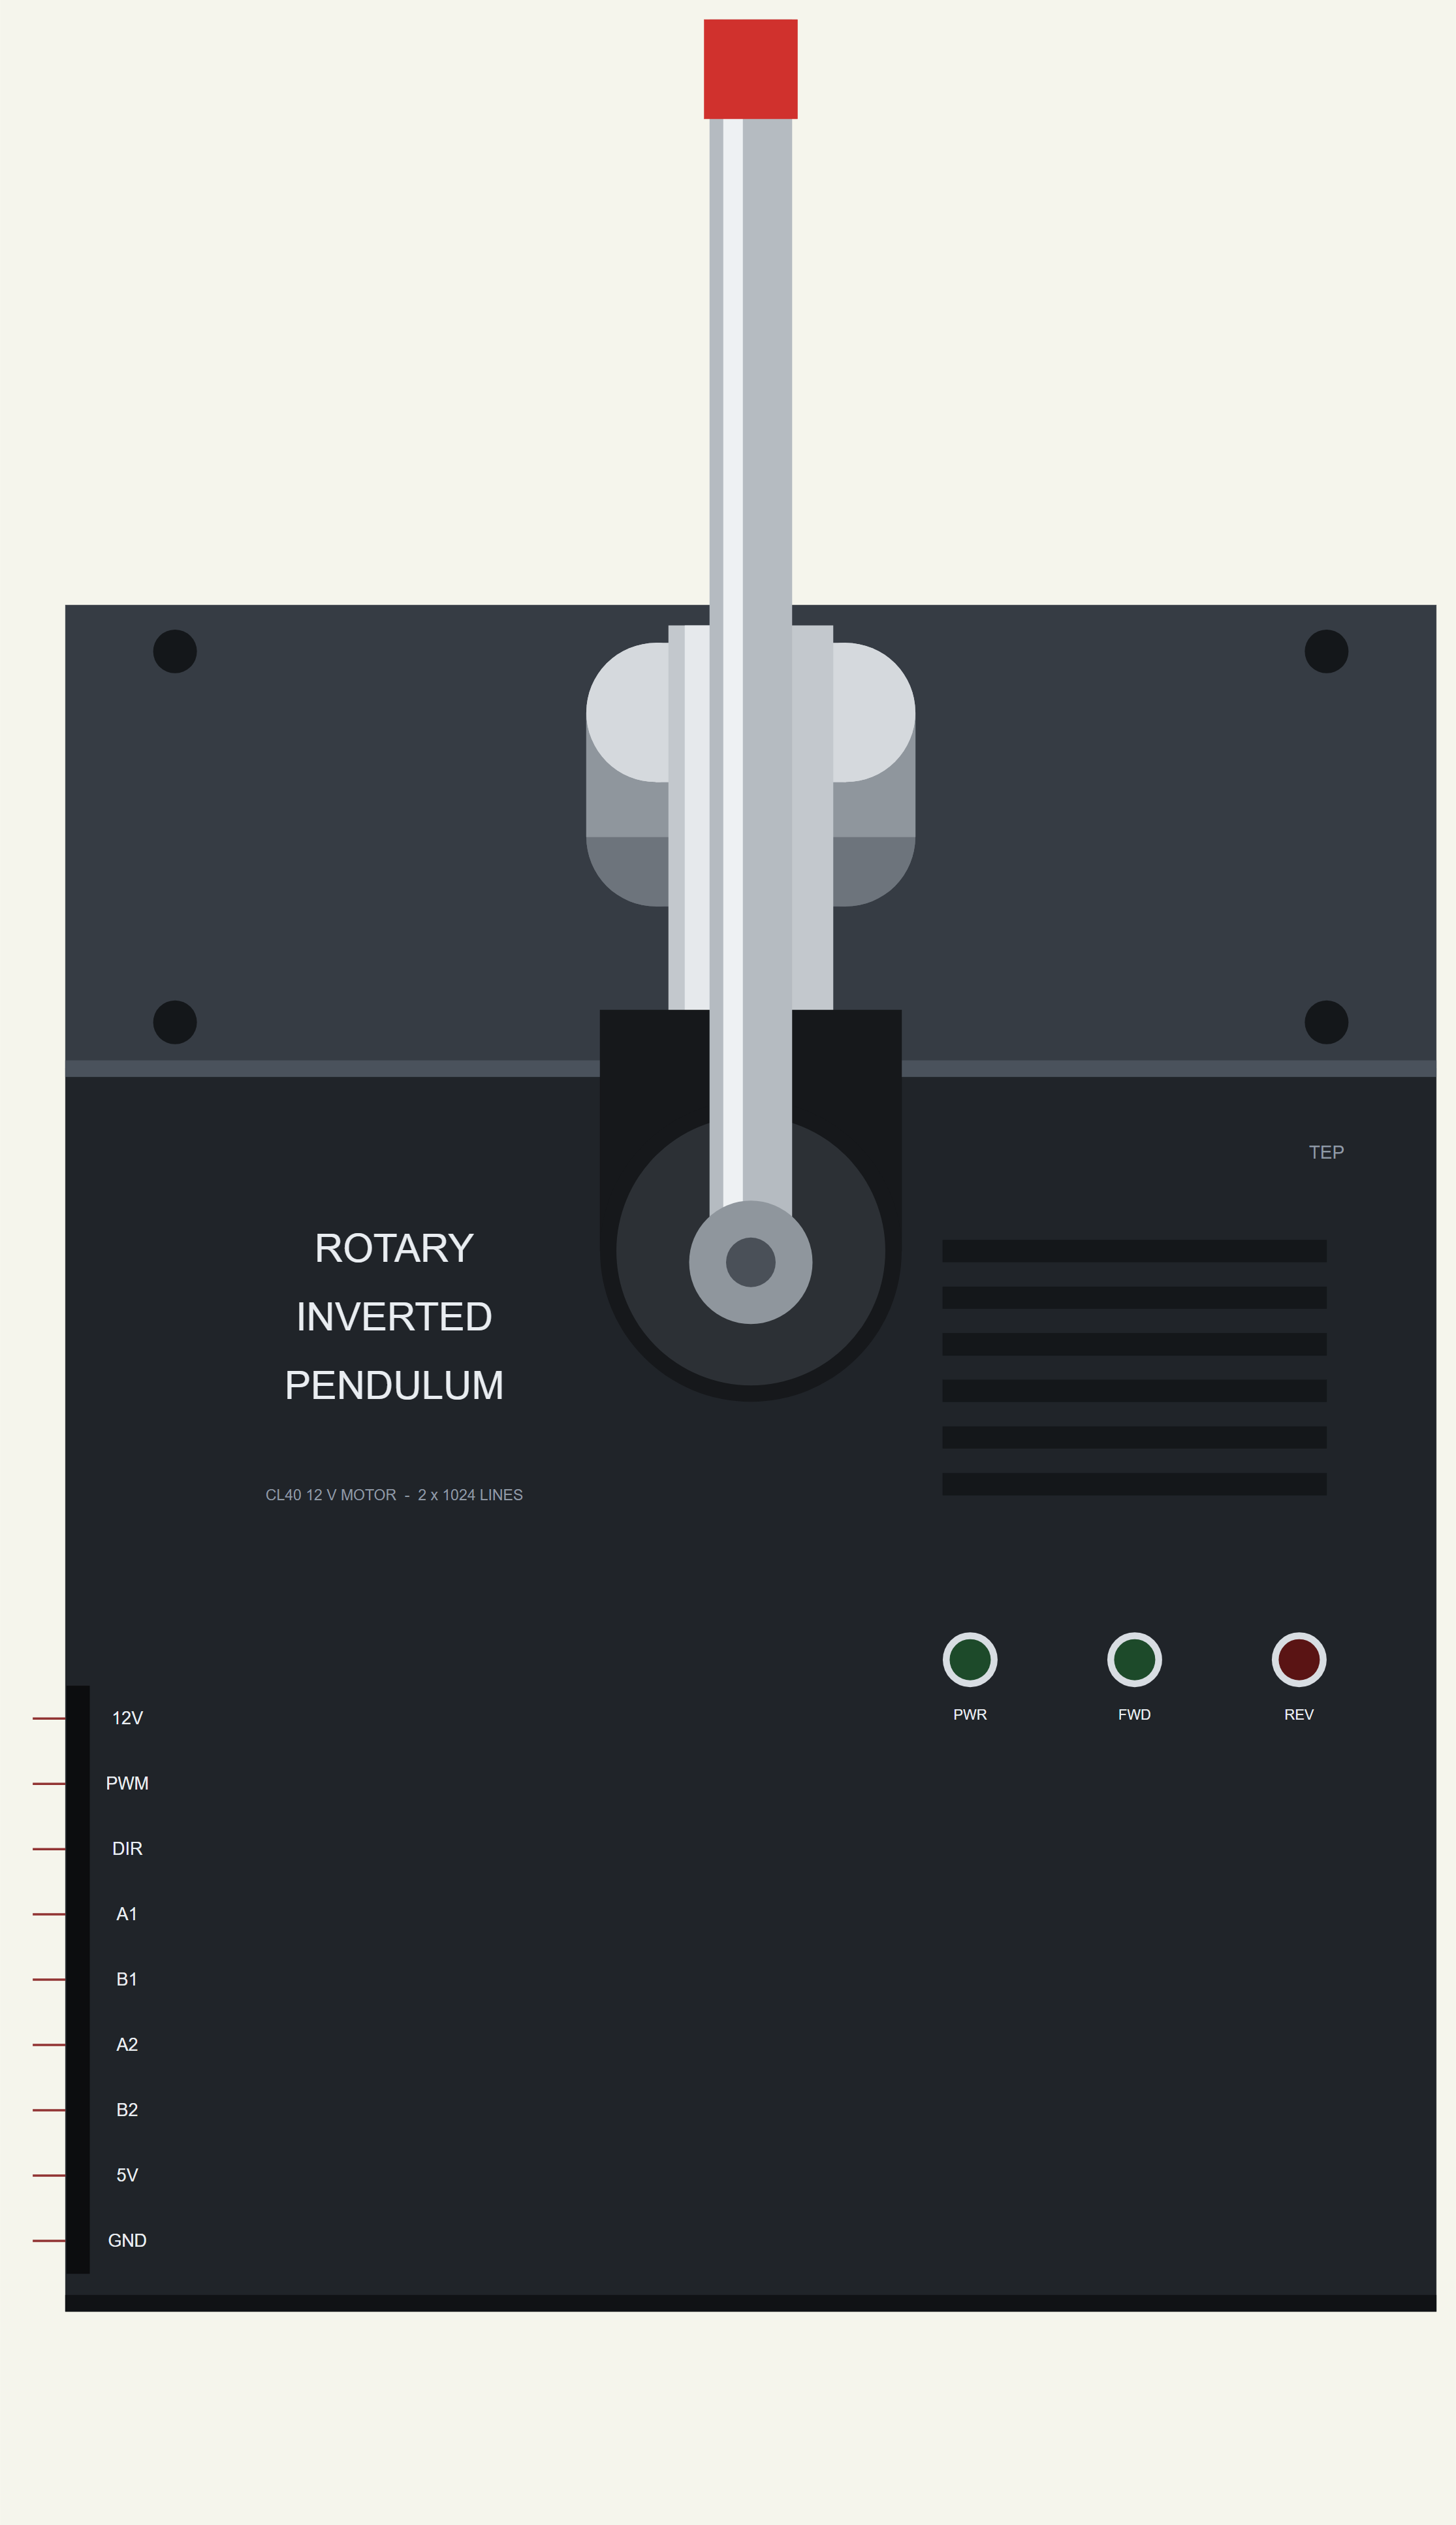
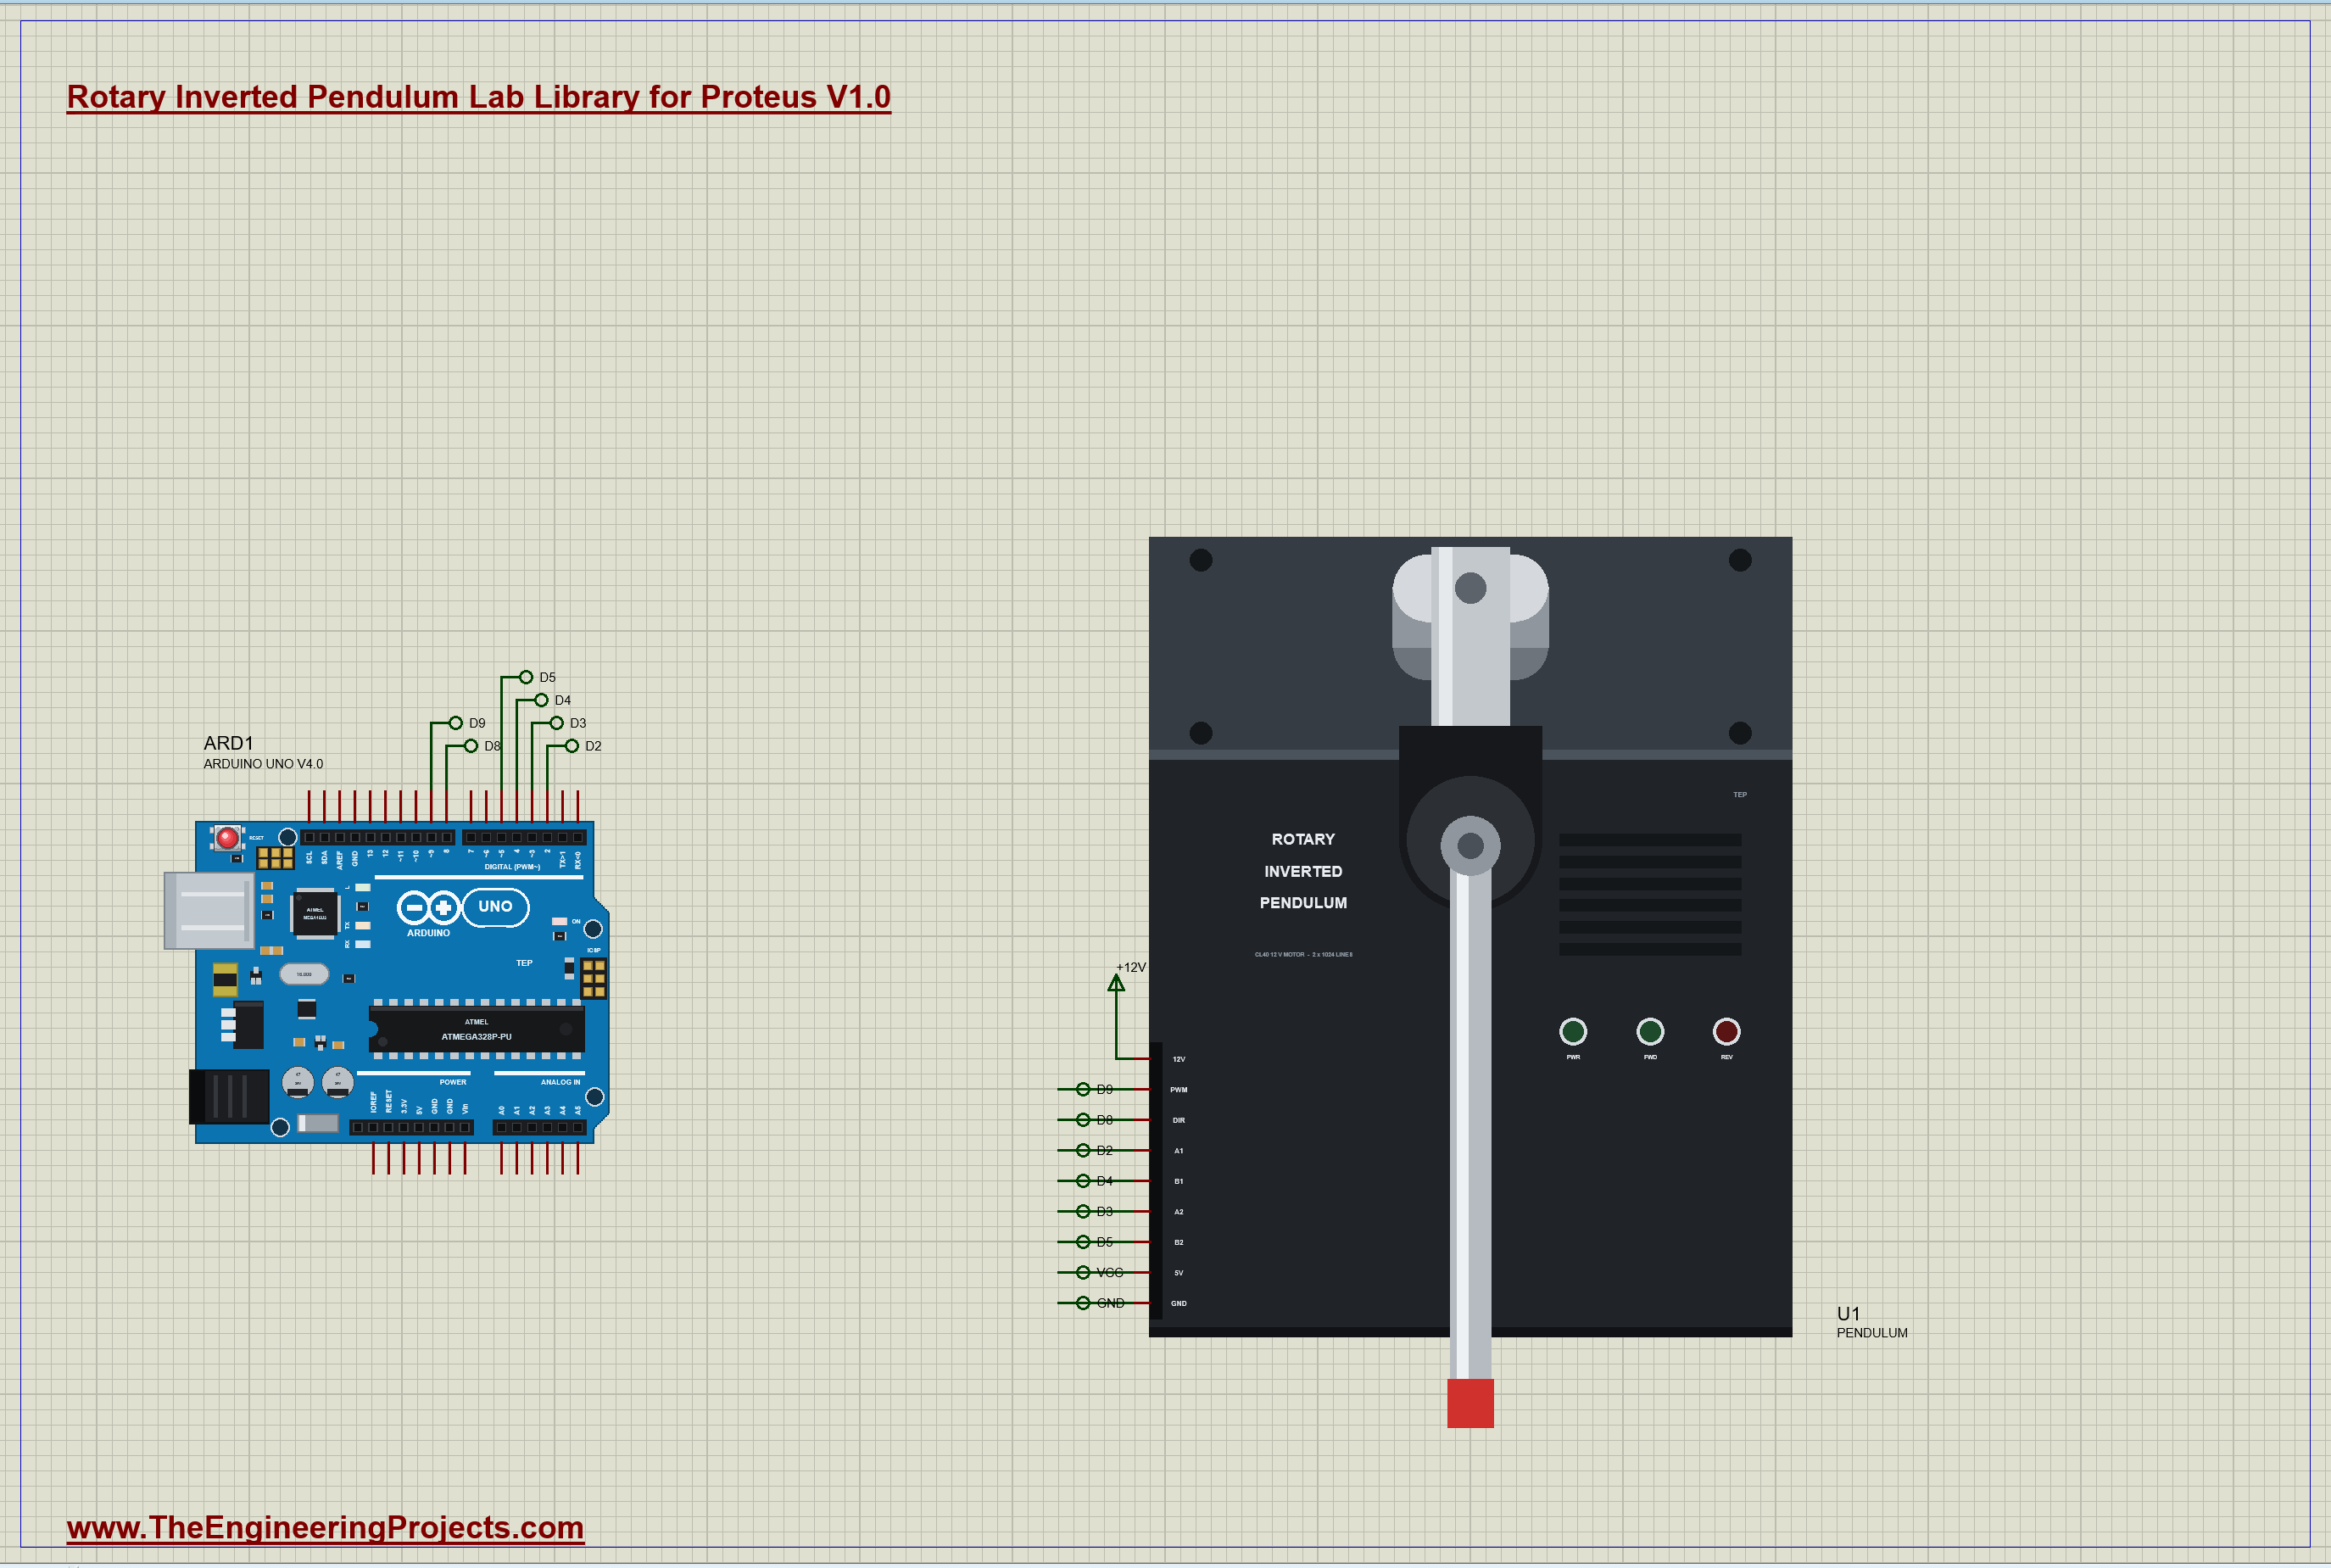
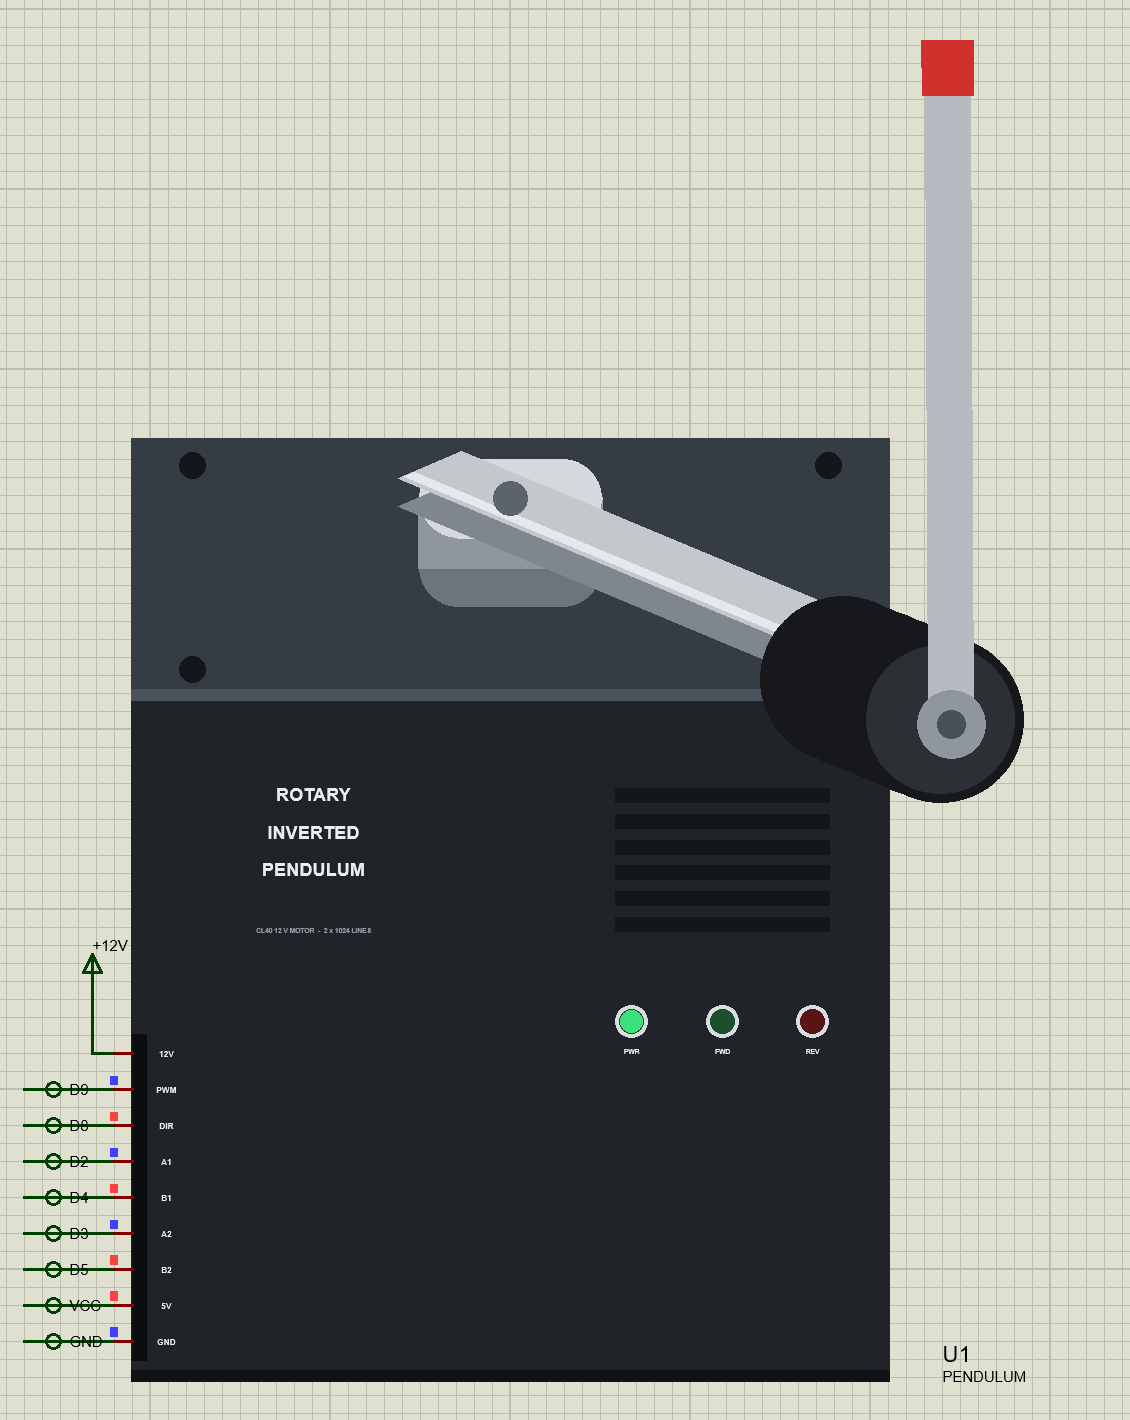
The circuit, the board and the results as they appear in Rotary Inverted Pendulum Lab Library for Proteus. Open an image for its full size.
README
 README
ROTARY INVERTED PENDULUM LAB LIBRARY FOR PROTEUS - V1.0 (a rotary pendulum lab with a pop-up)
Designed by The Engineering Projects
www.TheEngineeringProjects.com

IMPORTANT LINKS
Article (read it first - pictures, step by step, every feature explained):
  https://www.theengineeringprojects.com/2026/11/rotary-inverted-pendulum-lab-library-for-proteus.html
Report a bug or suggest a feature (our forum):
  https://www.theengineeringprojects.com/forum/category/rotary-pendulum-proteus-library
The demo runs on our Arduino UNO V4.0 (included) - working LEDs, RESET and a
built-in serial monitor, no Virtual Terminal to wire - its own article:
  https://www.theengineeringprojects.com/2026/10/arduino-uno-library-for-proteus-v40.html
Support us (the libraries are free):
  https://www.theengineeringprojects.com/donate

FILE STRUCTURE
Rotary-Inverted-Pendulum-TEP-v1.0/
|-- Proteus Library Files/
|   |-- ArduinoV4TEP.LIB                              201.9 KB   TEP Arduino boards V4.0 (UNO) -> LIBRARY
|   |-- TEPROTPEND.LIB                                 22.8 KB   the library -> LIBRARY folder
|-- Proteus Model Files/
|   |-- TEPARDUINO.DLL                                883.5 KB   the Arduino board model -> MODELS folder
|   |-- TEPROTPEND.DLL                                345.0 KB   the model -> MODELS folder
|-- Proteus Simulation/
|   |-- Pendulum_Demo.hex                              22.7 KB   the demo firmware
|   |-- Pendulum-LQR-ArduinoUnoV4.pdsprj               18.9 KB   the demo project
|   |-- TEPARDUINO.DLL                                883.5 KB   copy of the board model
|   |-- TEPROTPEND.DLL                                345.0 KB   copy of the model
|-- Arduino Code/
|   |-- Pendulum_Demo/Pendulum_Demo.ino                 5.2 KB   the demo sketch (source of the .hex)
|-- README.txt                                        ~14.2 KB   this file
Total: 2.68 MB (unzipped). The C++ source code of the models is not included.

WHAT IS IT?
A rotary inverted pendulum control lab, drawn at true scale and seen from the front and a little
above - our own design, after the rotary
pendulums of university control courses:
  * A 100 x 80 x 100 mm black base holds a coreless DC motor (the values of the Allied Motion CL40,
    its 12 V winding: 4.6 ohm, 30 mN.m/A) and
    an H-bridge. On the motor's hub an 80 mm aluminium arm turns; at its tip a 1024-line encoder
    carries a 100 mm steel pendulum (22.3 g)
    that swings in the plane across the arm. A second 1024-line encoder sits on the motor. PWR, FWD
    and REV LEDs on the front.
  * The physics: the full nonlinear equations of the rotary (Furuta) pendulum - the arm with the
    motor's torque, back-EMF and friction, the
    pendulum as a uniform rod and its coupling to the arm - solved in steps of 0.1 ms. Upright, the
    pendulum is an unstable pole of 16.1 rad/s.
  * The H-bridge: PWM high drives the motor from 12V (DIR high forward, low reverse), PWM low brakes
    it; every edge is timed.
  * The encoders: A1 / B1 (the arm) and A2 / B2 (the pendulum, from where it started) in quadrature,
    A leading B while the angle grows.
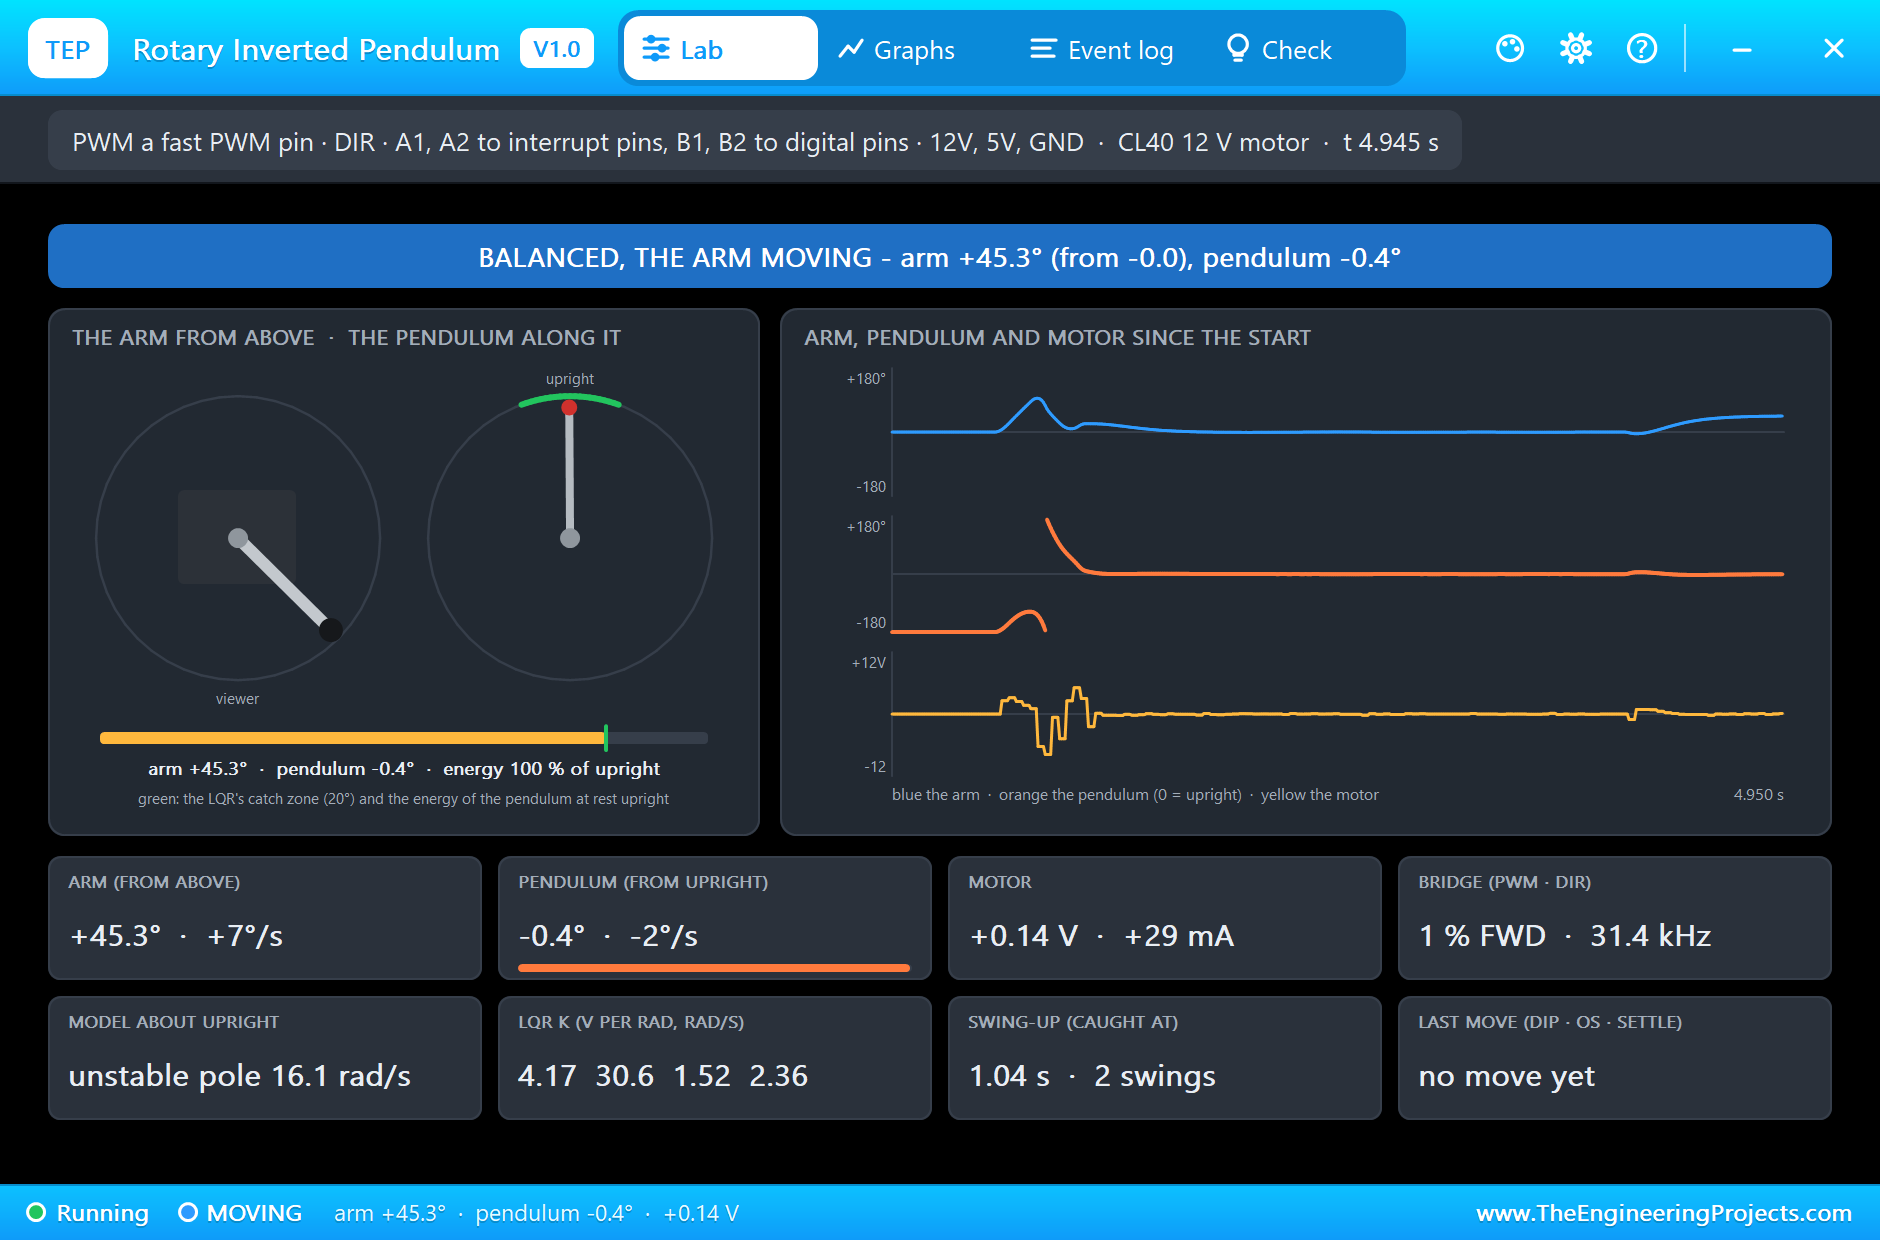
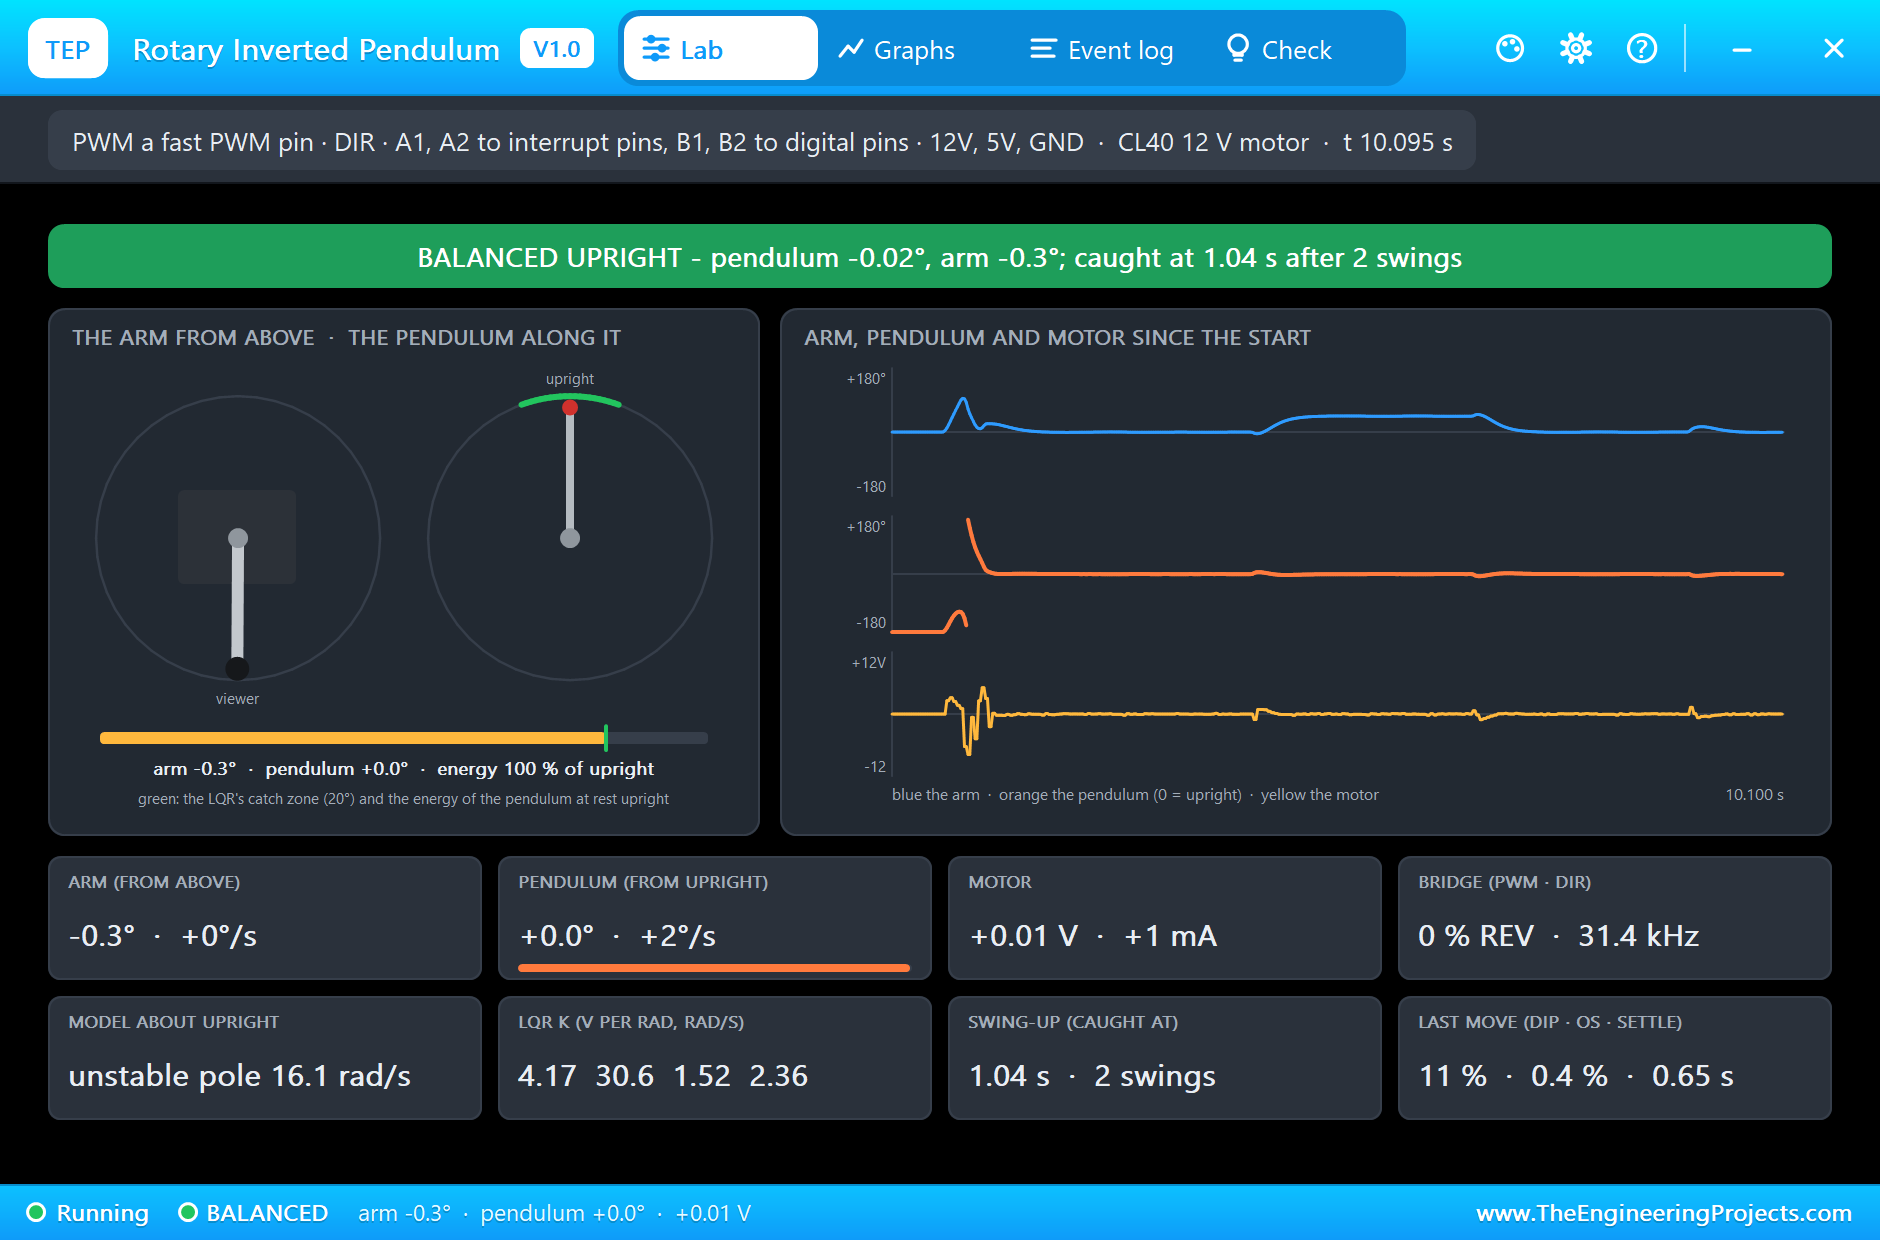
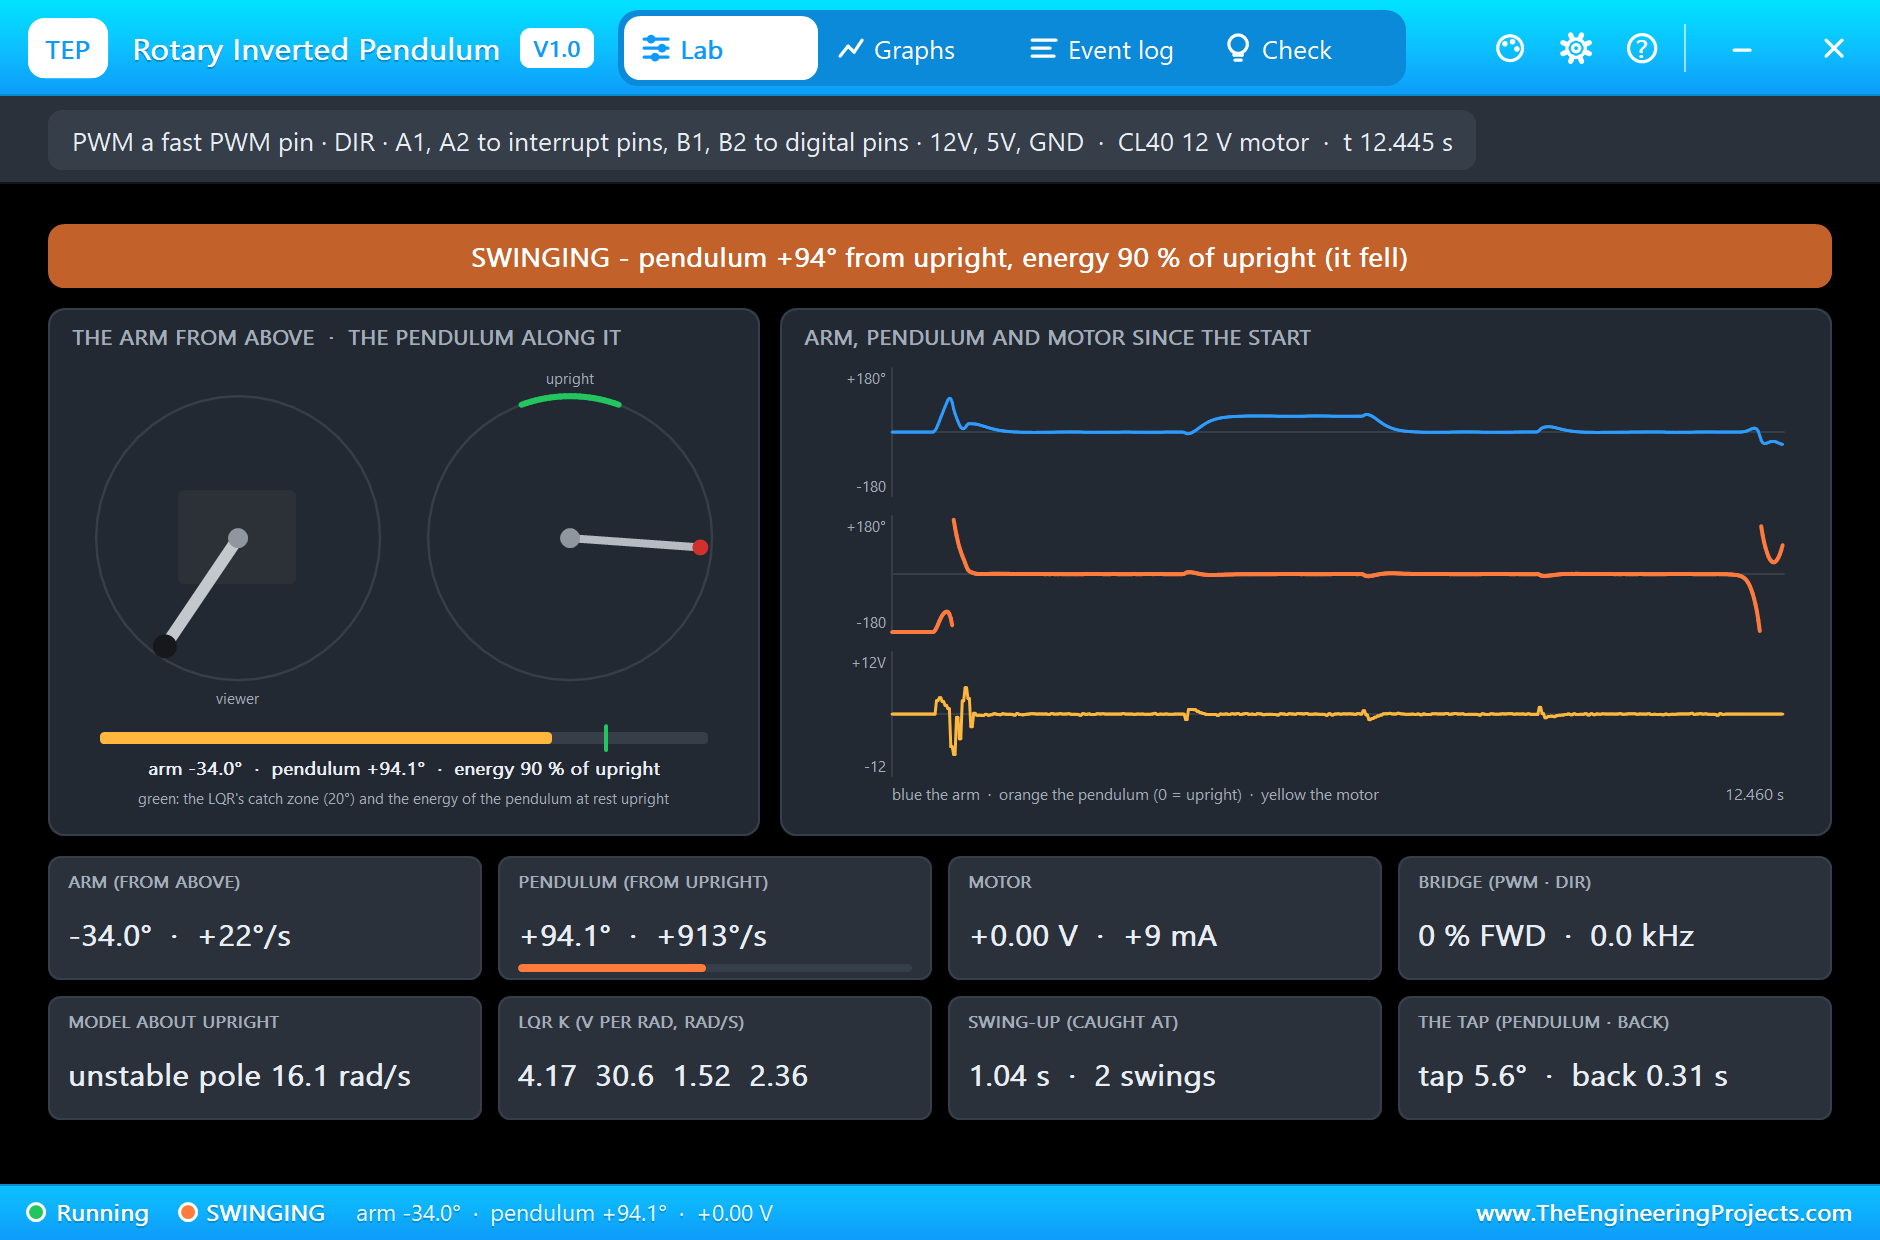
  * Click it at Run for the pop-up: the arm from above and the pendulum along it, the energy, the
    arm, the pendulum and the motor since the
    start, the linear model about upright (its poles), the LQR gains for the Q / R properties (a 2
    ms loop) with the closed-loop poles, the
    swing-up (swings, the catch), every arm move (rise, overshoot, the wrong-way dip, settling) and
    the tap.
The body is drawn as on the real part and to true scale against our Arduino.
The TEP signature and the pop-up are TEP additions.

ONE DEVICE (search "ROTPEND" in Pick Devices):
  ROTPENDTEP  "Rotary Inverted Pendulum V1.0" in TEPROTPEND.LIB (Control Labs > Motion), prefix U,
  model TEPROTPEND.DLL (mixed: digital +
              SPICE). Pins 12V (the motor's supply), PWM, DIR (the H-bridge), A1, B1 (the arm's
              encoder), A2, B2 (the pendulum's encoder), 5V
              (the encoders), GND - on the base's left edge.

THE POP-UP
Click the part at Run. Tabs:
    Lab        the arm from above and the pendulum along it (the LQR's catch zone, the energy), the
    arm, the pendulum and the motor since the
               start, and eight live values: the arm, the pendulum, the motor, the bridge, the
               model, the LQR gains, the swing-up and the
               last move (or the tap).
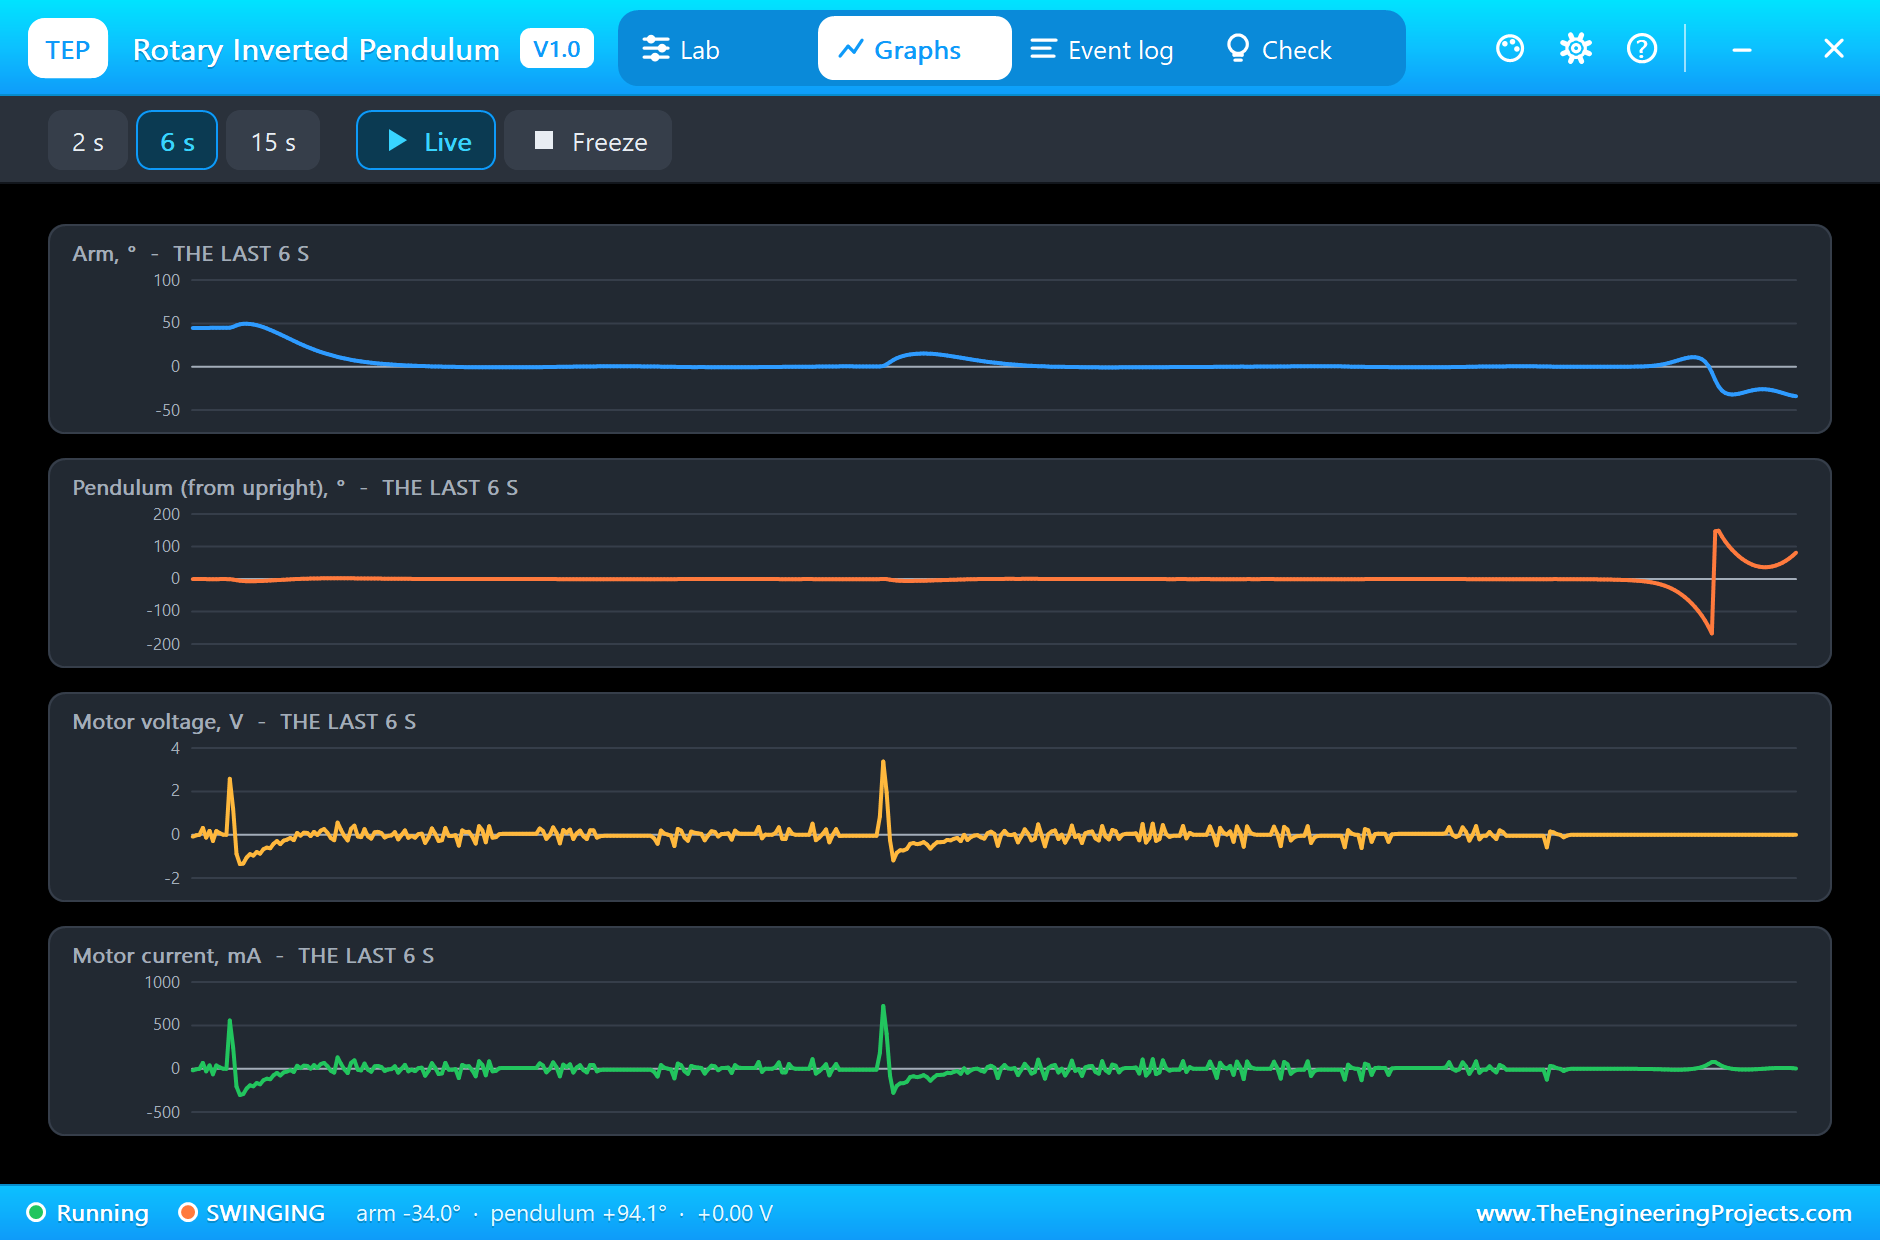
    Graphs     the live values over the last 2, 6 or 15 s. Live / Freeze.
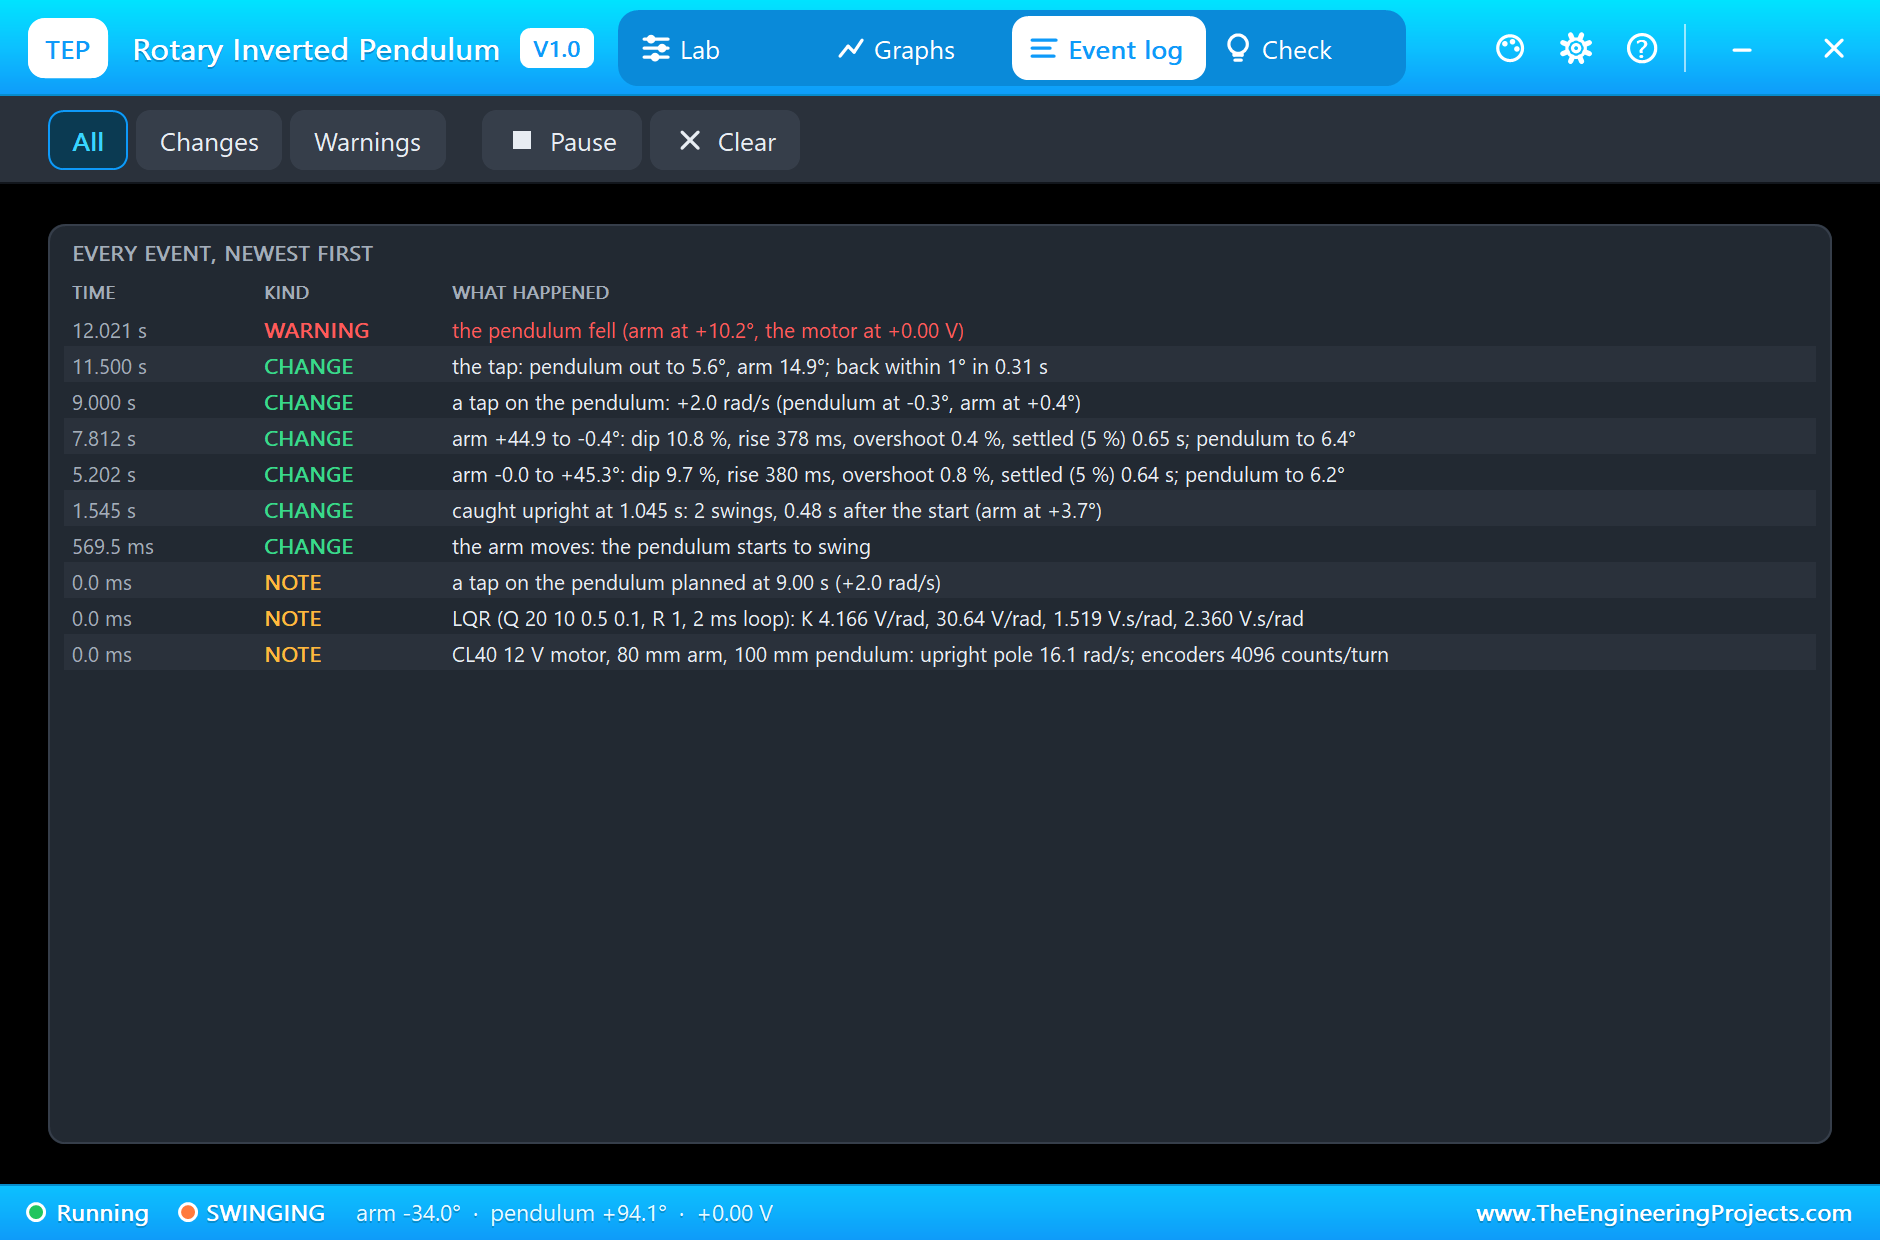
    Event log  every change and warning; filters All / Changes / Warnings, Pause, Clear
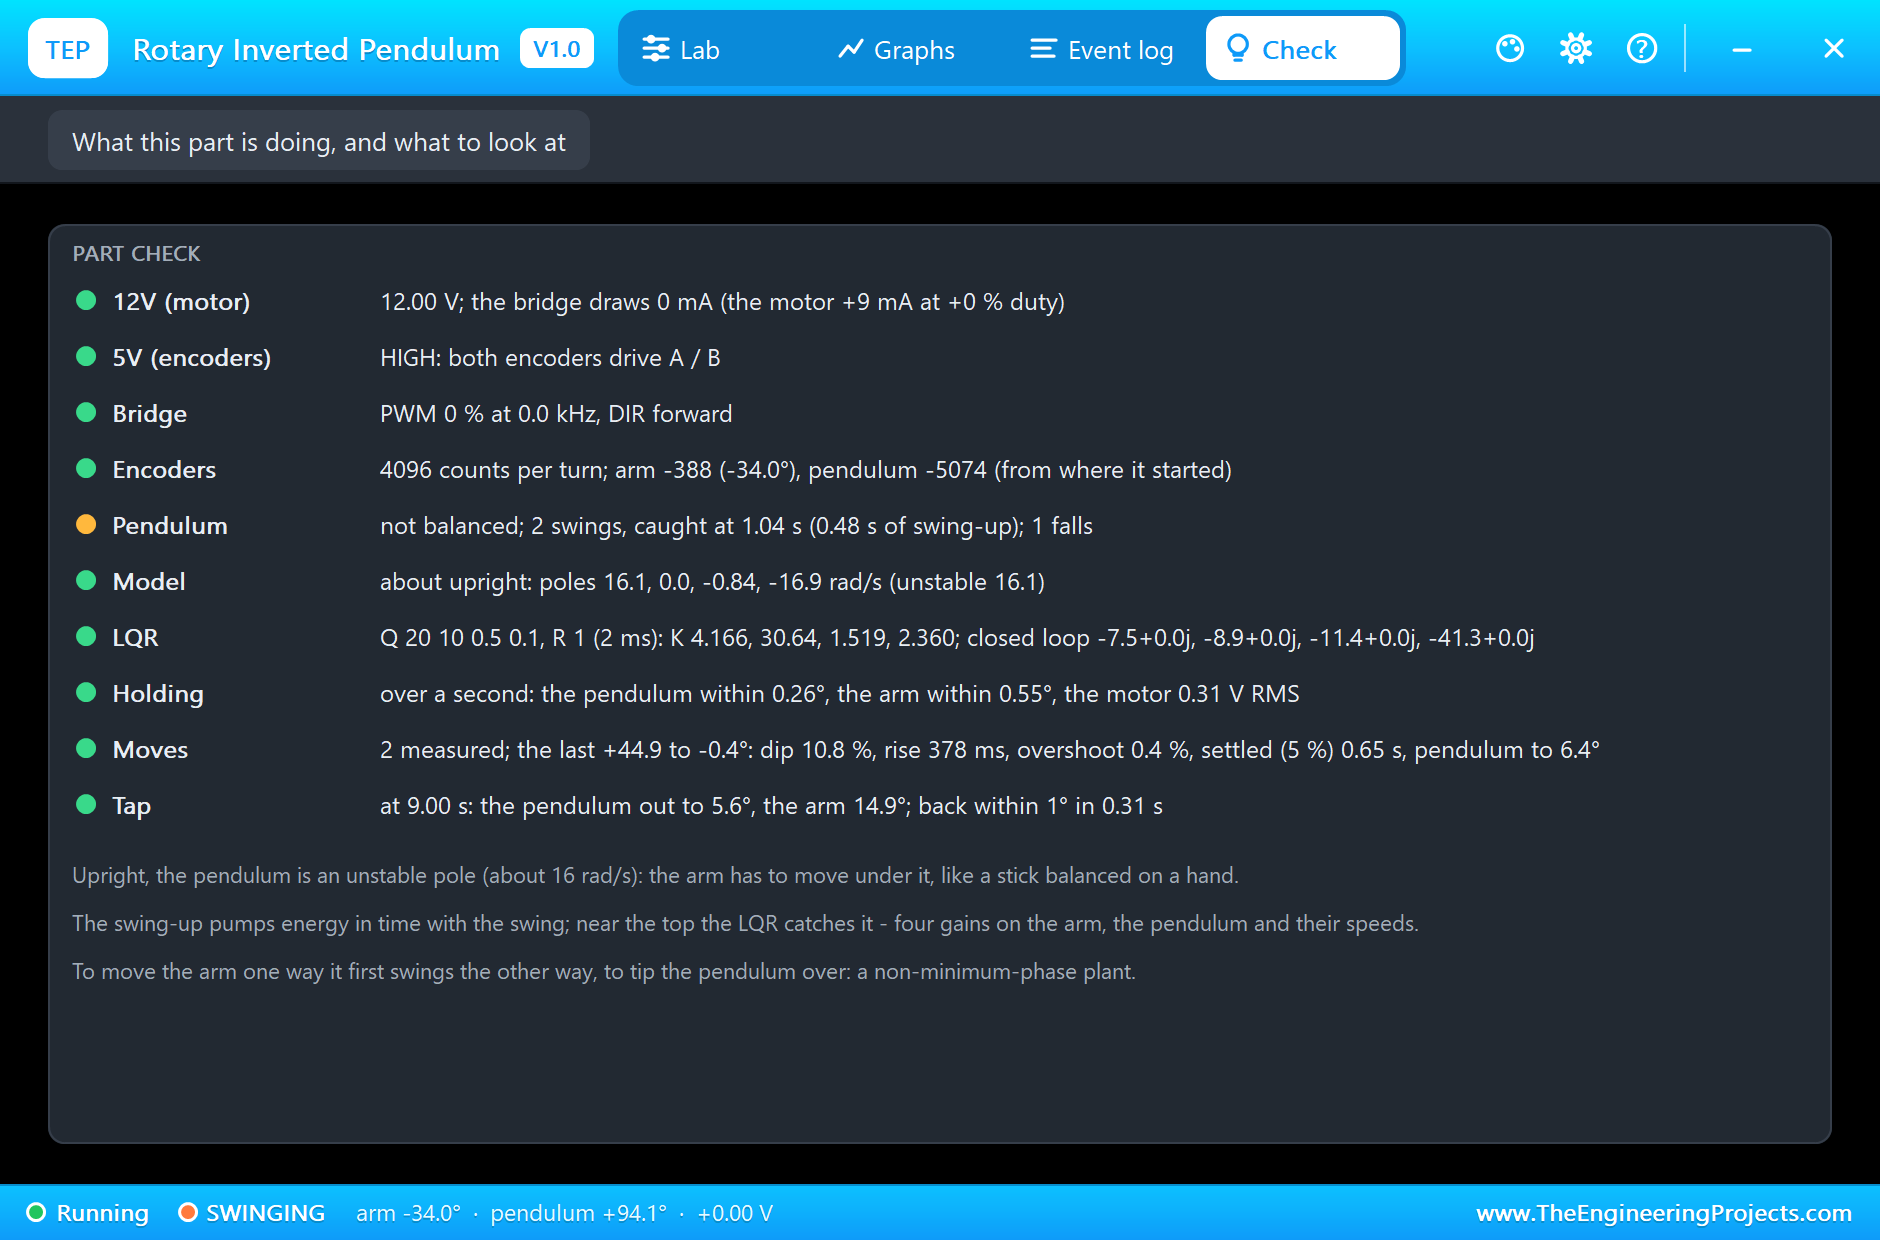
    Check      what the part is doing and what to look at, each with a verdict (green = fine, amber
    = check, red = wrong)
    Settings   theme, text size, open at Run, window size
    Help       report a bug, suggest a feature, article, updates, donate, forum; Copy diagnostics
    for a bug report

TEST STATUS
V1.0: verified in Proteus 8.5 on 7 Nov 2026 (the demo project as shipped: an A4 sheet, an Arduino UNO V4.0).
What the runs showed (the model's own numbers and the sketch's monitor):
  * The project loads and starts cleanly; the demo runs 12.4 simulated seconds in about two minutes
    on our PC; the bridge's PWM is 31.4 kHz.
  * Swing-up: a push of the arm at 0.5 s; the pendulum is caught upright at 1.045 s after 2 swings
    (0.48 s of swing-up), the arm at +3.7 deg.
  * The LQR (Q 20 10 0.5 0.1, R 1, a 2 ms loop): K 4.166 V/rad, 30.64 V/rad, 1.519 V.s/rad, 2.360
    V.s/rad. Open-loop poles about upright
    16.1, 0, -0.84 and -16.9 rad/s; closed-loop poles -7.5, -8.9, -11.4 and -41.3 rad/s.
  * Arm moves while balanced: 0 to +45.3 deg - the dip the wrong way 9.7 %, rise 380 ms, overshoot
    0.8 %, settled (5 %) in 0.64 s, the
    pendulum out to 6.2 deg; +44.9 to -0.4 deg - dip 10.8 %, rise 378 ms, overshoot 0.4 %, 0.65 s,
    the pendulum out to 6.4 deg.
  * Holding over a second: the pendulum within 0.26 deg, the arm within 0.55 deg, the motor 0.31 V
    RMS.
  * The tap at 9 s (+2 rad/s): the pendulum out to 5.6 deg, the arm 14.9 deg; back within 1 deg in
    0.31 s.
  * The balance off at 11.5 s: the pendulum falls at 12.02 s. The pop-up: Lab, Graphs, Event log,
    Check - all four pages followed the run.

INSTALLATION (about 2 minutes)
1. Close Proteus. Extract the WHOLE ZIP to a normal folder (e.g. Desktop).
2. Copy everything in "Proteus Library Files" (TEPROTPEND.LIB and our Arduino library V4.0,
ArduinoV4TEP.LIB, with the ARDUINO UNO V4.0 used by the demo) to the LIBRARY folder of Proteus, for
example:
     C:\Program Files (x86)\Labcenter Electronics\Proteus 8 Professional\LIBRARY
   (use the folder that already holds Proteus's own .LIB files).
3. Copy TEPROTPEND.DLL and TEPARDUINO.DLL from "Proteus Model Files" to the MODELS folder
(...\Proteus 8 Professional\MODELS).
4. Delete TEPROTPEND.IDX from the LIBRARY folder if it is there (Proteus makes a new index).
5. Start Proteus. In Pick Devices (P) search "ROTPEND".

RUN THE DEMO
"Proteus Simulation\Pendulum-LQR-ArduinoUnoV4.pdsprj" (an A4 sheet) - keep the .hex file and the
DLLs beside the project.
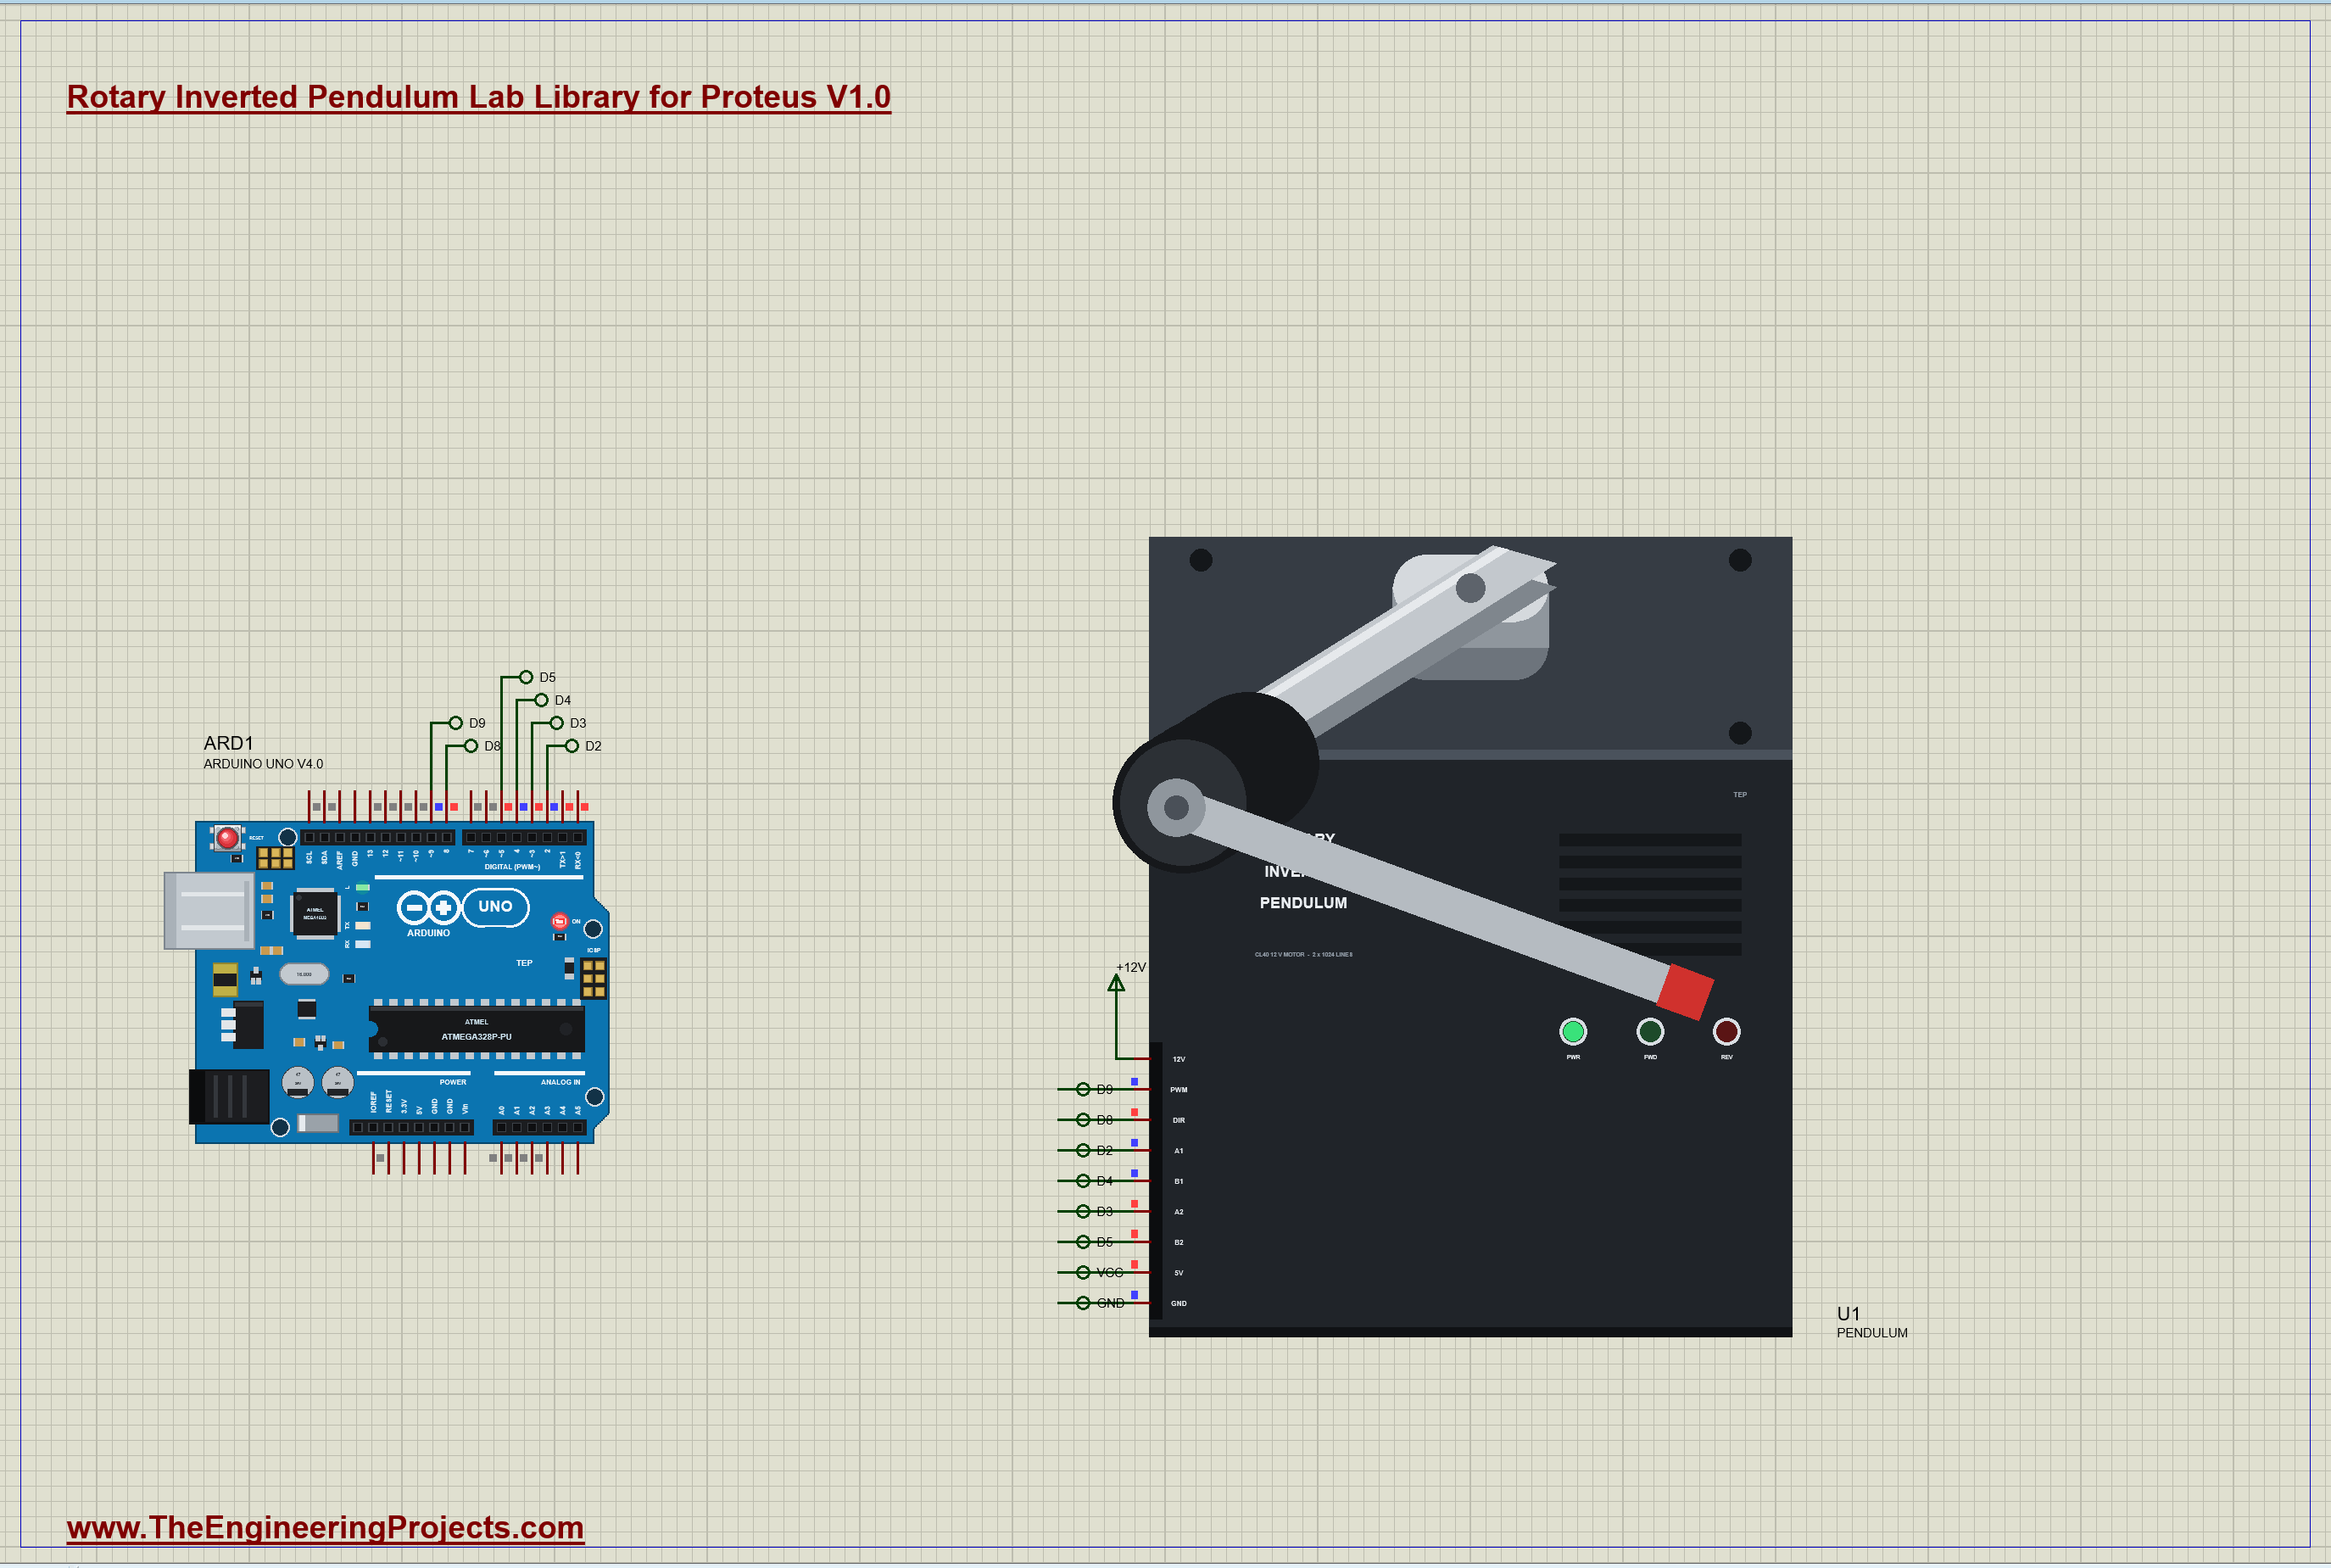
  ARD1:   Arduino UNO V4.0 running Pendulum_Demo.hex, its serial monitor built in (window "TEP
  Arduino UNO - ARD1").
  U1:     the pendulum lab (TAP = 9 s): PWM - D9 (Timer1 at 31.4 kHz), DIR - D8, A1 - D2, B1 - D4,
  A2 - D3, B2 - D5, 5V - VCC, 12V - a
          +12V terminal, GND. A1 and A2 are on the UNO's two external interrupts; each A edge is one
          count (2048 counts per turn).
  1. At 0.5 s a push of the arm starts the pendulum swinging; the energy swing-up brings it to the
  top, where the LQR catches it.
  2. Balanced, the arm goes to 45 degrees at 4 s and back at 6.5 s (it dips the wrong way first);
  the lab taps the pendulum at 9 s.
  3. At 11.5 s the balance goes off and the pendulum falls.
Closed the monitor? Click the UNO's USB port.

WIRING (the same in Proteus and on a real board)
  PWM: a fast PWM pin (D9 with Timer1's prescaler at 1: 31.4 kHz); DIR: any pin; A1, A2: the two
  interrupt pins (D2, D3); B1, B2: any pins;
  5V and GND; 12V: a supply that can give 2.6 A (the motor's stall current).
REAL HARDWARE:
 * A real rotary pendulum's encoder cable winds up: keep the arm within a turn or two either way.
 * Start with the pendulum hanging still: its encoder counts from where it is at power-up.
 * The swing-up throws the pendulum hard: keep hands and cables out of its circle.
 * A real arm has some backlash and the pendulum's bearing some friction: expect the arm to wander a
   degree or two while balancing.

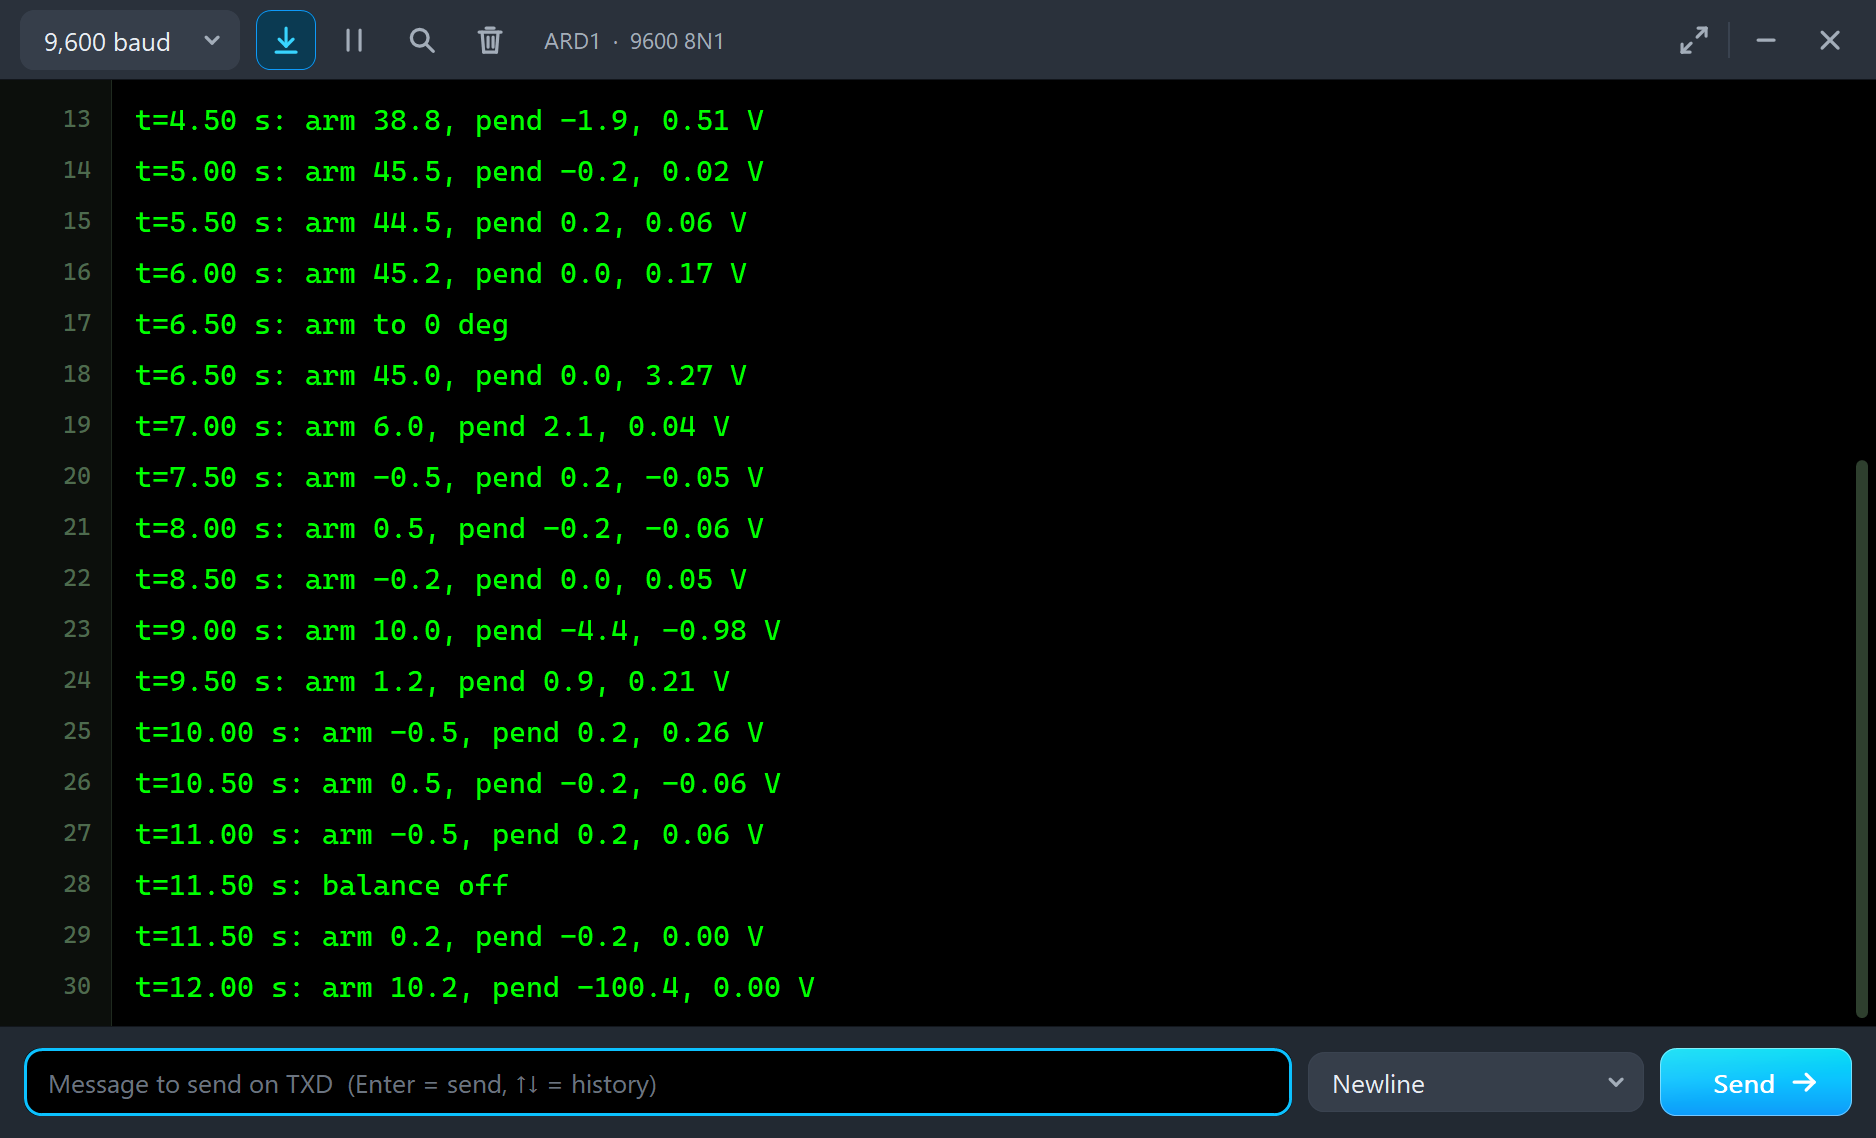
THE DEMO SKETCH ON THE SERIAL MONITOR (Pendulum_Demo V1.0, 9600 baud)
There are no commands. The sketch swings the pendulum up, balances it, moves the arm, rides out the
tap, lets go, and prints every 0.5 s.
EXPECTED MONITOR OUTPUT
  Rotary Inverted Pendulum - The Engineering Projects
  t=5.00 s: arm 45.5, pend -0.2, 0.02 V
  t=8.00 s: arm 0.5, pend -0.2, -0.06 V

PROPERTIES (double-click the part > Edit Properties)
  Encoder lines (LINES)                lines per turn of both encoders (x4 = counts per turn)
  The pendulum at the start (START)    degrees from hanging (its encoder reads 0 there)
  LQR weights Q (Q)                    arm, pendulum, arm speed, pendulum speed: the pop-up's LQR
  uses them
  LQR weight R (R)                     on the voltage
  A tap (TAP)                          a tap on the pendulum (+2 rad/s) at this time in seconds; 0 =
  none
Every run starts again from the properties.

LINKS.INI (OPTIONAL)
The Help page cards of the pop-up open web pages. To point them somewhere else without a new DLL,
put a text file named links.ini next to TEPROTPEND.DLL with lines KEY=URL, for example:
  ARTICLE=https://www.theengineeringprojects.com/...
Keys: WEBSITE, FORUM, BUG_REPORT, FEATURE_REQUEST, ARTICLE, USER_GUIDE,
UPDATE_CHECK, DONATE. Only http:// and https:// links are used; lines starting
with # are comments.

TROUBLESHOOTING
* NO 12 V: the bridge is driven but 12V is missing - the motor cannot turn.
* NO ENCODER SUPPLY: 5V is low - the encoders' outputs float.
* The pendulum never gets to the top: the swing-up's push is too weak, or its sign is wrong (push
  the arm against the pendulum's swing).
* It falls as soon as it is caught: a sign in the LQR - the pendulum leaning one way must turn the
  arm the same way.
* The part is not simulated: TEPROTPEND.DLL is missing from MODELS and from the project folder. No
  UNO / no monitor window: TEPARDUINO.DLL is missing, or click the UNO's USB port.

BUG REPORTS AND FEATURE REQUESTS
Please post them in our forum with a screenshot, the Serial Monitor text, the
simulation log and the pop-up's Copy diagnostics text:
  https://www.theengineeringprojects.com/forum/category/rotary-pendulum-proteus-library

SUPPORT US
This library is free. If it saves you time, please support our work:
  https://www.theengineeringprojects.com/donate

WEBSITE
  https://www.theengineeringprojects.com/

LICENCES AND THIRD-PARTY NOTES
* The model (TEPROTPEND.DLL), the symbols and artwork, the other parts of ours in the demo and the
  Arduino Library V4.0 (ArduinoV4TEP.LIB / TEPARDUINO.DLL, with its built-in TEP Serial Monitor
  Advance) are made by The Engineering Projects. The models use only standard Windows libraries; no
  Visual C++ redistributable is needed.
  The C++ source code is not included.
* Arduino UNO V4.0 (ArduinoV4TEP.LIB / TEPARDUINO.DLL, our Arduino Library V4.0 - its
  microcontroller is Proteus's own AVR model): The Engineering Projects,
  https://www.theengineeringprojects.com/2026/10/arduino-uno-library-for-proteus-v40.html
* The .hex file is built from the demo sketch and the Arduino AVR core 1.8.6, which includes
  LGPL-licensed code; its source code is available at
  https://github.com/arduino/ArduinoCore-avr/tree/1.8.6
* Proteus is a product of Labcenter Electronics and is not included. Arduino is a trademark of Arduino SA.
  This library is not made or endorsed by Arduino or Labcenter.

REBUILDING THE FIRMWARE (OPTIONAL)
The HEX file is supplied; Arduino IDE is not needed to run the demo. To edit the sketch, open
Arduino Code\Pendulum_Demo\Pendulum_Demo.ino, select Arduino Uno and use Sketch > Export Compiled
Binary. Replace the simulation's .hex with the exported HEX. The sketch needs 8,252 bytes of flash
and 483 bytes of RAM.

MODEL SCOPE AND LIMITS
Modelled: the motor's resistance, back-EMF and friction (its 0.59 mH is far faster than anything
here), the arm and the pendulum with the
full coupling, the pendulum's bearing friction, the H-bridge's duty and direction, both encoders'
edges, the supply's current.
Not modelled: the encoder cable's pull, gear backlash (the arm is direct drive), the arm's flex, the
motor's heating.

VERSION
TEP Rotary Inverted Pendulum library V1.0 (Nov 2026). Device ROTPENDTEP (TEPROTPEND.LIB /
TEPROTPEND.DLL). Demo sketch Pendulum_Demo V1.0. Demo board: ARDUINO UNO V4.0 (TEP Arduino Library
V4.0) with its built-in serial monitor.Development1 release
 Development1 release
-
V1.0Rotary Inverted Pendulum Library for Proteus V1.0this page
V1.0 is the only release in the Download Center so far. When a newer version is published, it appears above with its own download page.
Installation8 steps
 Installation8 steps
From the download to a working project, in order. The steps follow what the package contains.
You will need
- Proteus Design SuiteProteus 8 or newer (Labcenter), on Windows
- Arduino IDE1.8 or 2.x, with the board of the tutorial chosen under Tools → Board
- Any archive toolWindows, macOS and Linux extract ZIP files on their own
Steps
- 1
Extract the archive
Right-click rotary-inverted-pendulum-tep-v1-0-af6e110a801d4333b9d796e005afb069.zip and choose Extract All (or open it with 7-Zip or WinRAR) into a folder you can find again. Keep its folder structure (Rotary-Inverted-Pendulum-TEP-v1.0) as it is.
- 2
Copy the library files into Proteus
Move ArduinoV4TEP.LIB and TEPROTPEND.LIB and the files into the LIBRARY folder of your Proteus installation: C:\Program Files (x86)\Labcenter Electronics\Proteus 8 Professional\LIBRARY for Proteus 8, or the matching Proteus 7 folder. Older versions keep it under ProgramData\Labcenter Electronics. If Proteus is open, close it first.
- 3
Add the simulation model
Copy TEPARDUINO.DLL and TEPROTPEND.DLL into the MODELS folder next to LIBRARY, so the component can run, not only be drawn.
- 4
Restart Proteus and place the component
Start Proteus, open a schematic, press P (Pick Devices) and search for the component by the name used in the tutorial. It appears with its pins ready to wire.
- 5
Open the sketch in the Arduino IDE
Open Pendulum_Demo.ino, select your board and port under Tools, then Verify. Sketch → Export Compiled Binary writes the HEX file a simulation needs.
- 6
Load the HEX file
In Proteus double-click the microcontroller, set Program File to Pendulum_Demo.hex and run the simulation. For real hardware, flash the same file with your programmer.
- 7
Open the example simulation
Open Pendulum-LQR-ArduinoUnoV4.pdsprj in Proteus to see the wiring exactly as in the tutorial. Check the controller's Program File path, then press Play.
- 8
Follow the tutorial
Rotary Inverted Pendulum Lab Library for Proteus explains every connection and setting in order; keep it open beside the files while you build.
FAQs9 questionsContact TEP
 FAQs9 questions
How do I download Rotary Inverted Pendulum Library for Proteus V1.0?
Wait for the 30-second guest countdown on this page, then press the download button; the file comes straight from our storage. Members who are logged in skip the wait. If the browser opens the file instead of saving it, use its Save as option. The download link is made for you when the countdown ends and works for 15 minutes; a saved or shared link stops working, so share this page instead.
What is inside the archive?
Rotary Inverted Pendulum Library for Proteus V1.0 comes as a ZIP archive of 10 files (1.2 MB, 2.7 MB unpacked) holding Proteus library files, simulation model DLLs, a Proteus simulation, an Arduino sketch and compiled HEX firmware. Open the File Structure tab for the full list of 10 files.
What should I do if the download does not start?
Check the browser's download list first; an ad blocker or a company firewall can also hold it back, so try another browser or network. If the file arrives incomplete, download it again. For an installation problem, read the Install tab or tell us in the comments with your software version and the exact error message.
Is this file free?
Yes. Every file in the TEP Download Center is free for learning, personal and student projects. If you share it, link back to this page or the tutorial so others find the latest version.
How do I check that the file arrived complete?
Compare its SHA-256 with the one on this page, f682184f46a682d0e28d7b7ca856e1169afcc411f796abd02b7575b0b91257d0. In PowerShell run Get-FileHash "rotary-inverted-pendulum-tep-v1-0-af6e110a801d4333b9d796e005afb069.zip"; on macOS or Linux run shasum -a 256 "rotary-inverted-pendulum-tep-v1-0-af6e110a801d4333b9d796e005afb069.zip". The same value means the file is exactly the one in our storage; a different one means the download broke off, so download it again.
Do I need WinRAR to open the ZIP file?
No. Windows, macOS and Linux open ZIP archives on their own (Extract All, or double-click). WinRAR and 7-Zip work too. Extract the whole archive before using the files.
Where do I put the LIB and IDX files?
Both files go into the LIBRARY folder of your Proteus installation (Proteus 8: C:\Program Files (x86)\Labcenter Electronics\Proteus 8 Professional\LIBRARY; Proteus 7 has the same folder under its own name). Restart Proteus afterwards and search for the component with P.
Which Proteus version does the library need?
The tutorial names the Proteus version the library was made and tested with. Most TEP libraries work in Proteus 7 and Proteus 8; if the component does not appear after a restart, check that both the LIB and the IDX file were copied and that Proteus was fully closed while copying.
How do I get the HEX file into the simulation?
Compile the sketch in the Arduino IDE (Sketch → Export Compiled Binary gives you the HEX next to the sketch), then in Proteus double-click the board, set Program File to that HEX and run.
Members skip the wait. Log in or join TEP.

- 0Total downloads
- 4%Popularity
- ProteusCategory
- 0Comments
- ssyedzainnasirUploaded by
- 9 Nov 2026Uploaded at


 SHA-256
f682184f46a682d0e28d7b7ca856e1169afcc411f796abd02b7575b0b91257d0


 Need help with this file?
 Tags
Related Proteus
All Proteus tutorials


Comments
0